
POJ 1573:Robot Motion
| Time Limit: 1000MS | Memory Limit: 10000K | |
| Total Submissions: 11324 | Accepted: 5512 |
Description
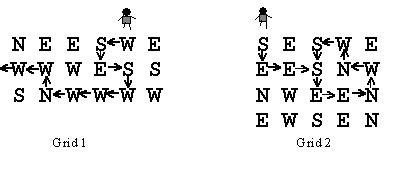
A robot has been programmed to follow the instructions in its path. Instructions for the next direction the robot is to move are laid down in a grid. The possible instructions are
N north (up the page)
S south (down the page)
E east (to the right on the page)
W west (to the left on the page)
For example, suppose the robot starts on the north (top) side of Grid 1 and starts south (down). The path the robot follows is shown. The robot goes through 10 instructions in the grid before leaving the grid.
Compare what happens in Grid 2: the robot goes through 3 instructions only once, and then starts a loop through 8 instructions, and never exits.
You are to write a program that determines how long it takes a robot to get out of the grid or how the robot loops around.
Input
which the robot enters from the north. The possible entry columns are numbered starting with one at the left. Then come the rows of the direction instructions. Each grid will have at least one and at most 10 rows and columns of instructions. The lines of instructions
contain only the characters N, S, E, or W with no blanks. The end of input is indicated by a row containing 0 0 0.
Output
on some number of locations repeatedly. The sample input below corresponds to the two grids above and illustrates the two forms of output. The word "step" is always immediately followed by "(s)" whether or not the number before it is 1.
Sample Input
3 6 5

NEESWE

WWWESS

SNWWWW

4 5 1

SESWE

EESNW

NWEEN

EWSEN

0 0 0
Sample Output
10 step(s) to exit

3 step(s) before a loop of 8 step(s)
突然爱上了模拟题,要是所有题都像这样的题目只需模拟一下走的方向,而不考虑算法的该有多好。。。哈哈
从头开始走,记录第几步走在了哪一个格子上,如果要走的格子大于0了,说明走重复了。这题比较水。
代码:
#include <iostream>

#include <algorithm>

#include <cmath>

#include <vector>

#include <string>

#include <cstring>

#pragma warning(disable:4996)

using namespace std;

enum{ E,N,W,S };

int map_f[20][20];

char call[20][20];

int move_x[5]={0,-1,0,1};

int move_y[5]={1,0,-1,0};

int X,Y,start,i,cur_x,cur_y,flag;

void solve()

{

	int temp;

	cur_x = 1;

	cur_y = start;

	map_f[cur_x][cur_y]=1;

	while(1)

	{

		if(flag)

			break;

		if(call[cur_x][cur_y]=='E')

		{

			temp=map_f[cur_x][cur_y];

			cur_x = cur_x + move_x[E];

			cur_y = cur_y + move_y[E];

			if(cur_x<=0 || cur_y<=0 || cur_x>X || cur_y>Y)

			{

				flag=1;

				cout<<temp<<" step(s) to exit"<<endl;

			}

			else if(map_f[cur_x][cur_y])

			{

				flag=1;

				cout<<map_f[cur_x][cur_y]-1<<" step(s) before a loop of "<<temp-map_f[cur_x][cur_y]+1<<" step(s)"<<endl;

			}

			else

			{

				map_f[cur_x][cur_y]=temp+1;

			}

		}

		else if(call[cur_x][cur_y]=='N')

		{

			temp=map_f[cur_x][cur_y];

			cur_x = cur_x + move_x[N];

			cur_y = cur_y + move_y[N];

			if(cur_x<=0 || cur_y<=0 || cur_x>X || cur_y>Y)

			{

				flag=1;

				cout<<temp<<" step(s) to exit"<<endl;

			}

			else if(map_f[cur_x][cur_y])

			{

				flag=1;

				cout<<map_f[cur_x][cur_y]-1<<" step(s) before a loop of "<<temp-map_f[cur_x][cur_y]+1<<" step(s)"<<endl;

			}

			else

			{

				map_f[cur_x][cur_y]=temp+1;

			}

		}

		else if(call[cur_x][cur_y]=='W')

		{

			temp=map_f[cur_x][cur_y];

			cur_x = cur_x + move_x[W];

			cur_y = cur_y + move_y[W];

			if(cur_x<=0 || cur_y<=0 || cur_x>X || cur_y>Y)

			{

				flag=1;

				cout<<temp<<" step(s) to exit"<<endl;

			}

			else if(map_f[cur_x][cur_y])

			{

				flag=1;

				cout<<map_f[cur_x][cur_y]-1<<" step(s) before a loop of "<<temp-map_f[cur_x][cur_y]+1<<" step(s)"<<endl;

			}

			else

			{

				map_f[cur_x][cur_y]=temp+1;

			}

		}

		else if(call[cur_x][cur_y]=='S')

		{

			temp=map_f[cur_x][cur_y];

			cur_x = cur_x + move_x[S];

			cur_y = cur_y + move_y[S];

			if(cur_x<=0 || cur_y<=0 || cur_x>X || cur_y>Y)

			{

				flag=1;

				cout<<temp<<" step(s) to exit"<<endl;

			}

			else if(map_f[cur_x][cur_y])

			{

				flag=1;

				cout<<map_f[cur_x][cur_y]-1<<" step(s) before a loop of "<<temp-map_f[cur_x][cur_y]+1<<" step(s)"<<endl;

			}

			else

			{

				map_f[cur_x][cur_y]=temp+1;

			}

		}

	}

}

int main()

{

	while(cin>>X>>Y>>start)

	{

		if(!(X+Y+start))

			break;

		memset(map_f,0,sizeof(map_f));

		flag=0;

		for(i=1;i<=X;i++)

		{

			cin>>call[i]+1;

		}

		solve();

	}

	return 0;

}
版权声明:本文为博主原创文章,未经博主允许不得转载。
POJ 1573:Robot Motion的更多相关文章
- 【POJ - 1573】Robot Motion
-->Robot Motion 直接中文 Descriptions: 样例1 样例2 有一个N*M的区域,机器人从第一行的第几列进入,该区域全部由'N' , 'S' , 'W' , 'E' ,走 ...
- 模拟 POJ 1573 Robot Motion
题目地址:http://poj.org/problem?id=1573 /* 题意:给定地图和起始位置,robot(上下左右)一步一步去走,问走出地图的步数 如果是死循环,输出走进死循环之前的步数和死 ...
- POJ 1573 Robot Motion(BFS)
Robot Motion Time Limit: 1000MS Memory Limit: 10000K Total Submissions: 12856 Accepted: 6240 Des ...
- Poj OpenJudge 百练 1573 Robot Motion
1.Link: http://poj.org/problem?id=1573 http://bailian.openjudge.cn/practice/1573/ 2.Content: Robot M ...
- POJ 1573 Robot Motion(模拟)
题目代号:POJ 1573 题目链接:http://poj.org/problem?id=1573 Language: Default Robot Motion Time Limit: 1000MS ...
- Robot Motion 分类: POJ 2015-06-29 13:45 11人阅读 评论(0) 收藏
Robot Motion Time Limit: 1000MS Memory Limit: 10000K Total Submissions: 11262 Accepted: 5482 Descrip ...
- POJ 1573 Robot Motion
Robot Motion Time Limit: 1000MS Memory Limit: 10000K Total Submissions: 12978 Accepted: 6290 Des ...
- poj 1573 Robot Motion【模拟题 写个while循环一直到机器人跳出来】
...
- poj1573 Robot Motion
Robot Motion Time Limit: 1000MS Memory Limit: 10000K Total Submissions: 12507 Accepted: 6070 Des ...
随机推荐
- ch8 高度相等的列--CSS方法
如下图所示效果,可以使用表格实现,本文采用在CSS中实现. 标记如下: <div class="wrapper"> <div class="box&qu ...
- PHP几个快速读取大文件例子
PHP几个快速读取大文件例子 感谢 把我给崩了 的投递 时间:2014-10-16 来源:三联 在PHP中,对于文件的读取时,最快捷的方式莫过于使用一些诸如file.file_get_contents ...
- Samjia 和矩阵[loj6173](Hash+后缀数组)
传送门 本题要求本质不同的子矩阵,即位置不同也算相同(具体理解可以看样例自己yy). 我们先看自己会什么,我们会求一个字符串中不同的子串的个数.我们考虑把子矩阵变成一个字符串. 先枚举矩阵的宽度,记为 ...
- arm linux 移植 x265
背景 本来想着把 x265编译到ffmpeg里面,搞定了x265的编译:但是一直报ERROR: x265 not found using pkg-config这个错误,我按照网上的资料,查看了ffbu ...
- 新闻网大数据实时分析可视化系统项目——17、Spark2.X分布式弹性数据集
1.三大弹性数据集介绍 1)概念 2)优缺点对比 2.Spark RDD概述与创建方式 1)概述 在集群背后,有一个非常重要的分布式数据架构,即弹性分布式数据集(resilientdistribute ...
- 微信小程序支付功能前端流程
只是分享一下小程序支付功能的前端流程和代码, 仅供参考(使用的是uni app). handleCreate () { /** 第一步:前台将商品数据发送到后台,后台创建订单入库并返回订单id等信息 ...
- 连接mysql报错java.sql.SQLException: The server time zone value '�й���ʱ��' is unrecognized...解决方法
报错内容: java.sql.SQLException: The server time zone value '�й���ʱ��' is unrecognized or represents mo ...
- Android拷贝工程不覆盖原工程的配置方法
http://www.2cto.com/kf/201203/125131.html 在Eclipse中改包名的时候选择refactor-->rename,勾选Rename subpackages ...
- C# 控件缩写规范
标准控件缩写规范 类 型 前 缀 示 例 Adrotator adrt adrtTopAd BulletedList blst blstCity Button btn btnSubmit Calend ...
- python数据分析基础
---恢复内容开始--- Python数据分析基础(1) //2019.07.09python数据分析基础总结1.python数据分析主要使用IDE是Pycharm和Anaconda,最为常用和方便的 ...