
Visual odometry and zed's IMU fusion on RTAB-Map
**"When using /camera/odom, you don't need to use visual_odometry node. rtabmap should be subscribed to /odometry/flltered if you want to use odometry output from IMU and /camera/odometry fusion, otherwise IMU is ignored if rtabmap is subscribed directly to /camera/odom. **
To get a good fusion between IMU and vo, the transform between the sensors should be very precise. You can use kalibr tool to get this information and get more precise TF. "
Open zed
zed test
cd /usr/local/zed/tools/
./ZED\ Explorer
If the camera can be openned, turn it off.
As the tutorial in ROS said,
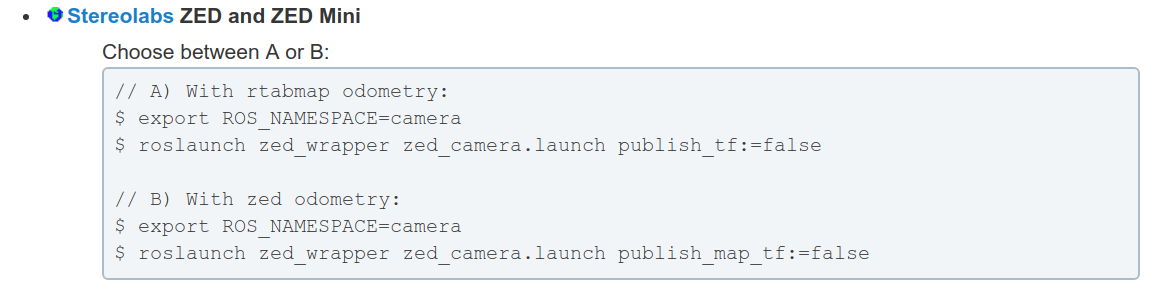
I want to use IMU data in zed, so
$ export ROS_NAMESPACE=camera

$ roslaunch zed_wrapper zed_camera.launch publish_map_tf:=false
Enter the mapping mode
As the tutorial in ROS said,
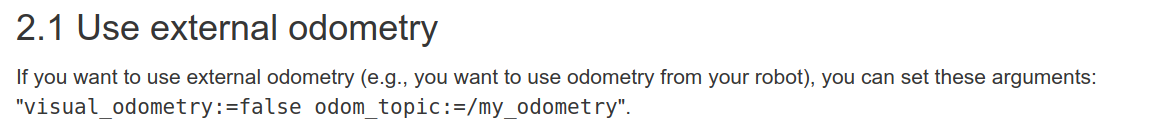
I want to use IMU data in zed, so
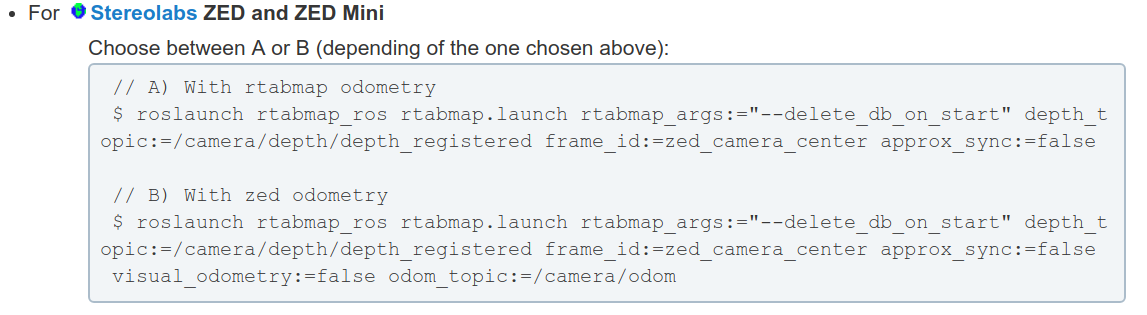
$ roslaunch rtabmap_ros rtabmap.launch rtabmap_args:="--delete_db_on_start" depth_topic:=/camera/depth/depth_registered frame_id:=zed_camera_center approx_sync:=false visual_odometry:=false odom_topic:=/camera/odom
These days a more convenient way to launch rtabmap with zed
roslaunch zed_rtabmap_example zed_rtabmap.launch
References:
[1] Fusion on zed and imu, but the map drifted immediately
Visual odometry and zed's IMU fusion on RTAB-Map的更多相关文章
- 泡泡一分钟:Visual Odometry Using a Homography Formulation with Decoupled Rotation and Translation Estimation Using Minimal Solutions
张宁 Visual Odometry Using a Homography Formulation with Decoupled Rotation and Translation Estimation ...
- 基于视觉的 SLAM/Visual Odometry (VO) 开源资料、博客和论文列表
基于视觉的 SLAM/Visual Odometry (VO) 开源资料.博客和论文列表 以下为机器翻译,具体参考原文: https://github.com/tzutalin/awesome-vis ...
- [Tutorial]综述阅读笔记 <Visual Odometry PartII_Introduce about BA>
目录 Visual Odometry: Part II - Matching, Robustness, and Applications ---- paper notes 特征点的选择与匹配 特征点匹 ...
- (3)视觉里程计 Visual Odometry
首先分析include头文件下的slamBase.h文件 # pragma once // 各种头文件 // C++标准库 #include <fstream> #include < ...
- Visual Odometry
http://www.cvlibs.net/datasets/kitti/eval_odometry.php
- DeepVO: Towards End-to-End Visual Odometry with Deep Recurrent Convolutional Neural Networks
1.Introduction DL解决VO问题:End-to-End VO with RCNN 2.Network structure a.CNN based Feature Extraction 论 ...
- 视觉惯性里程计Visual–Inertial Odometry(VIO)概述
周围很多朋友开始做vio了,之前在知乎上也和胖爷讨论过这个问题,本文主要来自于知乎的讨论. 来自https://www.zhihu.com/question/53571648/answer/13772 ...
- 三维重建7:Visual SLAM算法笔记
VSLAM研究了几十年,新的东西不是很多,三维重建的VSLAM方法可以用一篇文章总结一下. 此文是一个好的视觉SLAM综述,对视觉SLAM总结比较全面,是SLAM那本书的很好的补充.介绍了基于滤波器的 ...
- Kintinuous 相关论文 Volume Fusion 详解
近几个月研读了不少RGBD-SLAM的相关论文,Whelan的Volume Fusion系列文章的效果确实不错,而且开源代码Kintinuous结构清晰,易于编译和运行,故把一些学习时自己的理解和经验 ...
随机推荐
- 为工具箱添加CSKin选项卡
如何使用CSKin 项目的引用→右键→添加; 找到SCKin.dll; 添加引用 工具箱新建一个选项卡; 工具箱的空白处→右键→添加选项卡→SKinControl, 将刚才的CSKin.dll 直接拖 ...
- class_create(),class_device_create()创建/dev/xxx 名字
在刚开始写Linux设备驱动程序的时候,很多时候都是利用mknod命令手动创建设备节点,实际上Linux内核为我们提供了一组函数,可以用来在模块加载的时候自动在/dev目录下创建相应设备节点,并在卸载 ...
- jQuery笔记——DOM操作
在 JavaScript 中,DOM 不但内容庞大繁杂,而且我们开发的过程中需要考虑更多的兼容性.扩展性.在 jQuery 中,已经将最常用的 DOM 操 作方法进行了有效封装,并且不需要考虑浏览器的 ...
- 网站漏洞扫描并自动化工具-XAttacker
注:该脚本根据网站的cms类型来扫描,所以推荐用来扫外国的站 运行脚本 ┌─[root@sch01ar]─[/sch01ar/XAttacker] └──╼ #perl XAttacker.pl 询问 ...
- dd命令的高级应用
dd是Linux上的一个常用的命令.例如:dd if=/1.txt of=/tmp/2.txt (其中, if代表input file:of代表output file, 命令的结果就是将根目录 ...
- CSS 透明
filter:alpha(opacity=60);-moz-opacity:0.5;opacity: 0.5;
- mysql忘记root密码的处理方法
在linux下,如果忘记了mysql中root用户的密码可以采用以下办法解决. 1. 修改my.cnf,加入skip-grant-tables 修改mysql的配置文件my.cnf,在[mysqld] ...
- java基础之JDBC一:概述及步骤详解
1. JDBC的简介 概述: 就是Java用来操作不同数据库(DBMS)的类库(技术), 本质就是一些类和接口. /* 类: DriverManager 接口: Driver, Connection, ...
- char(10)、varchar(10)、nchar(10)、nvarchar(10)的区别
CHAR CHAR是定长的,当输入的字符小于10时,会在后面补空值,如果长度大于10,则会截取超出的字符 CHAR字段上的索引效率级高 VARCHAR 存储边长数据,但存储效率没有CHAR高 从空间上 ...
- 用Jquery实现修改页面selecte标签的默认选择
在WEB开发中,最基础的也是用的最多的就是数据库的增删改查,修改往往以为的小部分的改动,所以我们往往是在表单中填充以前的内容然后显示给用户进行修改操作. 在填充默认内容的时候对于input标签我们往往 ...