
ros的源码阅读
测试代码,使用xmlrpc与roscore通信
ros的框架是使用rpc与server端通信,server维护topic的publisher,subscriber,param server,serviceServer
import xmlrpclib

server = xmlrpclib.ServerProxy("http://localhost:11311/",verbose=False)

print server.getSystemState('/rosout')

##返回的是 [topic node ] [topic node ] [topic node ] [topic node ]
server
rosmaster/main.py
try:

    logger.info("Starting ROS Master Node")

    #定义master的端口,工作线程,启动

    master = rosmaster.master.Master(port, options.num_workers)

    master.start()

    import time

    while master.ok():

        time.sleep(.1)

except KeyboardInterrupt:

    logger.info("keyboard interrupt, will exit")

finally:

    logger.info("stopping master...")

    master.stop()
rosmaster/master.py
class Master(object):

    def __init__(self, port=DEFAULT_MASTER_PORT, num_workers=rosmaster.master_api.NUM_WORKERS):

        self.port = port

        self.num_workers = num_workers

    def start(self):

        """

        Start the ROS Master.

        """

        self.handler = None

        self.master_node = None

        self.uri = None

# self.server.register_instance(self.handler)

# 注册handler到xmlrpc,以后每次远程调用的时候,寻找ROSMasterHandler类同名称的函数进行处理返回

        handler = rosmaster.master_api.ROSMasterHandler(self.num_workers)

        master_node = rosgraph.xmlrpc.XmlRpcNode(self.port, handler)

        master_node.start()

        # poll for initialization

        while not master_node.uri:

            time.sleep(0.0001)

        # save fields

        self.handler = handler

        self.master_node = master_node

        self.uri = master_node.uri
rosmaster/master_api.py
class ROSMasterHandler(object):

    """

    XML-RPC handler for ROS master APIs.

    API routines for the ROS Master Node. The Master Node is a

    superset of the Slave Node and contains additional API methods for

    creating and monitoring a graph of slave nodes.

    By convention, ROS nodes take in caller_id as the first parameter

    of any API call.  The setting of this parameter is rarely done by

    client code as ros::msproxy::MasterProxy automatically inserts

    this parameter (see ros::client::getMaster()).

    """

    def __init__(self, num_workers=NUM_WORKERS):

        """ctor."""

        self.uri = None

        self.done = False

        self.thread_pool = rosmaster.threadpool.MarkedThreadPool(num_workers)

        # pub/sub/providers: dict { topicName : [publishers/subscribers names] }

        self.ps_lock = threading.Condition(threading.Lock())

        self.reg_manager = RegistrationManager(self.thread_pool)

        # maintain refs to reg_manager fields

        self.publishers  = self.reg_manager.publishers

        self.subscribers = self.reg_manager.subscribers

        self.services = self.reg_manager.services

        self.param_subscribers = self.reg_manager.param_subscribers

        self.topics_types = {} #dict { topicName : type }

        # parameter server dictionary

        self.param_server = rosmaster.paramserver.ParamDictionary(self.reg_manager)
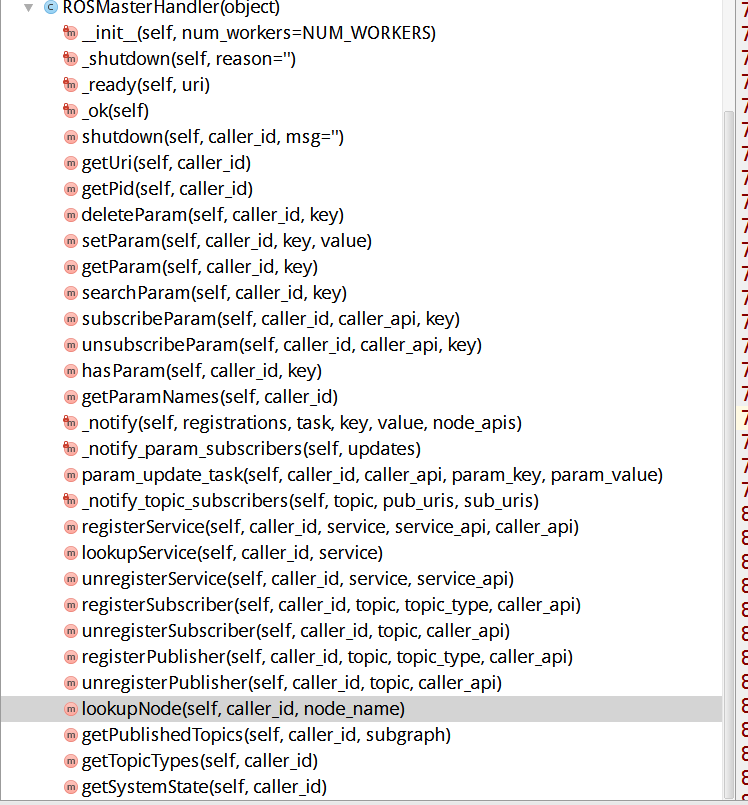
ROSMasterHandler定义的所有函数,也就是xmlrpc服务器处理的函数
rosmaster/registrations.py
class RegistrationManager(object):

    """

    Stores registrations for Master.

    RegistrationManager is not threadsafe, so access must be externally locked as appropriate

    """

    def __init__(self, thread_pool):

        """

        ctor.

        @param thread_pool: thread pool for queueing tasks

        @type  thread_pool: ThreadPool

        """

        self.nodes = {}

        self.thread_pool = thread_pool

        self.publishers  = Registrations(Registrations.TOPIC_PUBLICATIONS)

        self.subscribers = Registrations(Registrations.TOPIC_SUBSCRIPTIONS)

        self.services = Registrations(Registrations.SERVICE)

        self.param_subscribers = Registrations(Registrations.PARAM_SUBSCRIPTIONS)

   def _register(self, r, key, caller_id, caller_api, service_api=None):

        # update node information

        node_ref, changed = self._register_node_api(caller_id, caller_api)

        node_ref.add(r.type, key)

        # update pub/sub/service indicies

        if changed:

            self.publishers.unregister_all(caller_id)

            self.subscribers.unregister_all(caller_id)

            self.services.unregister_all(caller_id)

            self.param_subscribers.unregister_all(caller_id)

        r.register(key, caller_id, caller_api, service_api)

    def _unregister(self, r, key, caller_id, caller_api, service_api=None):

        node_ref = self.nodes.get(caller_id, None)

        if node_ref != None:

            retval = r.unregister(key, caller_id, caller_api, service_api)

            # check num removed field, if 1, unregister is valid

            if retval[2] == 1:

                node_ref.remove(r.type, key)

            if node_ref.is_empty():

                del self.nodes[caller_id]

        else:

            retval = 1, "[%s] is not a registered node"%caller_id, 0

        return retval
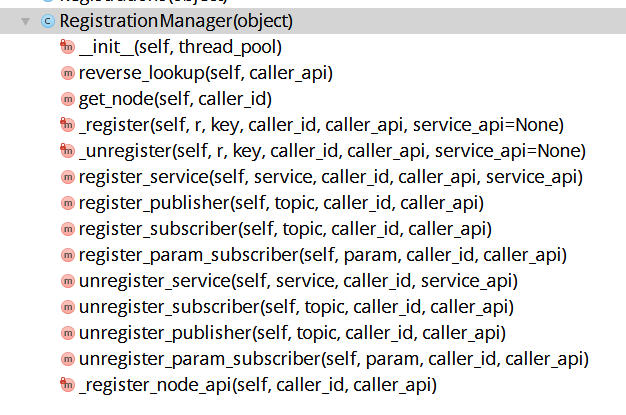
上面的publishers,subscribers,services都是由 Registrations这个类进行管理
def registerPublisher(self, caller_id, topic, topic_type, caller_api):

    """

    Register the caller as a publisher the topic.

    @param caller_id: ROS caller id

    @type  caller_id: str

    @param topic: Fully-qualified name of topic to register.

    @type  topic: str

    @param topic_type: Datatype for topic. Must be a

    package-resource name, i.e. the .msg name.

    @type  topic_type: str

    @param caller_api str: ROS caller XML-RPC API URI

    @type  caller_api: str

    @return: (code, statusMessage, subscriberApis).

    List of current subscribers of topic in the form of XMLRPC URIs.

    @rtype: (int, str, [str])

    """

    #NOTE: we need topic_type for getPublishedTopics.

    try:

        self.ps_lock.acquire()

        self.reg_manager.register_publisher(topic, caller_id, caller_api)

        # don't let '*' type squash valid typing

        if topic_type != rosgraph.names.ANYTYPE or not topic in self.topics_types:

            self.topics_types[topic] = topic_type

        pub_uris = self.publishers.get_apis(topic)

        sub_uris = self.subscribers.get_apis(topic)

#通知订阅topic的所有subscriber,回调函数

        self._notify_topic_subscribers(topic, pub_uris, sub_uris)

        mloginfo("+PUB [%s] %s %s",topic, caller_id, caller_api)

        sub_uris = self.subscribers.get_apis(topic)

    finally:

        self.ps_lock.release()

    return 1, "Registered [%s] as publisher of [%s]"%(caller_id, topic), sub_uris
caller_id 是节点,caller_api http://localhost:53749/
  def _notify(self, registrations, task, key, value, node_apis):

        """

        Generic implementation of callback notification

        @param registrations: Registrations

        @type  registrations: L{Registrations}

        @param task: task to queue

        @type  task: fn

        @param key: registration key

        @type  key: str

        @param value: value to pass to task

        @type  value: Any

        """

        # cache thread_pool for thread safety

        thread_pool = self.thread_pool

        if not thread_pool:

            return

        try:

            for node_api in node_apis:

                # use the api as a marker so that we limit one thread per subscriber

                thread_pool.queue_task(node_api, task, (node_api, key, value))

        except KeyError:

            _logger.warn('subscriber data stale (key [%s], listener [%s]): node API unknown'%(key, s))

    def _notify_param_subscribers(self, updates):

        """

        Notify parameter subscribers of new parameter value

        @param updates [([str], str, any)*]: [(subscribers, param_key, param_value)*]

        @param param_value str: parameter value

        """

        # cache thread_pool for thread safety

        thread_pool = self.thread_pool

        if not thread_pool:

            return

        for subscribers, key, value in updates:

            # use the api as a marker so that we limit one thread per subscriber

            for caller_id, caller_api in subscribers:

                self.thread_pool.queue_task(caller_api, self.param_update_task, (caller_id, caller_api, key, value))
client
def init_node(name, argv=None, anonymous=False, log_level=None, disable_rostime=False, disable_rosout=False, disable_signals=False, xmlrpc_port=0, tcpros_port=0):

class MasterProxy(object):

    """

    Convenience wrapper for ROS master API and XML-RPC

    implementation. The Master API methods can be invoked on this

    object and will be forwarded appropriately. Names in arguments

    will be remapped according to current node settings. Provides

    dictionary-like access to parameter server, e.g.::

      master[key] = value

    All methods are thread-safe.

    """
rospy 是python的客户端的实现
roscpp 是c++的客户端的实现
ros::NodeHandler构造函数执行会调用ros::start(),接下来ros的框架就起来了。
//init.cpp

namespace ros{

    void start()

    {

      PollManager::instance()->addPollThreadListener(checkForShutdown);

      XMLRPCManager::instance()->bind("shutdown", shutdownCallback);

      initInternalTimerManager();

      TopicManager::instance()->start();

      ServiceManager::instance()->start();

      ConnectionManager::instance()->start();

      PollManager::instance()->start();

      XMLRPCManager::instance()->start();

    }

};
gdb调试一个listener, talker,service ,client,可以看到每个node都起了好多线程,有专门的log thread, xmlrpc select线程,poll线程
rosgraph 是对底层的master的一个封装,用户一般不直接对他操作
ros的源码阅读的更多相关文章
- 【原】FMDB源码阅读(三)
[原]FMDB源码阅读(三) 本文转载请注明出处 —— polobymulberry-博客园 1. 前言 FMDB比较优秀的地方就在于对多线程的处理.所以这一篇主要是研究FMDB的多线程处理的实现.而 ...
- 【原】FMDB源码阅读(二)
[原]FMDB源码阅读(二) 本文转载请注明出处 -- polobymulberry-博客园 1. 前言 上一篇只是简单地过了一下FMDB一个简单例子的基本流程,并没有涉及到FMDB的所有方方面面,比 ...
- 【原】FMDB源码阅读(一)
[原]FMDB源码阅读(一) 本文转载请注明出处 —— polobymulberry-博客园 1. 前言 说实话,之前的SDWebImage和AFNetworking这两个组件我还是使用过的,但是对于 ...
- 【原】AFNetworking源码阅读(六)
[原]AFNetworking源码阅读(六) 本文转载请注明出处 —— polobymulberry-博客园 1. 前言 这一篇的想讲的,一个就是分析一下AFSecurityPolicy文件,看看AF ...
- 【原】AFNetworking源码阅读(五)
[原]AFNetworking源码阅读(五) 本文转载请注明出处 —— polobymulberry-博客园 1. 前言 上一篇中提及到了Multipart Request的构建方法- [AFHTTP ...
- 【原】AFNetworking源码阅读(四)
[原]AFNetworking源码阅读(四) 本文转载请注明出处 —— polobymulberry-博客园 1. 前言 上一篇还遗留了很多问题,包括AFURLSessionManagerTaskDe ...
- 【原】AFNetworking源码阅读(三)
[原]AFNetworking源码阅读(三) 本文转载请注明出处 —— polobymulberry-博客园 1. 前言 上一篇的话,主要是讲了如何通过构建一个request来生成一个data tas ...
- 【原】AFNetworking源码阅读(二)
[原]AFNetworking源码阅读(二) 本文转载请注明出处 —— polobymulberry-博客园 1. 前言 上一篇中我们在iOS Example代码中提到了AFHTTPSessionMa ...
- 【原】AFNetworking源码阅读(一)
[原]AFNetworking源码阅读(一) 本文转载请注明出处 —— polobymulberry-博客园 1. 前言 AFNetworking版本:3.0.4 由于我平常并没有经常使用AFNetw ...
随机推荐
- [Arduino] Arduino Uno R3 中文介绍
Arduino UNO是Arduino USB接口系列的最新版本,作为Arduino平台的参考标准模板.UNO的处理器核心是ATmega328,同时具有14路数字输入/输出口(其中6路可作为PWM输出 ...
- 沈逸老师PHP魔鬼特训笔记(4)
上一课我们通过shell脚本拷贝代码,了解了静态方法和静态属性.(还有个附件PHAR包,我直接无视了) 然后在GOD文件中写了一些参数, 我们也可以这样,把方法名像拼凑字符串一样拼起来. $get_p ...
- Sphinx 全文检索
什么是全文检索: 全文检索是指以文档的全部文本信息作为检索对象的一种信息检索技术.检索的对象有可能是文章的标题,也有可能是文章的作者,也有可能是文章摘要或内容. 简介: Sphinx是由俄罗斯人And ...
- Gulp 自动化的项目构建工具
在很多场合都会听到前端工和 node 程师推荐 Grunt 来实现项目的自动化,自动化可以自动完成 javascript/coffee/sass/less 等文件的的测试.检查.合并.压缩.格式化.部 ...
- CF Destroying Roads (最短路)
Destroying Roads time limit per test 2 seconds memory limit per test 256 megabytes input standard in ...
- 剑指Offer05 用栈模拟队列
添加了模板类应用 /************************************************************************* > File Name: ...
- /var/spool/postfix/maildrop小文件太多造成inode索引使用完解决
/var/spool/postfix/maildrop 小文件太多造成inode索引使用完解决办法 问题表现和检查: 1.运行df -i / 查看inode使用是否满: 2.查看/var/spool/ ...
- thinkphp,javascript跨域请求解决方案
javascript跨域请求解决方案 前言 对于很多前端或者做混合开发的同学,我们难免会遇到跨域发起请求业务,比如A站点向B站点请求数据等等.由于最近要做一个站点集群的项目,所以具体业务要求很多个站点 ...
- Javascript中二级联动
主要使用到到了地址JSON格式,来做,没有涉及数据库的读取. <!DOCTYPE html><html><head> <meta charset=" ...
- 【CSS3】---嵌入字体@font-face
@font-face能够加载服务器端的字体文件,让浏览器端可以显示用户电脑里没有安装的字体. 语法: @font-face { font-family : 字体名称; src : 字体文件在服务器上的 ...