
behavior planning——12.example cost funtion -lane change penalty

In the image above, the blue self driving car (bottom left) is trying to get to the goal (gold star). It's currently in the correct lane but the green car is going very slowly, so it considers whether it should perform a lane change (LC) or just keep lane (KL). These options are shown as lighter blue vehicles with a dashed outline.
If we want to design a cost function that deals with lane choice, it will be helpful to establish what the relevant variables are. In this case, we can define:
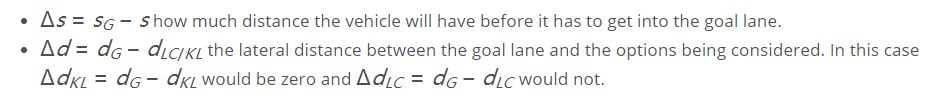
Before we define an actual cost function, let's think of some of the properties we want it to have...
习题 1/3
First, thinking only about delta d: Would we prefer the absolute value of delta d to be big or small?
Big
Small
习题 2/3
Now let's think about how s factors into our considerations of lane cost. Should costs associated with lane change be more important when we are far from the goal (in s coordinate) or close to the goal?
Far
Close
So we want a cost function that penalizes large ∣ and we want that penalty to be bigger when Δ is small.
Furthermore, we want to make sure that the maximum cost of this cost function never exceeds one and that the minimum never goes below zero.
Which of the following proposals meets these criteria?
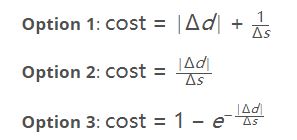
习题 3/3
Which of the options shown above meet the criteria we want (assume delta s is always positive)?
Option 1
Option 2
Option 3
In this example, we found that the ratio Δs∣Δd∣ was important. If we call that ratio x we can then use that ratio in any function with bounded range. These functions tend to be useful when designing cost functions. These types of functions are called Sigmoid Functions. You can learn more in the Wikipedia article if you're interested.
behavior planning——12.example cost funtion -lane change penalty的更多相关文章
- behavior planning——13. implement a cost function in C++
In the previous quizzes, you designed a cost function to choose a lane when trying to reach a goal i ...
- behavior planning——15.cost function design weightTweaking
Designing cost functions is difficult and getting them all to cooperate to produce reasionable vehic ...
- behavior planning——14.implement a cost function in C++
n most situations, a single cost function will not be sufficient to produce complex vehicle behavior ...
- behavior planning——11 create a cost function speed penalty
A key part of getting transitions to happen when we want them to is the design of reasonable cost ...
- behavior planning——10 behaior planning pseudocode
One way to implement a transition function is by generating rough trajectories for each accessible & ...
- behavior planning——inputs to transition functions
the answer is that we have to pass all of the data into transition function except for the previous ...
- Database Initialization Parameters for Oracle E-Business Suite Release 12 (文档 ID 396009.1)
In This Document Section 1: Common Database Initialization Parameters For All Releases Section 2: Re ...
- Database Initialization Parameters for Oracle E-Business Suite Release 12
In This Document Section 1: Common Database Initialization Parameters For All Releases Section 2: Re ...
- Goal Oriented Action Planning for a Smarter AI
Goal Oriented Action Planning for a Smarter AI by Brent Owens23 Apr 2014 Goal Oriented Action Planni ...
随机推荐
- Python实例 遍历文件夹和文件
import os import os.path # os,os.path里包含大多数文件访问的函数,所以要先引入它们. # 请按照你的实际情况修改这个路径 rootdir = &quo ...
- linux压缩打包
linux下的压缩命令有tar.gzip.gunzip.bzip2.bunzip2. compress.uncompress.zip.unzip.rar.unrar等等,压缩后的扩展名有.tar..g ...
- NOIP模拟 7.01
水灾(sliker.cpp/c/pas) 1000MS 64MB 大雨应经下了几天雨,却还是没有停的样子.土豪CCY刚从外地赚完1e元回来,知道不久除了自己别墅,其他的地方都将会被洪水淹没. CCY ...
- R语言可视化--颜色
RColorBrewer包 三类调色板:sequential / diverging / qualitative 调色板的信息可以与colorRamp / colorRampPalette结合使用 从 ...
- Mac上homebrew使用
一.官方网址 Homebrew 二.目录 安装 查看帮助信息 查看版本 更新Homebrew自己 安装软件包 查询可更新的包 更新包 (formula) 清理旧版本 锁定不想更新的包 卸载安装包 查看 ...
- [Vue CLI 3] 配置解析之 parallel
官方文档中介绍过在 vue.config.js 文件中可以配置 parallel,作用如下: 是否为 Babel 或 TypeScript 使用 thread-loader. 该选项在系统的 CPU ...
- 计算机网络 5.6-5.8 TCP/UDP
来看看传输层的位置 要点: 传输层是为两个应用进程提供端到端的通信 传输层的复用和分用 传输层与应用层就是端口 (传输层的应用访问点 TSP) 传输层与网络层之间就是协议字段(网络层的 NTSP) 端 ...
- iOS - CAReplicatorLayer 的运用
http://www.cocoachina.com/ios/20151230/14822.html 序 CAReplicatorLayer可以复制自己子层的layer,并且复制的出来的layer和原来 ...
- ORACLE 最后表数据更新的时间
SELECT SCN_TO_TIMESTAMP(MAX(ora_rowscn)) from myTable;
- 制作ACK集群自定义节点镜像的正确姿势
随着云原生时代的到来,用户应用.业务上云的需求也越来越多,不同的业务场景对容器平台的需求也不尽相同,其中一个非常重要的需求就是使用自定义镜像创建ACK集群. ACK支持用户使用自定义镜像创建Kuber ...