
[ROS]一些传感器数据读取融合问题的思考
思考问题:
1. 如何实现传感器数据的融合,或者说时间同步? 比如里程计读数和雷达数据融合?
void SlamGMapping::startLiveSlam()

{

  entropy_publisher_ = private_nh_.advertise<std_msgs::Float64>("entropy", 1, true);

  sst_ = node_.advertise<nav_msgs::OccupancyGrid>("map", 1, true);

  sstm_ = node_.advertise<nav_msgs::MapMetaData>("map_metadata", 1, true);

  ss_ = node_.advertiseService("dynamic_map", &SlamGMapping::mapCallback, this);

  scan_filter_sub_ = new message_filters::Subscriber<sensor_msgs::LaserScan>(node_, "scan", 5);

  scan_filter_ = new tf::MessageFilter<sensor_msgs::LaserScan>(*scan_filter_sub_, tf_, odom_frame_, 5);

  scan_filter_->registerCallback(boost::bind(&SlamGMapping::laserCallback, this, _1));

  transform_thread_ = new boost::thread(boost::bind(&SlamGMapping::publishLoop, this, transform_publish_period_));

}
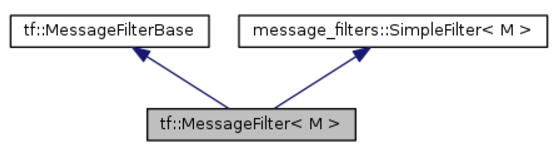
ROS中message_filters 和 tf::MessageFilter 需要关注一下。
 |
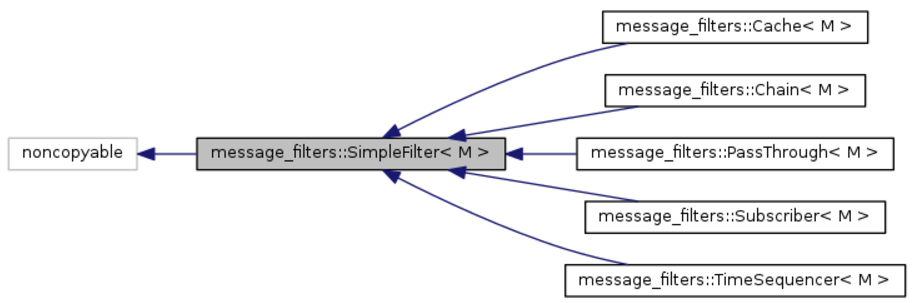 |
message_filters is a utility library for use with roscpp and rospy. It collects commonly used message "filtering" algorithms into a common space. A message filter is defined as something which a message arrives into and may or may not be spit back out of at a later point in time.
An example is the time synchronizer, which takes in messages of different types from multiple sources, and outputs them only if it has received a message on each of those sources with the same timestamp.
以下为MessageFilter泛型类执行的基本流程。
 /**

   * \brief Connect this filter's input to another filter's output.  If this filter is already connected, disconnects first.

   */

  template<class F>  void connectInput(F& f)

  {

    message_connection_.disconnect();

    message_connection_ = f.registerCallback(&MessageFilter::incomingMessage, this);

  }
 void incomingMessage(const ros::MessageEvent<M const>& evt)

  {

    add(evt);

  }
  /**

   * \brief Manually add a message into this filter.

   * \note If the message (or any other messages in the queue) are immediately transformable this will immediately call through to the output callback, possibly

   * multiple times

   */

  void add(const MConstPtr& message)

  {

    boost::shared_ptr<std::map<std::string, std::string> > header(new std::map<std::string, std::string>);

    (*header)["callerid"] = "unknown";

    add(MEvent(message, header, ros::Time::now()));

  }
 void add(const MEvent& evt)

   {

     if (target_frames_.empty())

     {

       return;

     }

     namespace mt = ros::message_traits;

     const MConstPtr& message = evt.getMessage();

     std::string frame_id = stripSlash(mt::FrameId<M>::value(*message));

     ros::Time stamp = mt::TimeStamp<M>::value(*message);

     if (frame_id.empty())

     {

       messageDropped(evt, filter_failure_reasons::EmptyFrameID);

       return;

     }

     // iterate through the target frames and add requests for each of them

     MessageInfo info;

     info.handles.reserve(expected_success_count_);

     {

       V_string target_frames_copy;

       // Copy target_frames_ to avoid deadlock from #79

       {

         boost::mutex::scoped_lock frames_lock(target_frames_mutex_);

         target_frames_copy = target_frames_;

       }

       V_string::iterator it = target_frames_copy.begin();

       V_string::iterator end = target_frames_copy.end();

       for (; it != end; ++it)

       {

         const std::string& target_frame = *it;

         tf2::TransformableRequestHandle handle = bc_.addTransformableRequest(callback_handle_, target_frame, frame_id, stamp);

         if (handle == 0xffffffffffffffffULL) // never transformable

         {

           messageDropped(evt, filter_failure_reasons::OutTheBack);

           return;

         }

         else if (handle == )

         {

           ++info.success_count;

         }

         else

         {

           info.handles.push_back(handle);

         }

         if (!time_tolerance_.isZero())

         {

           handle = bc_.addTransformableRequest(callback_handle_, target_frame, frame_id, stamp + time_tolerance_);

           if (handle == 0xffffffffffffffffULL) // never transformable

           {

             messageDropped(evt, filter_failure_reasons::OutTheBack);

             return;

           }

           else if (handle == )

           {

             ++info.success_count;

           }

           else

           {

             info.handles.push_back(handle);

           }

         }

       }

     }

     // We can transform already

     if (info.success_count == expected_success_count_)

     {

       messageReady(evt);

     }

     else

     {

       // If this message is about to push us past our queue size, erase the oldest message

       if (queue_size_ !=  && message_count_ +  > queue_size_)

       {

         // While we're using the reference keep a shared lock on the messages.

         boost::shared_lock< boost::shared_mutex > shared_lock(messages_mutex_);

         ++dropped_message_count_;

         const MessageInfo& front = messages_.front();

         TF2_ROS_MESSAGEFILTER_DEBUG("Removed oldest message because buffer is full, count now %d (frame_id=%s, stamp=%f)", message_count_,

                                 (mt::FrameId<M>::value(*front.event.getMessage())).c_str(), mt::TimeStamp<M>::value(*front.event.getMessage()).toSec());

         V_TransformableRequestHandle::const_iterator it = front.handles.begin();

         V_TransformableRequestHandle::const_iterator end = front.handles.end();

         for (; it != end; ++it)

         {

           bc_.cancelTransformableRequest(*it);

         }

         messageDropped(front.event, filter_failure_reasons::Unknown);

         // Unlock the shared lock and get a unique lock. Upgradeable lock is used in transformable.

         // There can only be one upgrade lock. It's important the cancelTransformableRequest not deadlock with transformable.

         // They both require the transformable_requests_mutex_ in BufferCore.

         shared_lock.unlock();

         // There is a very slight race condition if an older message arrives in this gap.

         boost::unique_lock< boost::shared_mutex > unique_lock(messages_mutex_);

         messages_.pop_front();

          --message_count_;

       }

       // Add the message to our list

       info.event = evt;

       // Lock access to the messages_ before modifying them.

       boost::unique_lock< boost::shared_mutex > unique_lock(messages_mutex_);

       messages_.push_back(info);

       ++message_count_;

     }

     TF2_ROS_MESSAGEFILTER_DEBUG("Added message in frame %s at time %.3f, count now %d", frame_id.c_str(), stamp.toSec(), message_count_);

     ++incoming_message_count_;

   }
完整的类代码:http://docs.ros.org/api/tf/html/c++/message__filter_8h_source.html
  /*

    2  * Copyright (c) 2008, Willow Garage, Inc.

    3  * All rights reserved.

    4  *

    5  * Redistribution and use in source and binary forms, with or without

    6  * modification, are permitted provided that the following conditions are met:

    7  *

    8  *     * Redistributions of source code must retain the above copyright

    9  *       notice, this list of conditions and the following disclaimer.

   10  *     * Redistributions in binary form must reproduce the above copyright

   11  *       notice, this list of conditions and the following disclaimer in the

   12  *       documentation and/or other materials provided with the distribution.

   13  *     * Neither the name of the Willow Garage, Inc. nor the names of its

   14  *       contributors may be used to endorse or promote products derived from

   15  *       this software without specific prior written permission.

   16  *

   17  * THIS SOFTWARE IS PROVIDED BY THE COPYRIGHT HOLDERS AND CONTRIBUTORS "AS IS"

   18  * AND ANY EXPRESS OR IMPLIED WARRANTIES, INCLUDING, BUT NOT LIMITED TO, THE

   19  * IMPLIED WARRANTIES OF MERCHANTABILITY AND FITNESS FOR A PARTICULAR PURPOSE

   20  * ARE DISCLAIMED. IN NO EVENT SHALL THE COPYRIGHT OWNER OR CONTRIBUTORS BE

   21  * LIABLE FOR ANY DIRECT, INDIRECT, INCIDENTAL, SPECIAL, EXEMPLARY, OR

   22  * CONSEQUENTIAL DAMAGES (INCLUDING, BUT NOT LIMITED TO, PROCUREMENT OF

   23  * SUBSTITUTE GOODS OR SERVICES; LOSS OF USE, DATA, OR PROFITS; OR BUSINESS

   24  * INTERRUPTION) HOWEVER CAUSED AND ON ANY THEORY OF LIABILITY, WHETHER IN

   25  * CONTRACT, STRICT LIABILITY, OR TORT (INCLUDING NEGLIGENCE OR OTHERWISE)

   26  * ARISING IN ANY WAY OUT OF THE USE OF THIS SOFTWARE, EVEN IF ADVISED OF THE

   27  * POSSIBILITY OF SUCH DAMAGE.

   28  */

    #ifndef TF_MESSAGE_FILTER_H

    #define TF_MESSAGE_FILTER_H

    #include <ros/ros.h>

    #include <tf/transform_listener.h>

    #include <tf/tfMessage.h>

    #include <string>

    #include <list>

    #include <vector>

    #include <boost/function.hpp>

    #include <boost/bind.hpp>

    #include <boost/shared_ptr.hpp>

    #include <boost/weak_ptr.hpp>

    #include <boost/thread.hpp>

    #include <boost/signals2.hpp>

    #include <ros/callback_queue.h>

    #include <message_filters/connection.h>

    #include <message_filters/simple_filter.h>

    #define TF_MESSAGEFILTER_DEBUG(fmt, ...) \

      ROS_DEBUG_NAMED("message_filter", "MessageFilter [target=%s]: " fmt, getTargetFramesString().c_str(), __VA_ARGS__)

    #define TF_MESSAGEFILTER_WARN(fmt, ...) \

      ROS_WARN_NAMED("message_filter", "MessageFilter [target=%s]: " fmt, getTargetFramesString().c_str(), __VA_ARGS__)

    namespace tf

    {

    namespace filter_failure_reasons

    {

    enum FilterFailureReason

    {

      Unknown,

      OutTheBack,

      EmptyFrameID,

    };

    }

    typedef filter_failure_reasons::FilterFailureReason FilterFailureReason;

    class MessageFilterBase

    {

    public:

      virtual ~MessageFilterBase(){}

      virtual void clear() = ;

      virtual void setTargetFrame(const std::string& target_frame) = ;

      virtual void setTargetFrames(const std::vector<std::string>& target_frames) = ;

      virtual void setTolerance(const ros::Duration& tolerance) = ;

      virtual void setQueueSize( uint32_t new_queue_size ) = ;

      virtual uint32_t getQueueSize() = ;

    };

   template<class M>

   class MessageFilter : public MessageFilterBase, public message_filters::SimpleFilter<M>

   {

   public:

     typedef boost::shared_ptr<M const> MConstPtr;

     typedef ros::MessageEvent<M const> MEvent;

     typedef boost::function<void(const MConstPtr&, FilterFailureReason)> FailureCallback;

     typedef boost::signals2::signal<void(const MConstPtr&, FilterFailureReason)> FailureSignal;

     MessageFilter(Transformer& tf, const std::string& target_frame, uint32_t queue_size, ros::NodeHandle nh = ros::NodeHandle(), ros::Duration max_rate = ros::Duration(0.01))

     : tf_(tf)

     , nh_(nh)

     , max_rate_(max_rate)

     , queue_size_(queue_size)

     {

       init();

       setTargetFrame(target_frame);

     }

     template<class F>

     MessageFilter(F& f, Transformer& tf, const std::string& target_frame, uint32_t queue_size, ros::NodeHandle nh = ros::NodeHandle(), ros::Duration max_rate = ros::Duration(0.01))

     : tf_(tf)

     , nh_(nh)

     , max_rate_(max_rate)

     , queue_size_(queue_size)

     {

       init();

       setTargetFrame(target_frame);

       connectInput(f);

     }

     template<class F>

     void connectInput(F& f)

     {

       message_connection_.disconnect();

       message_connection_ = f.registerCallback(&MessageFilter::incomingMessage, this);

     }

     ~MessageFilter()

     {

       // Explicitly stop callbacks; they could execute after we're destroyed

       max_rate_timer_.stop();

       message_connection_.disconnect();

       tf_.removeTransformsChangedListener(tf_connection_);

       clear();

       TF_MESSAGEFILTER_DEBUG("Successful Transforms: %llu, Failed Transforms: %llu, Discarded due to age: %llu, Transform messages received: %llu, Messages received: %llu, Total dropped: %llu",

                              (long long unsigned int)successful_transform_count_, (long long unsigned int)failed_transform_count_,

                              (long long unsigned int)failed_out_the_back_count_, (long long unsigned int)transform_message_count_,

                              (long long unsigned int)incoming_message_count_, (long long unsigned int)dropped_message_count_);

     }

     void setTargetFrame(const std::string& target_frame)

     {

       std::vector<std::string> frames;

       frames.push_back(target_frame);

       setTargetFrames(frames);

     }

     void setTargetFrames(const std::vector<std::string>& target_frames)

     {

       boost::mutex::scoped_lock list_lock(messages_mutex_);

       boost::mutex::scoped_lock string_lock(target_frames_string_mutex_);

       target_frames_ = target_frames;

       std::stringstream ss;

       for (std::vector<std::string>::iterator it = target_frames_.begin(); it != target_frames_.end(); ++it)

       {

         ss << *it << " ";

       }

       target_frames_string_ = ss.str();

     }

     std::string getTargetFramesString()

     {

       boost::mutex::scoped_lock lock(target_frames_string_mutex_);

       return target_frames_string_;

     };

     void setTolerance(const ros::Duration& tolerance)

     {

       time_tolerance_ = tolerance;

     }

     void clear()

     {

       boost::mutex::scoped_lock lock(messages_mutex_);

       TF_MESSAGEFILTER_DEBUG("%s", "Cleared");

       messages_.clear();

       message_count_ = ;

       warned_about_unresolved_name_ = false;

       warned_about_empty_frame_id_ = false;

     }

     void add(const MEvent& evt)

     {

       boost::mutex::scoped_lock lock(messages_mutex_);

       testMessages();

       if (!testMessage(evt))

       {

         // If this message is about to push us past our queue size, erase the oldest message

         if (queue_size_ !=  && message_count_ +  > queue_size_)

         {

           ++dropped_message_count_;

           const MEvent& front = messages_.front();

           TF_MESSAGEFILTER_DEBUG(

                 "Removed oldest message because buffer is full, count now %d (frame_id=%s, stamp=%f)",

                 message_count_,

                 ros::message_traits::FrameId<M>::value(*front.getMessage()).c_str(),

                 ros::message_traits::TimeStamp<M>::value(*front.getMessage()).toSec());

           signalFailure(messages_.front(), filter_failure_reasons::Unknown);

           messages_.pop_front();

           --message_count_;

         }

         // Add the message to our list

         messages_.push_back(evt);

         ++message_count_;

       }

       TF_MESSAGEFILTER_DEBUG(

             "Added message in frame %s at time %.3f, count now %d",

             ros::message_traits::FrameId<M>::value(*evt.getMessage()).c_str(),

             ros::message_traits::TimeStamp<M>::value(*evt.getMessage()).toSec(),

             message_count_);

       ++incoming_message_count_;

     }

     void add(const MConstPtr& message)

     {

       boost::shared_ptr<std::map<std::string, std::string> > header(new std::map<std::string, std::string>);

       (*header)["callerid"] = "unknown";

       add(MEvent(message, header, ros::Time::now()));

     }

     message_filters::Connection registerFailureCallback(const FailureCallback& callback)

     {

       boost::mutex::scoped_lock lock(failure_signal_mutex_);

       return message_filters::Connection(boost::bind(&MessageFilter::disconnectFailure, this, _1), failure_signal_.connect(callback));

     }

     virtual void setQueueSize( uint32_t new_queue_size )

     {

       queue_size_ = new_queue_size;

     }

     virtual uint32_t getQueueSize()

     {

       return queue_size_;

     }

   private:

     void init()

     {

       message_count_ = ;

       new_transforms_ = false;

       successful_transform_count_ = ;

       failed_transform_count_ = ;

       failed_out_the_back_count_ = ;

       transform_message_count_ = ;

       incoming_message_count_ = ;

       dropped_message_count_ = ;

       time_tolerance_ = ros::Duration(0.0);

       warned_about_unresolved_name_ = false;

       warned_about_empty_frame_id_ = false;

       tf_connection_ = tf_.addTransformsChangedListener(boost::bind(&MessageFilter::transformsChanged, this));

       max_rate_timer_ = nh_.createTimer(max_rate_, &MessageFilter::maxRateTimerCallback, this);

     }

     typedef std::list<MEvent> L_Event;

     bool testMessage(const MEvent& evt)

     {

       const MConstPtr& message = evt.getMessage();

       std::string callerid = evt.getPublisherName();

       std::string frame_id = ros::message_traits::FrameId<M>::value(*message);

       ros::Time stamp = ros::message_traits::TimeStamp<M>::value(*message);

       //Throw out messages which have an empty frame_id

       if (frame_id.empty())

       {

         if (!warned_about_empty_frame_id_)

         {

           warned_about_empty_frame_id_ = true;

           TF_MESSAGEFILTER_WARN("Discarding message from [%s] due to empty frame_id.  This message will only print once.", callerid.c_str());

         }

         signalFailure(evt, filter_failure_reasons::EmptyFrameID);

         return true;

       }

       //Throw out messages which are too old

       for (std::vector<std::string>::iterator target_it = target_frames_.begin(); target_it != target_frames_.end(); ++target_it)

       {

         const std::string& target_frame = *target_it;

         if (target_frame != frame_id && stamp != ros::Time())

         {

           ros::Time latest_transform_time ;

           tf_.getLatestCommonTime(frame_id, target_frame, latest_transform_time, ) ;

           if (stamp + tf_.getCacheLength() < latest_transform_time)

           {

             ++failed_out_the_back_count_;

             ++dropped_message_count_;

             TF_MESSAGEFILTER_DEBUG(

                   "Discarding Message, in frame %s, Out of the back of Cache Time "

                   "(stamp: %.3f + cache_length: %.3f < latest_transform_time %.3f. "

                   "Message Count now: %d",

                   ros::message_traits::FrameId<M>::value(*message).c_str(),

                   ros::message_traits::TimeStamp<M>::value(*message).toSec(),

                   tf_.getCacheLength().toSec(), latest_transform_time.toSec(), message_count_);

             last_out_the_back_stamp_ = stamp;

             last_out_the_back_frame_ = frame_id;

             signalFailure(evt, filter_failure_reasons::OutTheBack);

             return true;

           }

         }

       }

       bool ready = !target_frames_.empty();

       for (std::vector<std::string>::iterator target_it = target_frames_.begin(); ready && target_it != target_frames_.end(); ++target_it)

       {

         std::string& target_frame = *target_it;

         if (time_tolerance_ != ros::Duration(0.0))

         {

           ready = ready && (tf_.canTransform(target_frame, frame_id, stamp) &&

                             tf_.canTransform(target_frame, frame_id, stamp + time_tolerance_) );

         }

         else

         {

           ready = ready && tf_.canTransform(target_frame, frame_id, stamp);

         }

       }

       if (ready)

       {

         TF_MESSAGEFILTER_DEBUG("Message ready in frame %s at time %.3f, count now %d", frame_id.c_str(), stamp.toSec(), message_count_);

         ++successful_transform_count_;

         this->signalMessage(evt);

       }

       else

       {

         ++failed_transform_count_;

       }

       return ready;

     }

     void testMessages()

     {

       if (!messages_.empty() && getTargetFramesString() == " ")

       {

         ROS_WARN_NAMED("message_notifier", "MessageFilter [target=%s]: empty target frame", getTargetFramesString().c_str());

       }

       int i = ;

       typename L_Event::iterator it = messages_.begin();

       for (; it != messages_.end(); ++i)

       {

         MEvent& evt = *it;

         if (testMessage(evt))

         {

           --message_count_;

           it = messages_.erase(it);

         }

         else

         {

           ++it;

         }

       }

     }

     void maxRateTimerCallback(const ros::TimerEvent&)

     {

       boost::mutex::scoped_lock list_lock(messages_mutex_);

       if (new_transforms_)

       {

         testMessages();

         new_transforms_ = false;

       }

       checkFailures();

     }

     void incomingMessage(const ros::MessageEvent<M const>& evt)

     {

       add(evt);

     }

     void transformsChanged()

     {

       new_transforms_ = true;

       ++transform_message_count_;

     }

     void checkFailures()

     {

       if (next_failure_warning_.isZero())

       {

         next_failure_warning_ = ros::Time::now() + ros::Duration();

       }

       if (ros::Time::now() >= next_failure_warning_)

       {

         if (incoming_message_count_ - message_count_ == )

         {

           return;

         }

         double dropped_pct = (double)dropped_message_count_ / (double)(incoming_message_count_ - message_count_);

         if (dropped_pct > 0.95)

         {

           TF_MESSAGEFILTER_WARN("Dropped %.2f%% of messages so far. Please turn the [%s.message_notifier] rosconsole logger to DEBUG for more information.", dropped_pct*, ROSCONSOLE_DEFAULT_NAME);

           next_failure_warning_ = ros::Time::now() + ros::Duration();

           if ((double)failed_out_the_back_count_ / (double)dropped_message_count_ > 0.5)

           {

             TF_MESSAGEFILTER_WARN("  The majority of dropped messages were due to messages growing older than the TF cache time.  The last message's timestamp was: %f, and the last frame_id was: %s", last_out_the_back_stamp_.toSec(), last_out_the_back_frame_.c_str());

           }

         }

       }

     }

     void disconnectFailure(const message_filters::Connection& c)

     {

       boost::mutex::scoped_lock lock(failure_signal_mutex_);

       c.getBoostConnection().disconnect();

     }

     void signalFailure(const MEvent& evt, FilterFailureReason reason)

     {

       boost::mutex::scoped_lock lock(failure_signal_mutex_);

       failure_signal_(evt.getMessage(), reason);

     }

     Transformer& tf_;

     ros::NodeHandle nh_;

     ros::Duration max_rate_;

     ros::Timer max_rate_timer_;

     std::vector<std::string> target_frames_;

     std::string target_frames_string_;

     boost::mutex target_frames_string_mutex_;

     uint32_t queue_size_;

     L_Event messages_;

     uint32_t message_count_;

     boost::mutex messages_mutex_;

     bool new_messages_;

     volatile bool new_transforms_;

     bool warned_about_unresolved_name_;

     bool warned_about_empty_frame_id_;

     uint64_t successful_transform_count_;

     uint64_t failed_transform_count_;

     uint64_t failed_out_the_back_count_;

     uint64_t transform_message_count_;

     uint64_t incoming_message_count_;

     uint64_t dropped_message_count_;

     ros::Time last_out_the_back_stamp_;

     std::string last_out_the_back_frame_;

     ros::Time next_failure_warning_;

     ros::Duration time_tolerance_;

     boost::signals2::connection tf_connection_;

     message_filters::Connection message_connection_;

     FailureSignal failure_signal_;

     boost::mutex failure_signal_mutex_;

   };

   } // namespace tf

   #endif
TF_MESSAGE_FILTER
 bool

 Buffer::canTransform(const std::string& target_frame, const std::string& source_frame,

                      const ros::Time& time, const ros::Duration timeout, std::string* errstr) const

 {

   if (!checkAndErrorDedicatedThreadPresent(errstr))

     return false;

   // poll for transform if timeout is set

   ros::Time start_time = now_fallback_to_wall();

   while (now_fallback_to_wall() < start_time + timeout &&

          !canTransform(target_frame, source_frame, time) &&

          (now_fallback_to_wall()+ros::Duration(3.0) >= start_time) &&  //don't wait when we detect a bag loop

          (ros::ok() || !ros::isInitialized())) // Make sure we haven't been stopped (won't work for pytf)

     {

       sleep_fallback_to_wall(ros::Duration(0.01));

     }

   bool retval = canTransform(target_frame, source_frame, time, errstr);

   conditionally_append_timeout_info(errstr, start_time, timeout);

   return retval;

 }

 ros::Time now_fallback_to_wall()

 {

   try

   {

     return ros::Time::now();

   }

   catch (ros::TimeNotInitializedException ex)

   {

     ros::WallTime wt = ros::WallTime::now();

     return ros::Time(wt.sec, wt.nsec);

   }

 }
#include "tf2_ros/buffer.h"
2.ROS中的消息发布与订阅机制为啥不需要线程锁?
[ROS]一些传感器数据读取融合问题的思考的更多相关文章
- uart 超声波传感器数据读取
传感器选择 淘宝上搜索 US-100 , 价格大概在17块人民币左右. 读取数据的代码如下: // include/aplex_tty.h #ifndef _APLEX_TTY_H__ #define ...
- 【Raspberry Pi】DHT11 温度湿度传感器数据读取
时序图参考厂家说明书:DHT11数字湿温度传感器的原理和应用范例 四个阵脚连接:VCC接3.3伏电源,Dout接GPIO口,我接的是物理12针脚,NC留空,GND接地. 波折1:电阻被错接进了VCC, ...
- STC15系列通用-STC15F2K60S2/STCW4K32S4读取DHT11温湿度传感器数据串口输出代码实例工程免费下载
//为了方便大家调试,另附程序工程共大家下载,下载地址:https://www.90pan.com/b1908750 //************************** //程序说明:stc ...
- 基于uFUN开发板的心率计(一)DMA方式获取传感器数据
前言 从3月8号收到板子,到今天算起来,uFUN到手也有两周的时间了,最近利用下班后的时间,做了个心率计,从单片机程序到上位机开发,到现在为止完成的差不多了,实现很简单,uFUN开发板外加一个Puls ...
- OleDbDataReader快速数据读取方式
查询得到OleDbDataReader后,有三种方式支持数据读取,如下: //方法一**速度中等 OleDbDataReader reader = command.ExecuteReader(); w ...
- DataTable to Excel(使用NPOI、EPPlus将数据表中的数据读取到excel格式内存中)
/// <summary> /// DataTable to Excel(将数据表中的数据读取到excel格式内存中) /// </summary> /// <param ...
- geotrellis使用(二)geotrellis-chatta-demo以及geotrellis框架数据读取方式初探
在上篇博客(geotrellis使用初探)中简单介绍了geotrellis-chatta-demo的大致工作流程,但是有一个重要的问题就是此demo如何调取数据进行瓦片切割分析处理等并未说明,经过几天 ...
- GPS数据读取与处理
GPS数据读取与处理 GPS模块简介 SiRF芯片在2004年发布的最新的第三代芯片SiRFstar III(GSW 3.0/3.1),使得民用GPS芯片在性能方面登上了一个顶峰,灵敏度比以前的产品大 ...
- 【原】Learning Spark (Python版) 学习笔记(二)----键值对、数据读取与保存、共享特性
本来应该上周更新的,结果碰上五一,懒癌发作,就推迟了 = =.以后还是要按时完成任务.废话不多说,第四章-第六章主要讲了三个内容:键值对.数据读取与保存与Spark的两个共享特性(累加器和广播变量). ...
随机推荐
- 四、K3 Cloud 开发插件《K3 Cloud事件、方法、函数》
1.简单帐表/动态表单几个主要事件 //初始化 public override void Initialize() //构建动态列 public override BOS.Core.Report.Re ...
- javascript基础学习系列-原型链模式
1.demo代码如下: 2.画图如下: 3.规则: 1)每一个函数数据类型(普通函数/类)都有一个天生自带的属性:prototype(原型),并且这个属性是一个对象数据类型的值 2)并且prototy ...
- PAT甲级1052 Linked List Sorting
题目:https://pintia.cn/problem-sets/994805342720868352/problems/994805425780670464 题意: 给定一些内存中的节点的地址,值 ...
- 关于html中input组件间空隙的去除
有空隙的时候的代码是这样的: <input type="text" name="search" title="请输入要搜索的内容" s ...
- 腾讯云服务器部署FTP
腾讯云服务器,在申请成功后就可以使用远程桌面了. FTP服务器端软件 下载地址:https://filezilla-project.org/download.php?type=server FTP客户 ...
- TensorRT 不支持Tensorflow的操作有如下
tf.unpack, tf.slice, tf.tile, tf.expand_dims, tf.fill, tf.cast, tf.floor_div, tf.range 比较坑,所以你必须限制你的 ...
- arcgis10.4 server第一次发布地图报错:We were unable to connect to...Error:Proxy server got bad address...
arcgis 10.4发布地图跟10.2不一样.server url里的http要改为https,否则就会连接不上.
- 遇到问题无法在线上 debug,难道只能通过加日志再重新发布吗? 线上遇到某个用户的数据处理有问题,但线上同样无法 debug,线下无法重现! 是否有一个全局视角来查看系统的运行状况? 有什么办法可以监控到JVM的实时运行状态?
https://alibaba.github.io/arthas/ Arthas 是Alibaba开源的Java诊断工具,深受开发者喜爱. 当你遇到以下类似问题而束手无策时,Arthas可以帮助你解决 ...
- static的含义
static的含义:(1)设置变量的存储域,函数体内static变量的作用范围为该函数体,不同于auto变量,该变量的内存只被分配一次,因此其值在下次调用时仍持上次的值:(2)限制变量的作用域,在模块 ...
- xcode工程编译错误:"An instance 0xca90200 of class UITableView was deallocated while key value observers were still registered with it"
An instance 0xca90200 of class UITableView was deallocated while key value observers were still regi ...