
Calculate CAN bit timing parameters -- STM32
Calculate CAN bit timing parameters
Calculate CAN bit timing parameters
typedef struct

{

  //char name[ 16 ];                // Name of the CAN controller hardware

  //uint32_t ref_clk;               // CAN system clock frequency in Hz

  //uint32_t sjw_max;               // Synchronisation jump width

  uint32_t brp_min;                 // Bit-rate prescaler

  uint32_t brp_max;

  uint32_t brp_inc;

  uint32_t tseg1_min;               // Time segement 1 = prop_seg + phase_seg1

  uint32_t tseg1_max;

  uint32_t tseg2_min;               // Time segement 2 = phase_seg2

  uint32_t tseg2_max;

} CAN_BitTimingConst_TypeDef;

typedef struct

{

  uint32_t ref_clk;                 // CAN system clock frequency in Hz

  uint32_t bitrate;                 // Bit-rate in bits/second

  uint32_t sample_point;            // Sample point in one-tenth of a percent

  uint32_t brp;                     // Bit-rate prescaler

  uint32_t tq;                      // Time quanta (TQ) in nanoseconds

  uint32_t tseg1;                   // Time segement 1 = prop_seg + phase_seg1

  uint32_t tseg2;                   // Time segement 2 = phase_seg2

  uint32_t sjw;                     // Synchronisation jump width in TQs

//uint32_t prop_seg;                // Propagation segment in TQs

//uint32_t phase_seg1;              // Phase buffer segment 1 in TQs

//uint32_t phase_seg2;              // Phase buffer segment 2 in TQs

} CAN_BitTiming_TypeDef;
#define CAN_CALC_MAX_ERROR 50   // in one-tenth of a percent

int32_t CAN_UpdateSamplePoint( CAN_BitTimingConst_TypeDef *btc,

  int32_t sampl_pt, int32_t tseg, int32_t *tseg1, int32_t *tseg2 )

{

  *tseg2 = tseg +  - ( sampl_pt * ( tseg +  ) ) / ;

  if ( *tseg2 < btc->tseg2_min )

    *tseg2 = btc->tseg2_min;

  if ( *tseg2 > btc->tseg2_max )

    *tseg2 = btc->tseg2_max;

  *tseg1 = tseg - *tseg2;

  if ( *tseg1 > btc->tseg1_max )

  {

    *tseg1 = btc->tseg1_max;

    *tseg2 = tseg - *tseg1;

  }

  return  * ( tseg +  - *tseg2 ) / ( tseg +  );

}

// CIA Sample Point : 75.0% : Speed > 800000

// CIA Sample Point : 80.0% : Speed > 500000

// CIA Sample Point : 87.5% : Speed <= 500000

uint32_t CAN_CIA_SamplePoint( uint32_t bitrate )

{

  uint32_t sampl_pt;

  if ( bitrate >  )

    sampl_pt = ;

  else if ( bitrate >  )

    sampl_pt = ;

  else

    sampl_pt = ;

  return sampl_pt;

}

int32_t CAN_CalcBitTiming( CAN_BitTimingConst_TypeDef *btc,

  CAN_BitTiming_TypeDef *bt )

{

  uint64_t v64;

  int32_t rate = ;

  int32_t best_error = , error = ;

  int32_t best_tseg = , best_brp = , brp = ;

  int32_t tsegall, tseg = , tseg1 = , tseg2 = ;

  int32_t spt_error = , spt = , sampl_pt;

  // Use gived sample points

  if ( bt->sample_point )

    sampl_pt = bt->sample_point;

  else

    // Use CIA recommended sample points

    sampl_pt = CAN_CIA_SamplePoint( bt->bitrate );

  // tseg even = round down, odd = round up

  for ( tseg = ( btc->tseg1_max + btc->tseg2_max ) *  + ;

      tseg >= ( btc->tseg1_min + btc->tseg2_min ) * ; tseg-- )

  {

    tsegall =  + tseg / ;

    // Compute all possible tseg choices (tseg=tseg1+tseg2)

    brp = bt->ref_clk / ( tsegall * bt->bitrate ) + tseg % ;

    // chose brp step which is possible in system

    brp = ( brp / btc->brp_inc ) * btc->brp_inc;

    if ( ( brp < btc->brp_min ) || ( brp > btc->brp_max ) )

      continue;

    rate = bt->ref_clk / ( brp * tsegall );

    error = bt->bitrate - rate;

    // tseg brp biterror

    if ( error <  )

      error = -error;

    if ( error > best_error )

      continue;

    best_error = error;

    if ( error ==  )

    {

      spt = CAN_UpdateSamplePoint( btc, sampl_pt, tseg / , &tseg1, &tseg2 );

      error = sampl_pt - spt;

      if ( error <  )

        error = -error;

      if ( error > spt_error )

        continue;

      spt_error = error;

    }

    best_tseg = tseg / ;

    best_brp = brp;

    if ( error ==  )

      break;

  }

  if ( best_error )

  {

    /* Error in one-tenth of a percent */

    error = ( best_error *  ) / bt->bitrate;

    if ( error > CAN_CALC_MAX_ERROR )

    {

      // error ( "bitrate error %ld.%ld%% too high\n", error / 10, error % 10 );

      return DRIVER_ERROR_PARAMETER;

    }

    else

    {

      // warn( "bitrate error %ld.%ld%%\n", error / 10,  error % 10 );

    }

  }

  v64 = ( (uint64_t) best_brp * 1000000000UL ) / bt->ref_clk;

  bt->tq = (uint32_t) v64;

  bt->brp = best_brp;

  bt->tseg2 = tseg2;

  bt->tseg1 = tseg1;

  bt->sjw = ;

  // bt->prop_seg = tseg1 / 2;

  // bt->phase_seg1 = tseg1 - bt->prop_seg;

  // bt->phase_seg2 = tseg2;

  // real bit-rate

  bt->bitrate = bt->ref_clk / ( bt->brp * ( tseg1 + tseg2 +  ) );

  // real sample point

  bt->sample_point = CAN_UpdateSamplePoint( btc, sampl_pt, best_tseg, &tseg1,

    &tseg2 );

  return DRIVER_OK;

}
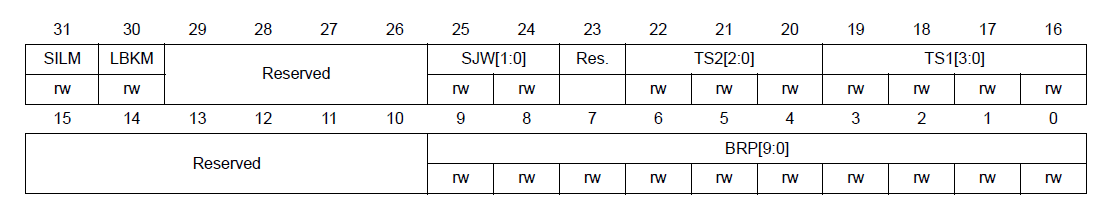
SJW[1:0]: Resynchronization jump width
These bits define the maximum number of time quanta the CAN hardware
is allowed to lengthen or shorten a bit to perform the resynchronization.
tRJW = tq x (SJW[1:0] + 1)
TS2[2:0]: Time segment 2
These bits define the number of time quanta in Time Segment 2.
tBS2 = tq x (TS2[2:0] + 1)
TS1[3:0]: Time segment 1
These bits define the number of time quanta in Time Segment 1
tBS1 = tq x (TS1[3:0] + 1)
BRP[9:0]: Baud rate prescaler
These bits define the length of a time quanta.
tq = (BRP[9:0]+1) x tPCLK
const CAN_BitTimingConst_TypeDef CAN_BitTimingConst =

{ ,    // Bit-rate prescaler Min

  , // Bit-rate prescaler Max

  ,    // Bit-rate prescaler Inc

  ,    // Time segement 1 = prop_seg + phase_seg1 Min

  ,   // Time segement 1 = prop_seg + phase_seg1 Max

  ,    // Time segement 2 = phase_seg2 Min

  ,    // Time segement 2 = phase_seg2 Max

  };

static int32_t CAN_SetSpeed( CAN_Controller_TypeDef *can, uint32_t speed )

{

  int32_t RetValue = CAN_EnterInit( can );

  if ( RetValue != DRIVER_OK )

    return RetValue;

  uint32_t Freq = can->freq( );

  CAN_BitTiming_TypeDef CAN_BitTiming;

  CAN_BitTiming.ref_clk = Freq;

  CAN_BitTiming.bitrate = speed;                // be updated to real speed
  CAN_BitTiming.sample_point = 0;               // be updated to real spt

  RetValue = CAN_CalcBitTiming( &CAN_BitTimingConst, &CAN_BitTiming );

  if ( RetValue == DRIVER_OK )

  {

    can->info->speed = CAN_BitTiming.bitrate;   // updated

    uint32_t BTR = can->reg->BTR & 0xC0000000;  // SILM|LBKM

    BTR |= ( ( CAN_BitTiming.brp -  ) <<  )   // BRP

    | ( ( CAN_BitTiming.tseg1 ) <<  )         // TS1

      | ( ( CAN_BitTiming.tseg2 -  ) <<  )   // TS2

      | ( ( CAN_BitTiming.sjw -  ) <<  );    // SJW

    can->reg->BTR = BTR;

  }

  return CAN_LeaveInit( can );
/*                           BPR TSEG1 TSEG2 */

/*  36 MHz    1 Mbps  */   { ,  , },  // 75%

/*  36 MHz  800 Kbps  */   { , , },  // 80%

/*  36 MHz  500 Kbps  */   { , , },  // 83.3%

/*  36 MHz  250 Kbps  */   { , , },  // 87.5%

/*  36 MHz  125 Kbps  */   {, , },  // 87.5%

/*  36 MHz  100 Kbps  */   {, , },  // 86.6%

/*  36 MHz 83.3 Kbps  */   {, , },  // 83.3%

/*  36 MHz 62.5 Kbps  */   {, , },  // 87.5%

/*  36 MHz  50 Kbps   */   {, , },  // 87.5%

/*  36 MHz  20 Kbps   */   {,, },  // 86.6%

/*  36 MHz  10 Kbps   */   {,, },  // 87.5%

/*  36 MHz  500 Kbps  */   { , , }   // 83.3%
Calculate CAN bit timing parameters -- STM32的更多相关文章
- Calculate CAN bit timing parameters
Calculate CAN bit timing parameters TSYNC_SEG === 1 TSEG1 = Prop_Seg + Phase_Seg1 TSEG2 = Phase_Seg2 ...
- 0xWS2812 STM32 driver for WS2812(B) RGB LEDs
0xWS2812 STM32 driver for WS2812(B) RGB LEDs 0xWS2812 pronounced "hex-WS2812" This code ai ...
- CRT/LCD/VGA Information and Timing
彩色阴极射线管的剖面图: 1. 电子QIANG Three Electron guns (for red, green, and blue phosphor dots)2. 电子束 Electron ...
- CRT/LCD/VGA Information and Timing【转】
转自:http://www.cnblogs.com/shangdawei/p/4760933.html 彩色阴极射线管的剖面图: 1. 电子QIANG Three Electron guns (for ...
- CALayer之 customizing timing of an animation
customizing timing of an animation Timing is an important part of animations, and with Core Animatio ...
- RFID 读写器 Reader Writer Cloner
RFID读写器的工作原理 RFID的数据采集以读写器为主导,RFID读写器是一种通过无线通信,实现对标签识别和内存数据的读出和写入操作的装置. 读写器又称为阅读器或读头(Reader).查询器(Int ...
- RFID Reader 线路图收集
This 125 kHz RFID reader http://www.serasidis.gr/circuits/RFID_reader/125kHz_RFID_reader.htm http:// ...
- BlackArch-Tools
BlackArch-Tools 简介 安装在ArchLinux之上添加存储库从blackarch存储库安装工具替代安装方法BlackArch Linux Complete Tools List 简介 ...
- Timequest静态时序分析(STA)基础
Setup Slack Hold Slack Recovery&Removal Recovery: The minimum time an asynchronous signal must b ...
随机推荐
- c++刷题(33/100)笔试题1
笔试总共2小时,三道题,时间挺充裕的,但是最后只做了一道,原因在于自己很浮躁,不审题,不仔细思考.没过的两道都是稍微改一下代码就能过,但是没过就是没过,要引以为戒 题目1: 小W有一个电子时钟用于显示 ...
- DSO 优化代码中的 Schur Complement
接上一篇博客<直接法光度误差导数推导>,DSO 代码中 CoarseInitializer::trackFrame 目的是优化两帧(ref frame 和 new frame)之间的相对状 ...
- lucene入门创建索引——(二)
1.程序宏观结构图
- 谁在call我-backtrace的实现原理【转】
转自:http://www.xuebuyuan.com/1504689.html 显示函数调用关系(backtrace/callstack)是调试器必备的功能之一,比如在gdb里,用bt命令就可以查看 ...
- 【译】ASP.NET Identity Core 从零开始
原文出自Rui Figueiredo的博客,原文链接<ASP.NET Identity Core From Scratch> 译者注:这篇博文发布时正值Asp.Net Core 1.1 时 ...
- 洛谷 2257 - YY的GCD
莫比乌斯反演半模板题 很容易可以得到 \[Ans = \sum\limits_{p \in prime} \sum\limits_{d = 1}^{\min (\left\lfloor\frac{a} ...
- Qt 数字和字符处理总结
1. 四舍五入保留小数几位 QString str="12.3456789"; double d1=str.toDouble(); qDebug()<<"d1 ...
- cat集成项目所遇到的一些坑
第一个问题:(jar包依赖冲突) 启动报错,直接贴log zhengxin-third-shanghai-cis [2017-08-21 14:17:49] 56231 WARN [main] - A ...
- 【hadoop】har://
来源:http://hadoop.apache.org/docs/r1.0.4/cn/hadoop_archives.html 在hadoop代码中发现了一个很奇怪的路径,由har://开头.经查询, ...
- 最小二乘法 及python 实现
参考 最小二乘法小结 机器学习:Python 中如何使用最小二乘法 什么是” 最小二乘法” 呢 定义:最小二乘法(又称最小平方法)是一种数学优化技术,它通过最小化误差的平方和寻找数据的最佳 ...