
ros nodelet 使用
ros nodelet能够加快高吞吐量程序运行速度比如点云
基本入门程序可以看
http://wiki.ros.org/nodelet/Tutorials/Porting%20nodes%20to%20nodelets
http://wiki.ros.org/nodelet
什么是nodelet,nodelet有什么用处
https://answers.ros.org/question/230972/what-is-a-nodelet/
代码框架:
class pcl_process_class

{
class MyPointCloudGeneratorNodelet : public nodelet::Nodelet

{

  // Subscriptions

  boost::shared_ptr<image_transport::ImageTransport> it_;

  image_transport::CameraSubscriber sub_depth_;

  int queue_size_;

  // Publications

  boost::mutex connect_mutex_;

  typedef sensor_msgs::PointCloud2 PointCloud;

  ros::Publisher pub_point_cloud_;

  image_geometry::PinholeCameraModel model_;

  virtual void onInit();

  void connectCb();

  void depthCb(const sensor_msgs::ImageConstPtr& depth_msg,

               const sensor_msgs::CameraInfoConstPtr& info_msg);

};

void MyPointCloudGeneratorNodelet::onInit()

{

  ros::NodeHandle& nh         = getNodeHandle();

  it_.reset(new image_transport::ImageTransport(nh));

  queue_size_ = ;

  // Read parameters

  // Monitor whether anyone is subscribed to the output

  ros::SubscriberStatusCallback connect_cb = boost::bind(&MyPointCloudGeneratorNodelet::connectCb, this);

  // Make sure we don't enter connectCb() between advertising and assigning to pub_point_cloud_

  boost::lock_guard<boost::mutex> lock(connect_mutex_);

  pub_point_cloud_ = nh.advertise<PointCloud>("points", , connect_cb, connect_cb);

  ROS_INFO("onInit");

}

// Handles (un)subscribing when clients (un)subscribe

void MyPointCloudGeneratorNodelet::connectCb()

{

  boost::lock_guard<boost::mutex> lock(connect_mutex_);

  if (pub_point_cloud_.getNumSubscribers() == )

  {

    sub_depth_.shutdown();

  }

  else if (!sub_depth_)

  {

    image_transport::TransportHints hints("raw", ros::TransportHints(), getPrivateNodeHandle());

    sub_depth_ = it_->subscribeCamera("image_rect", queue_size_, &MyPointCloudGeneratorNodelet::depthCb, this, hints);

  }

  ROS_INFO("connectCb");

}

void MyPointCloudGeneratorNodelet::depthCb(const sensor_msgs::ImageConstPtr& depth_msg,

                                   const sensor_msgs::CameraInfoConstPtr& info_msg)

{

      pcl_process_class mpcl_process_class;

      mpcl_process_class.pcl_process(depth_msg);

      PointCloud pointCloud;

      pcl::toROSMsg(*mpcl_p ointCloud);

}

} // namespace depth_image_proc

// Register as nodelet

#include <pluginlib/class_list_macros.h>

PLUGINLIB_EXPORT_CLASS(vision_obstacles_avoidance::MyPointCloudGeneratorNodelet,nodelet::Nodelet);
nodelet.launch
<launch>

  <node pkg="nodelet" type="nodelet" name="standalone_nodelet"  args="manager" output="screen"/>

  <node pkg="nodelet" type="nodelet" name="MyPointCloudGeneratorNodelet" args="load vision_obstacles_avoidance/MyPointCloudGeneratorNodelet standalone_nodelet" output="screen">

   <remap from="image_rect" to="/camera/depth_registered/hw_registered/image_rect_raw"/>

   <remap from="points" to="/point_cloud"/>

   <remap from="/camera/depth_registered/hw_registered/camera_info" to="/camera/depth_registered/camera_info"/>

  </node>

</launch>
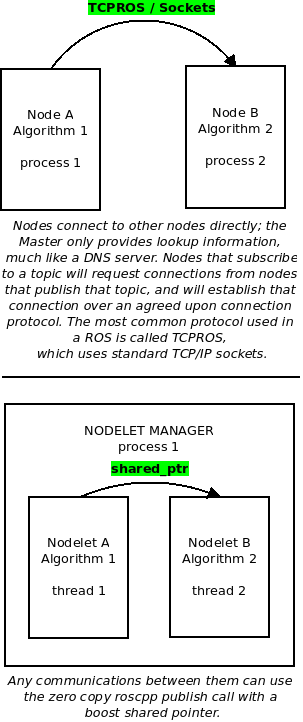
nodelet比较好用尤其是在使用pointcloud时候,由于ros node之间采用tcpros标准来传输数据,点云要经过压缩解压缩过程所以很慢,但是nodelet是直接使用原来数据,类似指针,但是只能在同一个机器下才有用。
class MyPointCloudGeneratorNodelet : public nodelet::Nodelet{ // Subscriptions boost::shared_ptr<image_transport::ImageTransport> it_; image_transport::CameraSubscriber sub_depth_; int queue_size_;
// Publications boost::mutex connect_mutex_; typedef sensor_msgs::PointCloud2 PointCloud; ros::Publisher pub_point_cloud_;
image_geometry::PinholeCameraModel model_;
virtual void onInit();
void connectCb();
void depthCb(const sensor_msgs::ImageConstPtr& depth_msg, const sensor_msgs::CameraInfoConstPtr& info_msg);};
void MyPointCloudGeneratorNodelet::onInit(){ ros::NodeHandle& nh = getNodeHandle(); it_.reset(new image_transport::ImageTransport(nh)); queue_size_ = 5; // Read parameters
// Monitor whether anyone is subscribed to the output ros::SubscriberStatusCallback connect_cb = boost::bind(&MyPointCloudGeneratorNodelet::connectCb, this); // Make sure we don't enter connectCb() between advertising and assigning to pub_point_cloud_ boost::lock_guard<boost::mutex> lock(connect_mutex_); pub_point_cloud_ = nh.advertise<PointCloud>("points", 1, connect_cb, connect_cb); ROS_INFO("onInit");
}
// Handles (un)subscribing when clients (un)subscribevoid MyPointCloudGeneratorNodelet::connectCb(){ boost::lock_guard<boost::mutex> lock(connect_mutex_); if (pub_point_cloud_.getNumSubscribers() == 0) { sub_depth_.shutdown(); } else if (!sub_depth_) { image_transport::TransportHints hints("raw", ros::TransportHints(), getPrivateNodeHandle()); sub_depth_ = it_->subscribeCamera("image_rect", queue_size_, &MyPointCloudGeneratorNodelet::depthCb, this, hints); } ROS_INFO("connectCb");
}
void MyPointCloudGeneratorNodelet::depthCb(const sensor_msgs::ImageConstPtr& depth_msg, const sensor_msgs::CameraInfoConstPtr& info_msg){
pcl_process_class mpcl_process_class; mpcl_process_class.pcl_process(depth_msg); PointCloud pointCloud; pcl::toROSMsg(*mpcl_p ointCloud);}
} // namespace depth_image_proc
// Register as nodelet#include <pluginlib/class_list_macros.h>PLUGINLIB_EXPORT_CLASS(vision_obstacles_avoidance::MyPointCloudGeneratorNodelet,nodelet::Nodelet);
ros nodelet 使用的更多相关文章
- ROS nodelet的使用
ROS是一种基于分布式网络通讯的操作系统,整个机器人控制系统是由一个Master主节点和若干个功能相对独立的Node子节点组成,这也是ROS系统最主要的特点就是分布式以及模块化的设计.在ROS通讯过程 ...
- ROS nodelet 理解记录
发现网上许多的例子都是基于官网的例子,还需要做进一步的说明. 1. NODELET_DEBUG 是无法打印的信息的,需要使用NODELET_INFO NODELET_DEBUG("Addin ...
- 使用yocs_cmd_vel_mux进行机器人速度控制切换
cmd_vel_mux包从名字就可以推测出它的用途,即进行速度的选择(In electronics, a multiplexer or mux is a device that selects one ...
- ubuntu14.04 and ros indigo install kinect driver--16
摘要: 原创博客:转载请表明出处:http://www.cnblogs.com/zxouxuewei/ 今日多次测设ros indigo install kinect driver ,提示各种失败,然 ...
- ROS Node/Topic/Message/Service的一些问题
1.Node http://blog.exbot.net/archives/1412 (摘自老王说ros) node干的什么活?callback queue里的活.这个callback queue里的 ...
- ZED 相机 && ORB-SLAM2安装环境配置与ROS下的调试
注:1. 对某些地方进行了更新(红色标注),以方便进行配置. 2. ZED ROS Wrapper官方github已经更新,根据描述新的Wrapper可能已经不适用与Ros Indigo了,如果大家想 ...
- (一)ROS系统入门 Getting Started with ROS 以Kinetic为主更新 附课件PPT
ROS机器人程序设计(原书第2版)补充资料 教案1 ROS Kinetic系统入门 ROS Kinetic在Ubuntu 16.04.01 安装可参考:http://blog.csdn.net/zha ...
- 奥比中光Orbbec Astra Pro RGBD 3D视觉传感器在ROS(indigo和kinetic)使用说明 rgb depth同时显示
Orbbec Astra Pro传感器在ROS(indigo和kinetic)使用说明 rgb depth同时显示 这款摄像头使用uvc输入彩色信息,需要libuvc和libuvc_ros这样才能在R ...
- ROS机器人程序设计(原书第2版)补充资料 (贰) 第二章 ROS系统架构及概念
ROS机器人程序设计(原书第2版)补充资料 (贰) 第二章 ROS系统架构及概念 书中,大部分出现hydro的地方,直接替换为indigo或jade或kinetic,即可在对应版本中使用. 由于工作事 ...
随机推荐
- scala(三)
一.面向对象编程——类 1.定义一个简单的类 class HelloWorld { private var name = "leo" def sayHello() { print( ...
- 【Nowcoder】玩游戏
Portal --> Nowcoder197D Solution 所以说这是一道==纯粹的人类智慧题是这样吗qwq 一开始的时候想sg函数qwq然后发现..好像根本不能拆成独立的子游戏嘛qw ...
- 学习 opencv---(13)opencv霍夫变换:霍夫线变换,霍夫圆变换
在本篇文章中,我们将一起学习opencv中霍夫变换相关的知识点,以及了解opencv中实现霍夫变换的HoughLines,HoughLinesP函数的使用方法,实现霍夫圆变换的HoughCircles ...
- ASP.NET 使用ajaxupload.js插件出现上传较大文件失败的解决方法
在网上下载了一个ajaxupload.js插件,用于无刷新上传图片使的,然后就按照demo的例子去运行了一下,上传啊什么的都OK,但是正好上传的示例图片有一个比较大的,4M,5M的样子,然后上传就会报 ...
- OpenCV---人脸检测
一:相关依赖文件下载 https://github.com/opencv/opencv 二:实现步骤(图片检测) (一)读取图片 image= cv.imread("./d.png&qu ...
- 解决SpringMVC put,patch,delete请求数据拿不到的问题
解决SpringMVC put,patch,delete请求参数拿不到的问题 废话不多说,核心代码如下: 在web.xml中添加如下代码 <!-- 解决web端不能put,delete等请求的问 ...
- JS数组---转及补充--
javascript之数组操作 1.数组的创建 var arr=Array();//写的角标数及直接写角标对应的内容简写 var arr=Array("我","爱&quo ...
- 图:centrality
[定义]Centrality:图中每个节点v的相对重要度c(v),重要度是什么可根据具体应用定义. [估计方法] Degree centrality Betweenness centrality Cl ...
- @PathParam 和 @QueryParam
今天调试一个上传功能,客户端手持机发送数据,在URL中附加一个参数,后台用@PathParam接收,但是报错,无法获取这个参数. url:http://192.168.1.3/web1_service ...
- 分析nginx日志脚本之python
为了对每个月的切割过的30个日志文件统计出访问最多的ip地址进行排序,整理了下面的脚本,主要思路是处理每一个日志文件的ip排序,最后进行字典合并,计算出月ip排序. #!/usr/bin/env py ...