
卡尔曼滤波— Constant Velocity Model
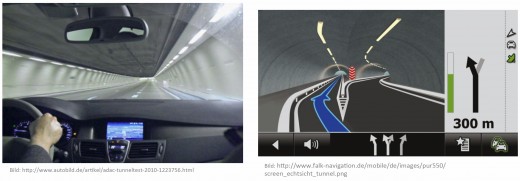
假设你开车进入隧道,GPS信号丢失,现在我们要确定汽车在隧道内的位置。汽车的绝对速度可以通过车轮转速计算得到,汽车朝向可以通过yaw rate sensor(A yaw-rate sensor is a gyroscopic device that measures a vehicle’s angular velocity around its vertical axis. )得到,因此可以获得X轴和Y轴速度分量Vx,Vy
首先确定状态变量,恒速度模型中取状态变量为汽车位置和速度:
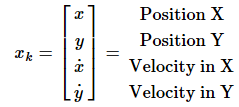
根据运动学定律(The basic idea of any motion models is that a mass cannot move arbitrarily due to inertia):
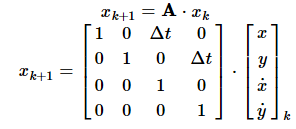
由于GPS信号丢失,不能直接测量汽车位置,则观测模型为:
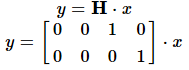
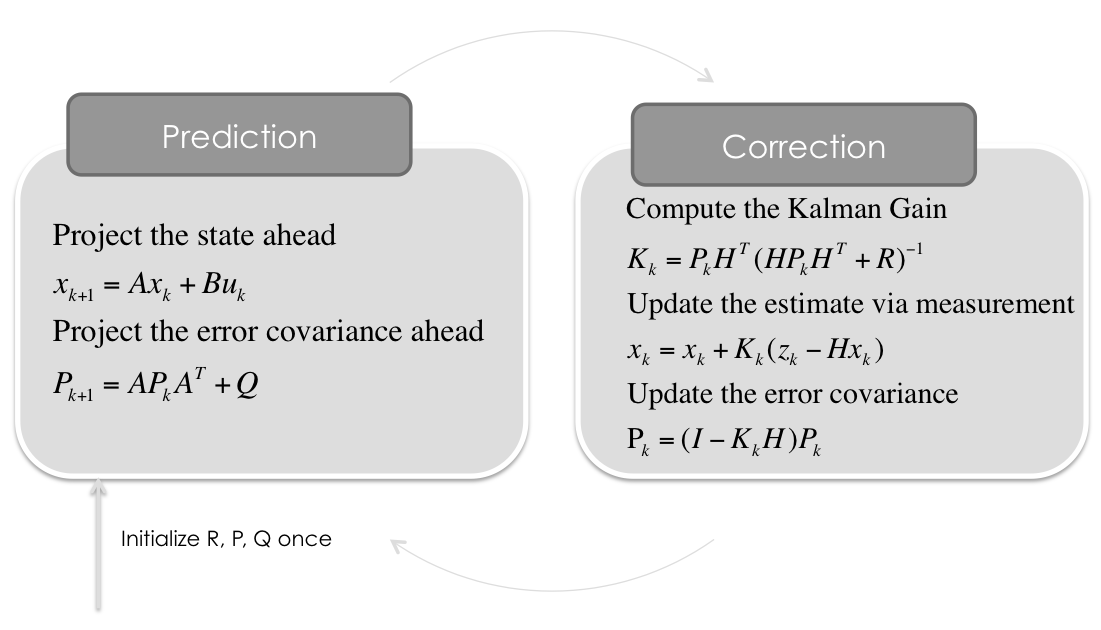
卡尔曼滤波步骤如下图所示:
 # -*- coding: utf-8 -*-

 import numpy as np

 import matplotlib.pyplot as plt

 # Initial State x0

 x = np.matrix([[0.0, 0.0, 0.0, 0.0]]).T

 # Initial Uncertainty P0

 P = np.diag([1000.0, 1000.0, 1000.0, 1000.0])

 dt = 0.1 # Time Step between Filter Steps

 # Dynamic Matrix A

 A = np.matrix([[1.0, 0.0, dt, 0.0],

               [0.0, 1.0, 0.0, dt],

               [0.0, 0.0, 1.0, 0.0],

               [0.0, 0.0, 0.0, 1.0]])

 # Measurement Matrix

 # We directly measure the velocity vx and vy

 H = np.matrix([[0.0, 0.0, 1.0, 0.0],

               [0.0, 0.0, 0.0, 1.0]])

 # Measurement Noise Covariance

 ra = 10.0**2

 R = np.matrix([[ra, 0.0],

               [0.0, ra]])

 # Process Noise Covariance

 # The Position of the car can be influenced by a force (e.g. wind), which leads

 # to an acceleration disturbance (noise). This process noise has to be modeled

 # with the process noise covariance matrix Q.

 sv = 8.8

 G = np.matrix([[0.5*dt**2],

                [0.5*dt**2],

                [dt],

                [dt]])

 Q = G*G.T*sv**2

 I = np.eye(4)

 # Measurement

 m = 200 # 200个测量点

 vx= 20  # in X

 vy= 10  # in Y

 mx = np.array(vx+np.random.randn(m))

 my = np.array(vy+np.random.randn(m))

 measurements = np.vstack((mx,my))

 # Preallocation for Plotting

 xt = []

 yt = []

 # Kalman Filter

 for n in range(len(measurements[0])):

     # Time Update (Prediction)

     # ========================

     # Project the state ahead

     x = A*x

     # Project the error covariance ahead

     P = A*P*A.T + Q

     # Measurement Update (Correction)

     # ===============================

     # Compute the Kalman Gain

     S = H*P*H.T + R

     K = (P*H.T) * np.linalg.pinv(S)

     # Update the estimate via z

     Z = measurements[:,n].reshape(2,1)

     y = Z - (H*x)                            # Innovation or Residual

     x = x + (K*y)

     # Update the error covariance

     P = (I - (K*H))*P

     # Save states for Plotting

     xt.append(float(x[0]))

     yt.append(float(x[1]))

 # State Estimate: Position (x,y)

 fig = plt.figure(figsize=(16,16))

 plt.scatter(xt,yt, s=20, label='State', c='k')

 plt.scatter(xt[0],yt[0], s=100, label='Start', c='g')

 plt.scatter(xt[-1],yt[-1], s=100, label='Goal', c='r')

 plt.xlabel('X')

 plt.ylabel('Y')

 plt.title('Position')

 plt.legend(loc='best')

 plt.axis('equal')

 plt.show()
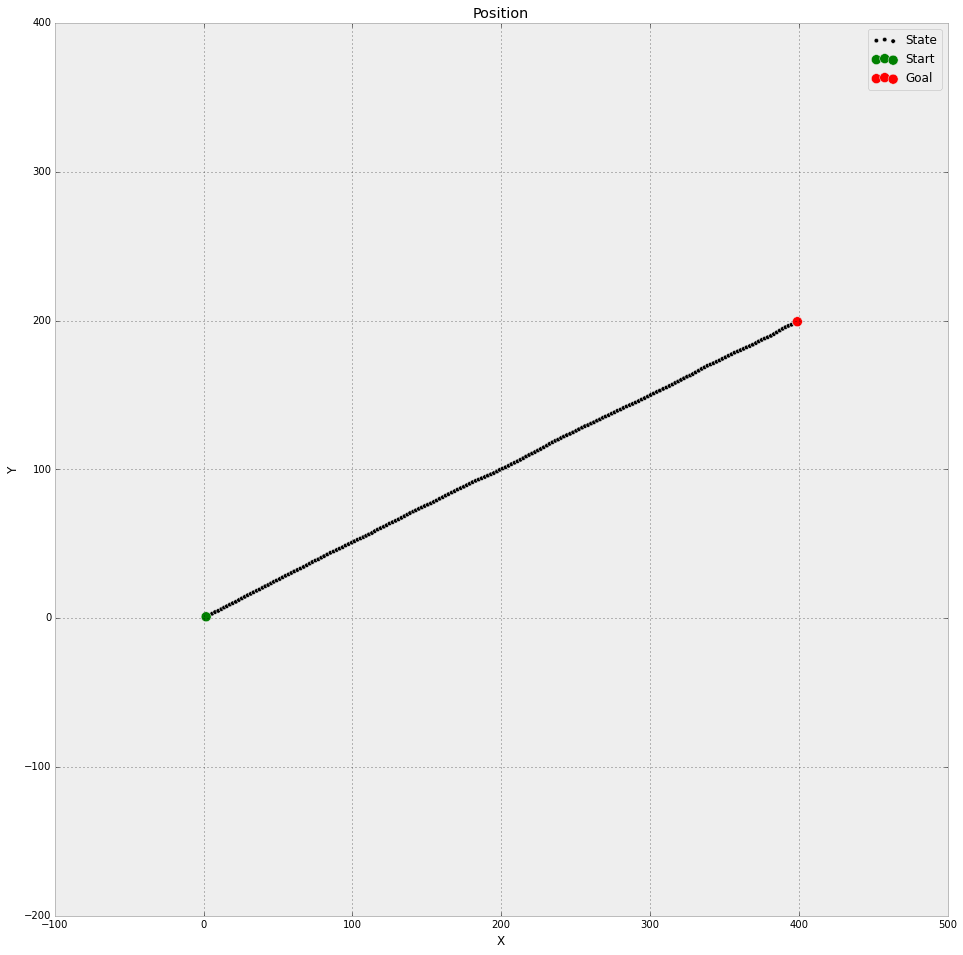
汽车在隧道中的估计位置如下图:
参考
Improving IMU attitude estimates with velocity data
https://zhuanlan.zhihu.com/p/25598462
卡尔曼滤波— Constant Velocity Model的更多相关文章
- 卡尔曼滤波—Simple Kalman Filter for 2D tracking with OpenCV
之前有关卡尔曼滤波的例子都比较简单,只能用于简单的理解卡尔曼滤波的基本步骤.现在让我们来看看卡尔曼滤波在实际中到底能做些什么吧.这里有一个使用卡尔曼滤波在窗口内跟踪鼠标移动的例子,原作者主页:http ...
- (转) Deep Reinforcement Learning: Pong from Pixels
Andrej Karpathy blog About Hacker's guide to Neural Networks Deep Reinforcement Learning: Pong from ...
- Mini-project # 4 - "Pong"___An Introduction to Interactive Programming in Python"RICE"
Mini-project #4 - "Pong" In this project, we will build a version of Pong, one of the firs ...
- RootMotionComputer 根运动计算机
using UnityEngine; using System.Collections; /* * -------------------------------------------------- ...
- Framework for Graphics Animation and Compositing Operations
FIELD OF THE DISCLOSURE The subject matter of the present disclosure relates to a framework for hand ...
- Tracking without bells and whistles
Tracking without bells and whistles 2019-08-07 20:46:12 Paper: https://arxiv.org/pdf/1903.05625 Code ...
- [Elementary Mechanics Using Python-02]Feather in tornado
Problem 9.17 Feather in tornado. In this project you will learn to use Newton's laws and the force m ...
- [UE4]自定义MovementComponent组件
自定义Movement组件 目的:实现自定义轨迹如抛物线,线性,定点等运动方式,作为组件控制绑定对象的运动. 基类:UMovementComponent 过程: 1.创建UCustomMovement ...
- UIScrollview使用
改变内容偏移 - (void)setContentOffset:(CGPoint)contentOffset animated:(BOOL)animated; // animate at const ...
随机推荐
- sp_addlinkedserver 方法应用
EXEC sp_addlinkedserver @server='DBVIP',--被访问的服务器别名 @srvproduct='', @provider='SQLO ...
- sql多表查询(out join,inner join, left join, right join)
left join以左表为基准显示所有左表的信息,在on中有符合条件的其他表也显示出来 right join则相反 inner join的只显示on中符合条件的 1 使用多个表格 在「world」资料 ...
- linux设备驱动归纳总结(八):3.设备管理的分层与面向对象思想【转】
本文转载自:http://blog.chinaunix.net/uid-25014876-id-110738.html linux设备驱动归纳总结(八):3.设备管理的分层与面向对象思想 xxxxxx ...
- javaWeb request乱码处理
//解决get方式提交的乱码 String name = request.getParameter("name"); name=new String(u ...
- jQuery 文档操作方法(w3school)
这些方法对于 XML 文档和 HTML 文档均是适用的,除了:html(). 方法 描述 addClass() 向匹配的元素添加指定的类名. after() 在匹配的元素之后插入内容. append( ...
- NIOS II CPU复位异常的原因及解决方案
NIOS II CPU复位异常的原因及解决方案 近期在用nios ii做项目时,发现一个奇怪的现象,在NIOS II EDS软件中编写好的代码,烧写到芯片中,第一次能够正常运行,但是当我按下板卡上 ...
- apache php 开启伪静态
打开apache的配置文件httpd.conf 找到 #LoadModule rewrite_module modules/mod_rewrite.so 把前面#去掉.没有则添加,但必选独占一行,使a ...
- Linux下怎么运行java程序
在Linux下安装好jdk配置好环境变量后,要回到程序所在的目录下,然后跟在windows一样输入 java (程序名)运行,原理是就好像在Windows的DOS环境下执行java这个命令时必须在 ...
- YTU 3008: 链串的基本运算
3008: 链串的基本运算 时间限制: 1 Sec 内存限制: 128 MB 提交: 1 解决: 1 题目描述 编写一个程序,实现链串的各种基本运算,主函数已给出,请补充每一种方法. 1.建立串s ...
- 【20160924】GOCVHelper MFC增强算法(5)
CString ExportListToExcel(CString sExcelFile,CListCtrl* pList, CString strTitle) { CStr ...