
How to publish a pointcloud of ros msgs in a topic from a pcd file?
How to publish a pointcloud of ros msgs in a topic from a pcd file?
Two methods
1. modified source
2. pcd_to_pointcloud
- run ros node pcl_ros in a terminal
usage:
$ rosrun pcl_ros pcd_to_pointcloud <file.pcd> [ <interval> ]
Loads a PCD file, publishing it one or more times as a ROS point cloud message.
Published Topics
- cloud_pcd (sensor_msgs/PointCloud2)
// A stream of point clouds generated from the PCD file.
// <interval> is the (optional) number of seconds to sleep between messages.

// If <interval> is zero or not specified the message is published once.
- in my condition, I use
// can add _frame_id:=/camera_link

$ rosrun pcl_ros pcd_to_pointcloud /home/william/Documents/demos/cylinders/preprocessing/data/realSense02.pcd 10 _frame_id:=/map
- run rviz:
$ rosrun rviz rviz
If the frame id you add is not camera_link, then should be edit.
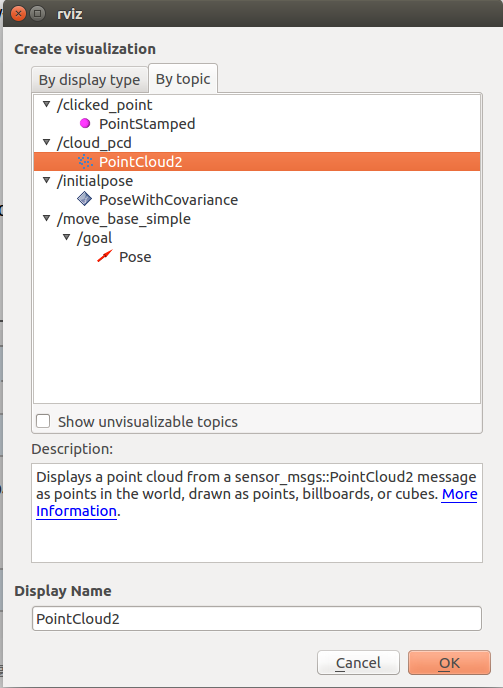
click 'Add', click 'By topic', choose 'Pointcloud2' below topic '/cloud_pcd'. Then the pointcloud can be visualized.
References:
How to publish a pointcloud of ros msgs in a topic from a pcd file?的更多相关文章
- ROS(一)Topic 通信
ROS系统起源于2007年斯坦福大学人工智能实验室的项目与机器人技术公司Willow Garage的个人机器人项目(Personal Robots Program)之间的合作,2008年之后就由Wil ...
- ros 使用命令测试topic
发布话题 $ rostopic pub -r /chatter std_msgs/String "test" 输出数据: $ rostopic echo /chatter data ...
- python smbus IOError: [Errno 2] No such file or directory
1.打开配置文件 sudo nano /boot/config.txt 打开以下选项 "dtparam=i2c_arm=on" ctrl + o 保存 ctrl + x 退出 2. ...
- 如何在ROS中使用PCL(2)
记录关于我们运行roslaunch openni_launch openni.launch 命令时生成的话题以及这些话题的数据类型便于后期的处理,只有知道它们的数据结构,才能很好的对数据进行处理,我 ...
- ROS教程
Learning ROS 学习ROS Depending on your learning style and preferences, you can take two approaches to ...
- ROS语音交互(四)接入图灵语义理解
首先程序中会用到Json,curl 安装相应的库 $ sudo apt-get install libcurl3 libcurl4-openssl-dev$ sudo apt-get install ...
- ROS多个master消息互通
需求 有时候我们需要有几个不同的master, 他们之间要交换topic的内容,这时候就不能使用ros自带的设置同一个master的方法. 我们的处理方法是,构造一个client和一个server,他 ...
- 理解ROS话题
首先需要打开一个终端在里面运行roscore: roscore 再打开一个终端,在里面运行一个turtlesim_node节点: rosrun turtlesim turtlesim_node 打开另 ...
- (二)ROS系统架构及概念 ROS Architecture and Concepts 以Kinetic为主更新 附课件PPT
第2章 ROS系统架构及概念 ROS Architecture and Concepts PPT说明: 正文用白色,命令或代码用黄色,右下角为对应中文译著页码. 这一章需要掌握ROS文件系统,运行图级 ...
随机推荐
- 解决windows下tomcat端口被占用[Address already in use: JVM_Bind]
有时候电脑比较卡,项目比较大的情况下,eclipse没有完全停止tomcat的情况下,下次启动会出现tomcat的端口被占用无法启动的情况,主要报如下错误 解决方案 window下打开命令窗口(快捷键 ...
- POJ2456(最大化最小值)
Aggressive cows Time Limit: 1000MS Memory Limit: 65536K Total Submissions: 10728 Accepted: 5288 ...
- AngularJS:HTML DOM
ylbtech-AngularJS:HTML DOM 1.返回顶部 1. AngularJS HTML DOM AngularJS 为 HTML DOM 元素的属性提供了绑定应用数据的指令. ng-d ...
- 杂项:Grunt
ylbtech-杂项:Grunt GRUNTJavaScript 世界的构建工具 1. 返回顶部 1. 为何要用构建工具? 一句话:自动化.对于需要反复重复的任务,例如压缩(minification) ...
- iOS中的数据存储
SQLite3 SQLite3是一款开源的嵌入式关系型数据库,可移植性好,易使用,内存开销小. SQLite3是无类型的,意味着你可以保存任何类型的数据到任意表的任意字段中. SQLite3常用的4种 ...
- 2015.5.9 C#编写DLL及C#调用C#DLL
过程比C#调用VC++dll简单. 一.创建DLL 新建工程,类型选择类库,生成的结果就是dll 注意:在项目属性-应用程序中,注意三个地方,程序集名称和默认命名空间可以调整,但要一致,别的程序调用此 ...
- LNMP 1.1 php编译安装
LNMP 是 Linux nginx mysql php nginx和apache一样也是一种web服务.在静态web服务中nginx更胜一筹.在动态中不比apache有优势. LNMP的mysql ...
- LAMP 3.2 mysql登陆
mysql 服务启动时,不仅会监听 IP:Port,还会监听一个 socket,我们安装的 mysql 是监听在/tmp/mysql.sock.如果 php 是在本地,那么 php 和 mysql 通 ...
- DevTools in Spring Boot 1.3
Spring Boot 1.3 will ship with a brand new module called spring-boot-devtools. The aim of this modul ...
- 【259】ucpole.dat update
2017年2月21日 57871 +0.020896 0.007232 +0.414732 0.009212 +0.418044 0.007533 p 57872 +0.022055 0.007284 ...