
POJ 1376 Robot
| Time Limit: 1000MS | Memory Limit: 10000K | |
| Total Submissions: 7866 | Accepted: 2586 |
Description
The GO command has one integer parameter n in {1,2,3}. After receiving this command the robot moves n meters in the direction it faces.
The TURN command has one parameter which is either left or right. After receiving this command the robot changes its orientation by 90o in the direction indicated by the parameter.
The execution of each command lasts one second.
Help researchers of RMI to write a program which will determine the minimal time in which the robot can move from a given starting point to a given destination.
Input
Output
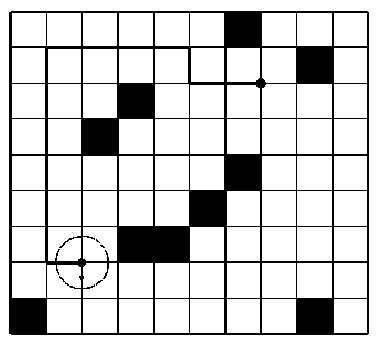
Sample Input
9 10

0 0 0 0 0 0 1 0 0 0

0 0 0 0 0 0 0 0 1 0

0 0 0 1 0 0 0 0 0 0

0 0 1 0 0 0 0 0 0 0

0 0 0 0 0 0 1 0 0 0

0 0 0 0 0 1 0 0 0 0

0 0 0 1 1 0 0 0 0 0

0 0 0 0 0 0 0 0 0 0

1 0 0 0 0 0 0 0 1 0

7 2 2 7 south

0 0
Sample Output
12

这题改了好几天。。。。。
错误的点:
1.在DEBUG的时候我尝试恢复路径,此时发现有的结点的pre信息被后来修改,是因为应当在入队的时候标记,而不是出队的时候
2.对于位置的移动判断写错,首先边界不能触碰,而且一个黑色方格周围的点也不能。
3.在枚举一个点沿着一个方向行走的可行距离的时候,当遇到黑色方块或者边界的时候要break

代码:
#include<iostream>

#include<cstdio>

#include<cmath>

#include<cstring>

#include<sstream>

#include<algorithm>

#include<queue>

#include<deque>

#include<iomanip>

#include<vector>

#include<cmath>

#include<map>

#include<stack>

#include<set>

#include<fstream>

#include<memory>

#include<list>

#include<string>

using namespace std;

typedef long long LL;

typedef unsigned long long ULL;

#define MAXN 109

#define N 33

#define MOD 1000000

#define INF 1000000009

const double eps = 1e-;

const double PI = acos(-1.0);

int X[] = { -,,, }, Y[] = { ,,,- };

bool been[MAXN][MAXN][];//四个方向

int n, m, rx, ry, g[MAXN][MAXN];

struct node

{

    int x, y, dir, time;

    node() = default;

    node(int _x, int _y, int _dir, int _t) :x(_x), y(_y), dir(_dir), time(_t) {}

};

node pre[MAXN][MAXN][];

int d[MAXN][MAXN];

void print(node u)

{

    vector<node> v;

    for (;;)

    {

        //cout << u.x <<' '<< u.y << ' '<< u.dir << endl;

        v.push_back(u);

        if (u.time == ) break;

        u = pre[u.x][u.y][u.dir];

    }

    int cnt = ;

    for (int i = v.size() - ; i >= ; i--)

    {

        printf("%d %d %d %d\n", v[i].x, v[i].y, v[i].dir, v[i].time);

    }

}

bool CanGo(int x, int y)

{

    if (x< || x >= n || y< || y >= m)

        return false;

    if (g[x][y] || g[x + ][y] || g[x][y + ] || g[x + ][y + ])

        return false;

    return true;

}

int BFS(int x, int y, int d)

{

    been[x][y][d] = true;

    queue<node> q;

    q.push(node(x, y, d, ));

    while (!q.empty())

    {

        node t = q.front();

        q.pop();

        //cout << t.x << ' ' << t.y << ' ' << t.dir <<' ' << t.time << endl;

        if (t.x == rx&&t.y == ry)

        {

            //cout << t.prex << ' ' << t.prey << "::::" << t.dir << endl;

            //print(t);

            return t.time;

        }

        if (!been[t.x][t.y][(t.dir + ) % ])

        {

            been[t.x][t.y][(t.dir + ) % ] = true;

            pre[t.x][t.y][(t.dir + ) % ] = t;

            q.push(node(t.x, t.y, (t.dir + ) % , t.time + ));

        }

        if (!been[t.x][t.y][(t.dir -  + ) % ])

        {

            been[t.x][t.y][(t.dir -  + ) % ] = true;

            pre[t.x][t.y][(t.dir -  + ) % ] = t;

            q.push(node(t.x, t.y, (t.dir -  + ) % , t.time + ));

        }

        for (int i = ; i <= ; i++)

        {

            int tx = t.x + X[t.dir] * i, ty = t.y + Y[t.dir] * i;

            if (CanGo(tx, ty))

            {

                if(!been[tx][ty][t.dir])

                {

                    been[tx][ty][t.dir] = true;

                    pre[tx][ty][t.dir] = t;

                    q.push(node(tx, ty, t.dir, t.time + ));

                }

            }

            else

                break;

        }

    }

    return -;

}

int main()

{

    while (scanf("%d%d", &n, &m), n + m)

    {

        memset(been, false, sizeof(been));

        int tx, ty, d;

        char op[];

        for (int i = ; i <= n; i++)

            for (int j = ; j <= m; j++)

                scanf("%d", &g[i][j]);

        scanf("%d%d%d%d%s", &tx, &ty, &rx, &ry, op);

        if (!CanGo(rx, ry))

        {

            printf("-1\n");

            continue;

        }

        if (op[] == 'n')

            d = ;

        else if (op[] == 'e')

            d = ;

        else if (op[] == 's')

            d = ;

        else

            d = ;

        printf("%d\n", BFS(tx, ty, d));

    }

}
POJ 1376 Robot的更多相关文章
- 模拟 POJ 1573 Robot Motion
题目地址:http://poj.org/problem?id=1573 /* 题意:给定地图和起始位置,robot(上下左右)一步一步去走,问走出地图的步数 如果是死循环,输出走进死循环之前的步数和死 ...
- Robot POJ - 1376
The Robot Moving Institute is using a robot in their local store to transport different items. Of co ...
- POJ 1573 Robot Motion(BFS)
Robot Motion Time Limit: 1000MS Memory Limit: 10000K Total Submissions: 12856 Accepted: 6240 Des ...
- POJ 1573 Robot Motion(模拟)
题目代号:POJ 1573 题目链接:http://poj.org/problem?id=1573 Language: Default Robot Motion Time Limit: 1000MS ...
- POJ 1573 Robot Motion
Robot Motion Time Limit: 1000MS Memory Limit: 10000K Total Submissions: 12978 Accepted: 6290 Des ...
- poj 1573 Robot Motion【模拟题 写个while循环一直到机器人跳出来】
...
- POJ 1573 Robot Motion 模拟 难度:0
#define ONLINE_JUDGE #include<cstdio> #include <cstring> #include <algorithm> usin ...
- poj 1573 Robot Motion_模拟
又是被自己的方向搞混了 题意:走出去和遇到之前走过的就输出. #include <cstdlib> #include <iostream> #include<cstdio ...
- poj 1367 robot(搜索)
题意:给你一个图,求起点 到 终点的最少时间 每次有两种选择①:往前走1~3步 ②原地选择90° 费时皆是1s 图中1为障碍物,而且不能出边界.还要考虑机器人的直径 ...
随机推荐
- E20171014-hm
Sibling n. 兄弟,姐妹; [生] 同科,同属; [人] 氏族成员;
- Akka源码分析-Event Bus
akka中的EventBus其实是不常用,也最容易被忽略的一个组件. 但如果你深入Cluster的实现就会发现,这个东西其实还挺有用的,而且它是ActorSystem系统中所有事件消息的一个横切面,通 ...
- hbuilder中的 http://www.w3.org/TR/html4/strict.dtd
<!-- This is HTML 4.01 Strict DTD, which excludes the presentation attributes and elements that W ...
- webHttpBinding+wsHttpBinding+basicHttpBinding的区别 (转)
1. webHttpBinding (web AJAX/JSON)2. wsHttpBinding (ASP.NET client) 3. basicHttpBinding (Silverlight) ...
- Java系列学习(十三)-字符串
1.字符串基础 概念:字符串本质是打包字符数组的对象,是java.lang.String类的实例 2.字符串的构造方法 public String() public String(byte[] byt ...
- swift单例创建的几种方法
//单例方法1 class SingleTonOne{ static var sharedInstanceOne:SingleTonOne{ struct SingleTonStruct { stat ...
- asp.net——登录界面
题目: 在页面中放入两个TextBox分别用于输入用户名和密码,一个显示文字用的Label,一个提交按钮Button.点击按钮提交用户名和密码,如果用户名都密码正确(比如用户名admin 密码abc1 ...
- DeadObjectException
开发的过程中有时候会遇到DeadObjectException,说明系统service已经停止运行,解决的方式是在mainfistxml的application标签中添加android:hardwar ...
- ScrollView在调试状态一点击就挂的原因(OnMouseActivate)
这几天做的一个任务是做一个Dialog,需要在这个Dialog中添加一个自定义的CSrollvew类,但是遇到一个比较扯淡的问题,程序直接运行时可以的,调试状态下一点击CSrollview就挂了.而且 ...
- JavaScript定时器及其他
By Abyssly Jun 20 2014 Updated:Jun 20 2014 平时工作中不可避免地要嵌套网页,对JavaScript的深入了解还是很有必要滴.而JavaScript中一个容易让 ...