
软件篇-04-OMPL和FCL用于SLAM轨迹规划
使用OMPL内置的infoRRTstar算法模块和FCL碰撞检测库实现当前点和目标点的轨迹规划,
- 效果图
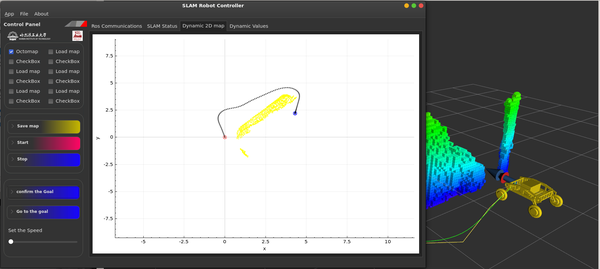
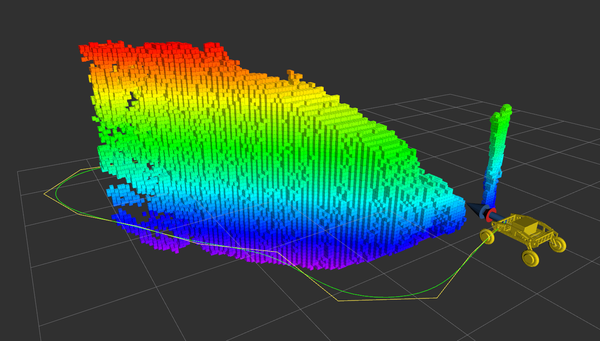
- 将pointcloud点云转化为OctoMap,用于碰撞检测
// turn the pcl cloud to fcl::CollisionGeometry after octree

// updtae the octomap

octomap::OcTree* treeOctomapPtr = new octomap::OcTree( 0.05 );

for(auto p:pclCloud->points) {
  if(p.z > groundHeightMax + carTF_zed2.pose.position.z) treeOctomapPtr->updateNode
  ( octomap::point3d(p.x, p.y, p.z), true );
  }
  treeOctomapPtr->updateInnerOccupancy();
  fcl::OcTree<float>* tree = new fcl::OcTree<float>(std::shared_ptr<const octomap::OcTree>(treeOctomapPtr));
  tree_obj = std::shared_ptr<fcl::CollisionGeometry<float>>(tree);
- 设置OMPL轨迹规划限制空间
// set the bounds for the R^3 part of SE(3)

ompl::base::RealVectorBounds bounds(3);

// set X-Y-Z dimensions bound

bounds.setLow(0,bounds_lmin);

bounds.setHigh(0,bounds_lmax);

bounds.setLow(1,bounds_wmin);

bounds.setHigh(1,bounds_wmax);

bounds.setLow(2,bounds_hmin);

bounds.setHigh(2,bounds_hmax);
- 使用FCL检测当前状态是否碰撞
bool Navigation::isStateValid(const ompl::base::State *state)
{

// cast the abstract state type to the type we expect const ompl::base::SE3StateSpace::StateType *se3state = state->as<ompl::base::SE3StateSpace::StateType>();

// extract the first component of the state and cast it to what we expect const ompl::base::RealVectorStateSpace::StateType *pos = se3state->as<ompl::base::RealVectorStateSpace::StateType>(0); // extract the second component of the state and cast it to what we expect const ompl::base::SO3StateSpace::StateType *rot = se3state->as<ompl::base::SO3StateSpace::StateType>(1); fcl::CollisionObject<float> treeObj((tree_obj)); fcl::CollisionObject<float> slamCarObject(slamCar); // check validity of state defined by pos & rot fcl::Vector3f translation(pos->values[0],pos->values[1],pos->values[2]); fcl::Quaternionf rotation(rot->w, rot->x, rot->y, rot->z); slamCarObject.setTransform(rotation, translation); fcl::CollisionRequest<float>requestType(1,false,1,false); fcl::CollisionResult<float> collisionResult; fcl::collide(&slamCarObject,&treeObj, requestType, collisionResult);return(!collisionResult.isCollision());}

在下面的代码将FCL和OMPL相联系,这里的 "std::placeholders::_1"是一个占位符。

si = ompl::base::SpaceInformationPtr(new ompl::base::SpaceInformation(space));
si->setStateValidityChecker(std::bind(&Navigation::isStateValid, this, std::placeholders::_1 ));
- 一切设置好后就可以开始计算路径了
ompl::base::PlannerStatus solved;

try
{
  solved = plan->solve(rrtSolutionTimeLimit);
}
catch(ompl::Exception e)
{
  ROS_WARN("Error occourred: %s", e.what());
}
ompl::geometric::PathSimplifier* pathBSpline = new ompl::geometric::PathSimplifier(si);

path_smooth = new ompl::geometric::PathGeometric(dynamic_cast<const ompl::geometric::PathGeometric&>(*pdef->getSolutionPath()));
pathBSpline->smoothBSpline(*path_smooth,3);

// ROS_INFO("Smoothed Path:"); // path_smooth->print(std::cout); smooth_msg.header.stamp = ros::Time::now(); smooth_msg.header.frame_id = "map"; for (std::size_t idx = 0; idx < path_smooth->getStateCount (); idx++) { // cast the abstract state type to the type we expect const ompl::base::SE3StateSpace::StateType *se3state = path_smooth->getState(idx)->as<ompl::base::SE3StateSpace::StateType>(); // extract the first component of the state and cast it to what we expect const ompl::base::RealVectorStateSpace::StateType *pos = se3state->as<ompl::base::RealVectorStateSpace::StateType>(0); // extract the second component of the state and cast it to what we expect const ompl::base::SO3StateSpace::StateType *rot = se3state->as<ompl::base::SO3StateSpace::StateType>(1); geometry_msgs::PoseStamped point; point.pose.position.x = pos->values[0]; point.pose.position.y = pos->values[1]; point.pose.position.z = pos->values[2]; point.pose.orientation.x = rot->x; point.pose.orientation.y = rot->y; point.pose.orientation.z = rot->z; point.pose.orientation.w = rot->w; smooth_msg.poses.push_back(point);}
软件篇-04-OMPL和FCL用于SLAM轨迹规划的更多相关文章
- 软件篇-03-基于ORB_SLAM2手写SLAM稠密地图构建实现
本文使用的方法不是从内部修改ORBSLAM2源码以获取稠密点云,而是先从ZED2 sdk获取以摄像头坐标系为描述的三维点云/作为点云地图的一个子集,然后融合IMU与ORB_SLAM2进行实时定位,通过 ...
- 软件篇-05-融合ORB_SLAM2和IMU闭环控制SLAM底盘运动轨迹
前面我们已经得到了当前底盘在世界坐标系中的位姿,这个位姿是通过融合ORB_SLAM2位姿和IMU积分得到的,在当前位姿已知的case下,给SLAM小车设置一个goal,我这里是通过上位机设置,然后 ...
- GSM Sniffing入门之软件篇:GSMTAP抓取与SMS(Short Message Service)
重点介绍如何利用50元左右的设备,抓包并还原SMS短信内容: ps:研究GSM Sniffing纯属个人兴趣,能抓SMS报文只是捡了个明文传输的漏子,切勿用于非法用途.就像sylvain说的,osmo ...
- [知乎]老狼:深入PCI与PCIe之二:软件篇
深入PCI与PCIe之二:软件篇 https://zhuanlan.zhihu.com/p/26244141 我们前一篇文章(深入PCI与PCIe之一:硬件篇 - 知乎专栏)介绍了PCI和PCIe的硬 ...
- OA办公软件篇(一)—组织架构
OA办公软件篇(一)-组织架构 背景 作用 迭代历程 具体实现 写在最后 背景 在说组织架构之前,我们先来说说OA本身. 百度百科解释OA为:办公自动化(Office Automation,简称O ...
- OA办公软件篇(三)—审批流
背景 作用 迭代历程 具体实现 写在最后 背景 在前面两篇文章中,我们分别讲了组织架构和权限管理,今天我们来讲一个跟组织架构关系比较密切的功能-审批流. 审批流,通俗来说就是一个完整的审批流程,是 ...
- iOS系列 基础篇 04 探究视图生命周期
iOS系列 基础篇 04 探究视图生命周期 视图是应用的一个重要的组成部份,功能的实现与其息息相关,而视图控制器控制着视图,其重要性在整个应用中不言而喻. 以视图的四种状态为基础,我们来系统了解一下视 ...
- 智能家居-3.基于esp8266的语音控制系统(软件篇)
智能家居-1.基于esp8266的语音控制系统(开篇) 智能家居-2.基于esp8266的语音控制系统(硬件篇) 智能家居-3.基于esp8266的语音控制系统(软件篇) 赞赏支持 QQ:505645 ...
- OA办公软件篇(二)—权限管理
权限管理的背景 权限管理的作用 迭代历程 关键名词释义 权限管理模型 具体实现 写在最后 权限管理的背景 在OA办公软件篇(一)-组织架构一文中,我们说到组织架构是软件系统的权限体系的重要搭建依据 ...
随机推荐
- Redis数据结构和对象三
1.Redis 对象系统 Redis用到的所有主要数据结构,简单动态字符串(SDS).双端链表.字典.压缩列表.整数集合.跳跃表. Redis并没有直接使用这些数据结构来实现键值对数据库,而是基于这些 ...
- MySQL之四 存储引擎
1.介绍 存储引擎MySQL中的"文件系统" MySQL体系结构 InnoDB存储引擎介绍 My1SAM 和InnoDB区别 mysql MariaDB [(none)]> ...
- C++入门(3):C++开发环境搭建
本文首发 | 公众号:lunvey 既然开始学C++,电脑上应该具备它的开发环境. 而C++历史,lunvey老师觉得:初学者有兴趣可以自行了解一下,不是必要的. 大家都在用最新款的苹果手机,好用就行 ...
- 理解ASP.NET Core 中的WebSocket
在本文中,我们将详细介绍RFC 6455 WebSocket规范,并配置一个通用的.NET 5应用程序通过WebSocket连接与SignalR通信. 我们将深入底层的概念,以理解底层发生了什么. 关 ...
- Python flask-restful框架讲解
Restful 是 Flask 的扩展,增加了对快速构建 REST api 的支持.它是一个轻量级的概念,与您现有的 ORM/librarie 一起工作.Restful 鼓励最小化设置的最佳实践.如果 ...
- JVM笔记 -- JVM的发展以及基于栈的指令集架构
2011年,JDK7发布,1.7u4中,开始启用新的垃圾回收器G1(但是不是默认). 2017年,发布JDK9,G1成为默认GC,代替CMS.(一般公司使用jdk8的时候,会通过参数,指定GC为G1) ...
- ModuleNotFoundError: No module named 'django'
1 .就在前天 我还能用python3 manage.py runserver 0.0.0.0:8000 启动Django 今天就突然报错了(心情极为复杂,你这也能信?) 2.打印python找 ...
- Celery:进一步探索
一.创建Celery专用模块 对于大型项目,一般需要创建一个专用模块,便于管理. 1.1 模块结构 proj/__init__.py /celery.py /tasks.py proj/celery. ...
- WPF 实战 - 翻页控件
1. 先上效果 <StackPanel Orientation="Horizontal" HorizontalAlignment="Center"> ...
- 关于ORACLE数据库跨库调用序列的解决办法
问题 ORACLE 数据库 用户1 xscg 有序列 seq_S_ATTACHMENT_INFO.nextval 我要在 用户2 xsds 里面调用 ...