
快速切题 poj2632
| Time Limit: 1000MS | Memory Limit: 65536K | |
| Total Submissions: 7799 | Accepted: 3388 |
Description
A robot crashes with a wall if it attempts to move outside the area of the warehouse, and two robots crash with each other if they ever try to occupy the same spot.
Input
The second line contains two integers, 1 <= N, M <= 100, denoting the numbers of robots and instructions respectively.
Then follow N lines with two integers, 1 <= Xi <= A, 1 <= Yi <= B and one letter (N, S, E or W), giving the starting position and direction of each robot, in order from 1 through N. No two robots start at the same position.
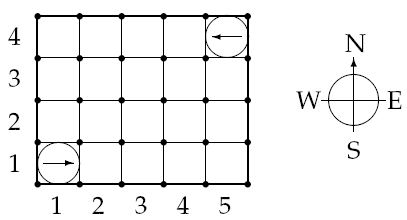
Figure 1: The starting positions of the robots in the sample warehouse
Finally there are M lines, giving the instructions in sequential order.
An instruction has the following format:
< robot #> < action> < repeat>
Where is one of
- L: turn left 90 degrees,
- R: turn right 90 degrees, or
- F: move forward one meter,
and 1 <= < repeat> <= 100 is the number of times the robot should perform this single move.
Output
- Robot i crashes into the wall, if robot i crashes into a wall. (A robot crashes into a wall if Xi = 0, Xi = A + 1, Yi = 0 or Yi = B + 1.)
- Robot i crashes into robot j, if robots i and j crash, and i is the moving robot.
- OK, if no crashing occurs.
Only the first crash is to be reported.
Sample Input
4

5 4

2 2

1 1 E

5 4 W

1 F 7

2 F 7

5 4

2 4

1 1 E

5 4 W

1 F 3

2 F 1

1 L 1

1 F 3

5 4

2 2

1 1 E

5 4 W

1 L 96

1 F 2

5 4

2 3

1 1 E

5 4 W

1 F 4

1 L 1

1 F 20
Sample Output
Robot 1 crashes into the wall

Robot 1 crashes into robot 2

OK

Robot 1 crashes into robot 2

简单的模拟
应用时:15min
实际用时:1h40min
问题:碰撞的先后次序
#include<cstdio>

#include <cstring>

#include <algorithm>

using namespace std;

int A,B,n,m;

int robot[][];

char rbuff[];

int dir[];

const int dx[]={,,,-};

const int dy[]={,,-,};

int action[][];

int tx,ty;

int ansr;

bool between(int aim,int gap){

    int sx=robot[gap][];

    int sy=robot[gap][];

    int mingx=min(sx,tx);

    int maxgx=max(sx,tx);

    int mingy=min(sy,ty);

    int maxgy=max(sy,ty);

    int ax=robot[aim][];int ay=robot[aim][];

    if(ax>=mingx&&ax<=maxgx&&ay>=mingy&&ay<=maxgy){

            if(ansr==)ansr=aim;

            else {

                if(abs(robot[ansr][]-sx)>=abs(ax-sx)&&abs(robot[ansr][]-sy)>=abs(ay-sy)){

                    ansr=aim;

                }

            }

            return true;

    }

    return false;

}

void solve(){

    ansr=;

    for(int i=;i<m;i++){

        int rob=action[i][];

        int rep=action[i][];

        if(action[i][]==){

            robot[rob][]=(robot[rob][]+-rep%)%;

        }

        else if(action[i][]==){

            robot[rob][]=(robot[rob][]+rep%)%;

        }

        else{

            bool fl=false;

            tx=robot[rob][]+rep*dx[robot[rob][]];

            ty=robot[rob][]+rep*dy[robot[rob][]];

            for(int j=;j<=n;j++){

                if(j==rob)continue;

                if(between(j,rob)){

                    fl=true;

                }

            }

           if(fl){

                printf("Robot %d crashes into robot %d\n",rob,ansr);return ;

            }

            if(tx<||tx>A||ty<||ty>B){

                printf("Robot %d crashes into the wall\n",rob);return ;

            }

            robot[rob][]=tx;

            robot[rob][]=ty;

        }

    }

    puts("OK");

}

int main(){

    #ifndef ONLINE_JUDGE

        freopen("output.txt","w",stdout);

    #endif // ONLINE_JUDGE

dir['N']=;dir['E']=;dir['S']=;dir['W']=;

dir['L']=;dir['R']=;dir['F']=;

    int t;

    scanf("%d",&t);

    while(t--){

       scanf("%d%d%d%d",&A,&B,&n,&m);

       for(int i=;i<=n;++i){

            scanf("%d%d%s",robot[i],robot[i]+,rbuff);

            robot[i][]=dir[rbuff[]];

       }

       for(int i=;i<m;i++){

             scanf("%d%s%d",action[i],rbuff,action[i]+);

             action[i][]=dir[rbuff[]];

       }

       solve();

    }

    return ;

}
快速切题 poj2632的更多相关文章
- 快速切题sgu127. Telephone directory
127. Telephone directory time limit per test: 0.25 sec. memory limit per test: 4096 KB CIA has decid ...
- 快速切题sgu126. Boxes
126. Boxes time limit per test: 0.25 sec. memory limit per test: 4096 KB There are two boxes. There ...
- 快速切题 sgu123. The sum
123. The sum time limit per test: 0.25 sec. memory limit per test: 4096 KB The Fibonacci sequence of ...
- 快速切题 sgu120. Archipelago 计算几何
120. Archipelago time limit per test: 0.25 sec. memory limit per test: 4096 KB Archipelago Ber-Islan ...
- 快速切题 sgu119. Magic Pairs
119. Magic Pairs time limit per test: 0.5 sec. memory limit per test: 4096 KB “Prove that for any in ...
- 快速切题 sgu118. Digital Root 秦九韶公式
118. Digital Root time limit per test: 0.25 sec. memory limit per test: 4096 KB Let f(n) be a sum of ...
- 快速切题 sgu117. Counting 分解质因数
117. Counting time limit per test: 0.25 sec. memory limit per test: 4096 KB Find amount of numbers f ...
- 快速切题 sgu116. Index of super-prime bfs+树思想
116. Index of super-prime time limit per test: 0.25 sec. memory limit per test: 4096 KB Let P1, P2, ...
- 快速切题 sgu115. Calendar 模拟 难度:0
115. Calendar time limit per test: 0.25 sec. memory limit per test: 4096 KB First year of new millen ...
随机推荐
- STM32系统时钟为什么没有定义呢
对于使用3.5版本库开发的STM32学习者 有时候不清楚为什么没有时钟定义 那么我们就简单的讲解下吧: 1,函数从启动文件开始运行(汇编文件) 2,若是hd.s 请看151行LDR R0, = ...
- Python3基础 try-except else进行配合
Python : 3.7.0 OS : Ubuntu 18.04.1 LTS IDE : PyCharm 2018.2.4 Conda ...
- win10中mount和unmount iso文件
https://www.windowscentral.com/how-mount-or-unmount-iso-images-windows-10 You can also right-click t ...
- CSS3 常用选择器
p:last-of-type{background-color: red;} 选择p中最后一项 p:nth-of-type(2n){background-color: red;} 隔行变色里面也可以填 ...
- 使用rz,sz需要安装lrzsz
... tar zxvf lrzsz-1.12.20.tar.gz 4.进入目录 cd lrzsz-1.12.20 5../configure --prefix=/usr/local/lrzsz 6. ...
- Cocos2d-x学习笔记(十二)3D特效
特效类即是GridAction类,其实就是基于网格的3D动作类.需开启OpenGL的深度缓冲,否则容易3D失真. 下边是一个snippet,创建网格对象,并将其添加到当前layer:同时,将进行3D特 ...
- python 元组列表合并
#create a tuple l = [(,), (,), (,)] print(list(zip(*l)))
- python排序(插入排序) 从小到大顺序
def insert_sort(ilist): for i in range(len(ilist)): for j in range(i): if ilist[i] < ilist[j]: il ...
- Redis<一> 数据结构:String
). set key value : 将字符串值 value 关联到 key .如果 key 已经持有其他值, SET 就覆写旧值,无视类型. ). get key : 返回 key 所关联的字符串值 ...
- 610D - Vika and Segments(线段树+扫描线+离散化)
扫描线:http://www.cnblogs.com/scau20110726/archive/2013/04/12/3016765.html 看图,图中的数字是横坐标离散后对应的下标,计算时左端点不 ...