
PCL点云库:Kd树
Kd树按空间划分生成叶子节点,各个叶子节点里存放点数据,其可以按半径搜索或邻区搜索。PCL中的Kd tree的基础数据结构使用了FLANN以便可以快速的进行邻区搜索。FLANN is a library for performing fast approximate nearest neighbor searches in high dimensional spaces。下面是一个最基本的例子,只寻找一个最近点:
#include <pcl/point_cloud.h>

#include <pcl/kdtree/kdtree_flann.h>

#include <iostream>

#include <vector>

#include <ctime>

int main (int argc, char** argv)

{

    srand (time (NULL));  //seeds rand() with the system time

    time_t begin,end;

    begin = clock();  //开始计时

    //-------------------------------------------------------------------------------

    pcl::PointCloud<pcl::PointXYZ>::Ptr cloud (new pcl::PointCloud<pcl::PointXYZ>);

    // Generate pointcloud data

    cloud->width = ;

    cloud->height = ;

    cloud->points.resize (cloud->width * cloud->height);

    // fills a PointCloud with random data

    for (size_t i = ; i < cloud->points.size (); ++i)

    {

        cloud->points[i].x = 1024.0f * rand () / (RAND_MAX + 1.0f);

        cloud->points[i].y = 1024.0f * rand () / (RAND_MAX + 1.0f);

        cloud->points[i].z = 1024.0f * rand () / (RAND_MAX + 1.0f);

    }

    // creates kdtree object

    pcl::KdTreeFLANN<pcl::PointXYZ> kdtree;

    // sets our randomly created cloud as the input

    kdtree.setInputCloud (cloud);

    //create a “searchPoint” which is assigned random coordinates

    pcl::PointXYZ searchPoint;

    searchPoint.x = 1024.0f * rand () / (RAND_MAX + 1.0f);

    searchPoint.y = 1024.0f * rand () / (RAND_MAX + 1.0f);

    searchPoint.z = 1024.0f * rand () / (RAND_MAX + 1.0f);

    // K nearest neighbor search

    int K = ;

    std::vector<int> pointIdxNKNSearch(K);

    std::vector<float> pointNKNSquaredDistance(K);

    std::cout << "K nearest neighbor search at (" << searchPoint.x

        << " " << searchPoint.y

        << " " << searchPoint.z

        << ") with K=" << K << std::endl;

    /***********************************************************************************************

    template<typename PointT>

    virtual int pcl::KdTree< PointT >::nearestKSearch  ( const PointT &  p_q,

                                                        int  k,

                                                        std::vector< int > &  k_indices,

                                                        std::vector< float > &  k_sqr_distances

                                                        )  const [pure virtual]

    Search for k-nearest neighbors for the given query point.

    Parameters:

        [in] the given query point

        [in] k the number of neighbors to search for

        [out] the resultant indices of the neighboring points

        [out] the resultant squared distances to the neighboring points

    Returns:

        number of neighbors found

    ********************************************************************************************/

    if ( kdtree.nearestKSearch (searchPoint, K, pointIdxNKNSearch, pointNKNSquaredDistance) >  )

    {

        for (size_t i = ; i < pointIdxNKNSearch.size (); ++i)

            std::cout << "    "  <<   cloud->points[ pointIdxNKNSearch[i] ].x

            << " " << cloud->points[ pointIdxNKNSearch[i] ].y

            << " " << cloud->points[ pointIdxNKNSearch[i] ].z

            << " (squared distance: " << pointNKNSquaredDistance[i] << ")" << std::endl;

    }

    //--------------------------------------------------------------------------------------------

    end = clock();  //结束计时

    double Times =  double(end - begin) / CLOCKS_PER_SEC; //将clock()函数的结果转化为以秒为单位的量

    std::cout<<"time: "<<Times<<"s"<<std::endl;

    return ;

}
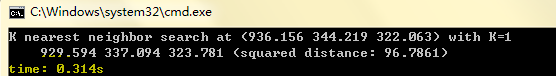
生成四十万个随机点,release版本下测试0.3s左右找到最近点,这比之前自己写的Kd树不知快到哪里去了。当然自己写只是为了更好的理解其中的原理,真要用的时候还得靠别人的轮子...
参考:
PCL点云库:Kd树的更多相关文章
- PCL点云库:ICP算法
ICP(Iterative Closest Point迭代最近点)算法是一种点集对点集配准方法.在VTK.PCL.MRPT.MeshLab等C++库或软件中都有实现,可以参见维基百科中的ICP Alg ...
- PCL点云库中的坐标系(CoordinateSystem)
博客转载自:https://blog.csdn.net/qq_33624918/article/details/80488590 引言 世上本没有坐标系,用的人多了,便定义了坐标系统用来定位.地理坐标 ...
- Windows下安装PCL点云库
原文链接:http://blog.csdn.net/u012337034/article/details/38270109 简介: 在Windows下安装PCL点云库的方法大概有两种: ...
- Windows 8 64位系统 在VS2010 32位软件上 搭建 PCL点云库 开发环境
Windows 8 64位系统 在VS2010 32位软件上 搭建 PCL点云库 开发环境 下载PCL For windows 软件包 到这个网站下载PCL-All-In-One Installer: ...
- python利用pybind11调用PCL点云库
2019年7月9日14:31:13 完成了一个简单的小例子,python生成点云数据,利用pybind11传给PCL显示. ubuntu 16.04 + Anaconda3 python3.6 + ...
- PCL点云库(Point Cloud Library)简介
博客转载自:http://www.pclcn.org/study/shownews.php?lang=cn&id=29 什么是PCL PCL(Point Cloud Library)是在吸收了 ...
- PCL点云库:对点云进行变换(Using a matrix to transform a point cloud)
点云数据可以用ASCII码的形式存储在PCD文件中(关于该格式的描述可以参考链接:The PCD (Point Cloud Data) file format).为了生成三维点云数据,在excel中用 ...
- [PCL]1 PCL点云库安装
1.安装文件下载:官网,我还是比较喜欢别人编译好的安装包啊,哈哈. http://www.pointclouds.org/downloads/windows.html 2.傻瓜式安装(下面的依赖项都集 ...
- PCL点云库增加自定义数据类型
#include <pcl/filters/passthrough.h> #include <pcl/filters/impl/passthrough.hpp> // the ...
随机推荐
- coolpro2 剪切并淡出
1.先将音乐暂停或者停止. 2.选择需要淡出的一段音乐 3.选择效果--波形振幅--渐变 4.选择Fade-out,确定
- 论url
http://www.cnblogs.com/yexiaochai/p/3650379.css文件中 background: (../images/logo.png); http://www.cnbl ...
- nodejs 80端口监听失败及NODE_PATH不起作用的问题
nodejs做web服务器,打开80时报错:Error: listen EACCES 0.0.0.0:80 80端口监听失败,是因为1024以下的端口需要root权限,需要sudo或su之后执行.但这 ...
- win7下用mklink命令解决delphiXE系列占用C盘空间的问题
DelphiXE从2010以后, 安装程序安装完成后都会在ProgramData目录里复制一份安装程序的备份, 随着版本升级安装包越来越大, 占用C盘的空间也就越来越大 虽然可以通过删除的方式删掉, ...
- Synergy 鼠标和键盘共享软件
http://symless.com/nightly Synergy 正可以让你的多台电脑共享一套键鼠,甚至还可以共享剪贴板,如同一机多屏,并跨平台支持 .
- Linked List Cycle II || LeetCode
/** * Definition for singly-linked list. * struct ListNode { * int val; * struct ListNode *next; * } ...
- Kingdom of Obsession---hdu5943(二分匹配)
题目链接:http://acm.hdu.edu.cn/showproblem.php?pid=5943 题意:给你两个数n, s 然后让你判断是否存在(s+1, s+2, s+3, ... , s+n ...
- selenium借助AutoIt识别上传(下载)详解
AutoIt目前最新是v3版本,这是一个使用类似BASIC脚本语言的免费软件,它设计用于Windows GUI(图形用户界面)中进行自动化操作.它利用模拟键盘按键,鼠标移动和窗口/控件的组合来实现自动 ...
- CentOS 配置网络yum源
配置网络yum源(需要保证外网开通,使用网易163提供开源镜像站) 1.下载repo文件 方法一:下载到本地windows再上传到linux服务器上: 下载地址 : http://mirrors.16 ...
- Unity中那些事半功倍的好插件
Unity开发最好的地方就是有各种强大的插件,有哪些插件让大家事半功倍,稳定强大 值得推荐学习和入手呢?Unity5.0之后,制作UI 以及UI的动画,UI特效,大家一般都使用什么插件?或者说有什么好 ...