
ros 编译包含脚本文件以及launch文件
目录结构如下:
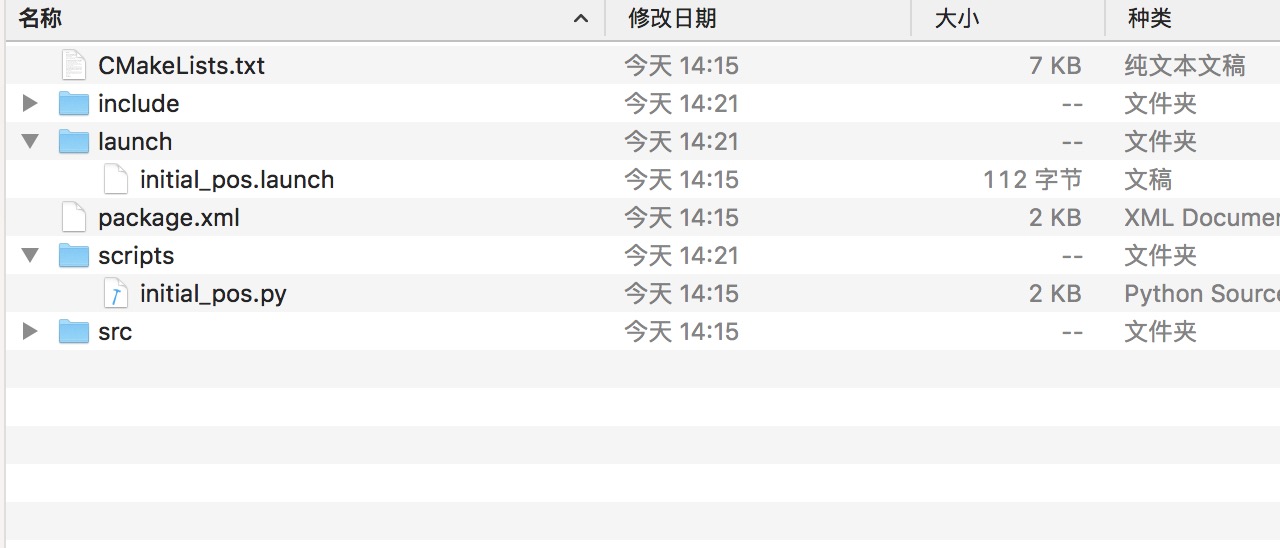
修改CMakeLists.txt文件
install(PROGRAMS

    scripts/initial_pos.py

    DESTINATION ${CATKIN_PACKAGE_BIN_DESTINATION})

install(DIRECTORY launch/

    DESTINATION ${CATKIN_PACKAGE_SHARE_DESTINATION}/launch)
initial_pos.launch文件内容:
<launch>

<node pkg="bp_initialpos" name="initial_pos" type="initial_pos.py" output="screen">

</node>

</launch>
initial_pos.py文件内容:
#!/usr/bin/env python

import rospy

import tf

import time

from tf.transformations import *

from std_msgs.msg import String

from geometry_msgs.msg import Pose

from geometry_msgs.msg import Quaternion

filenm="/opt/bp/tmp"

tms=

tp_x=0.0

tp_y=0.0

tp_a=0.0

i=tms

def get_pos(data):

    global tp_x

    global tp_y

    global tp_a

    global i

    global tms

    (roll, pitch, yaw) = euler_from_quaternion([data.orientation.x, data.orientation.y, data.orientation.z, data.orientation.w])

    if(i==):

        rospy.loginfo("current position(x:%f,y:%f),theta:%f", data.position.x, data.position.y, yaw)

        if(tp_x==round(data.position.x,)):

            if(tp_y==round(data.position.y,)):

                if(tp_a==round(yaw,)):

                    rospy.loginfo("still!")

                else:

                    with open(filenm, 'w+') as f:

                        f.write(str(data.position.x)+","+str(data.position.y)+","+str(yaw))

                    rospy.loginfo("write!")

            else:

                with open(filenm, 'w+') as f:

                    f.write(str(data.position.x)+","+str(data.position.y)+","+str(yaw))

                rospy.loginfo("write!")

        else:

            with open(filenm, 'w+') as f:

                f.write(str(data.position.x)+","+str(data.position.y)+","+str(yaw))

            rospy.loginfo("write!")

        i=tms

    tp_x=round(data.position.x,)

    tp_y=round(data.position.y,)

    tp_a=round(yaw,)

    i=i-

    #rospy.loginfo("current position(x:%f,y:%f,z:%f)", data.position.x, data.position.y, data.position.z)

def poslistener():

    # In ROS, nodes are uniquely named. If two nodes with the same

    # name are launched, the previous one is kicked off. The

    # anonymous=True flag means that rospy will choose a unique

    # name for our 'listener' node so that multiple listeners can

    # run simultaneously.

    rospy.init_node('poslistener', anonymous=True)

    rospy.Subscriber("robot_pose", Pose, get_pos)

    # spin() simply keeps python from exiting until this node is stopped

    rospy.spin()

if __name__ == '__main__':

    poslistener()
ros 编译包含脚本文件以及launch文件的更多相关文章
- ROS Learning-010 beginner_Tutorials 编写简单的启动脚本文件(.launch 文件)
ROS Indigo beginner_Tutorials-09 编写简单的启动脚本文件 我使用的虚拟机软件:VMware Workstation 11 使用的Ubuntu系统:Ubuntu 14.0 ...
- ROS学习笔记六:xxx.launch文件详解
每当我们需要运行一个ROS节点或工具时,都需要打开一个新的终端运行一个命令.当系统中的节点数量不断增加时,每个节点一个终端的模式会变得非常麻烦.那么有没有一种方式可以一次性启动所有节点呢?答案当然是肯 ...
- 4.2 ROS节点运行管理launch文件
4.2 ROS节点运行管理launch文件 关于 launch 文件的使用我们已经不陌生了,在第一章内容中,就曾经介绍到: 一个程序中可能需要启动多个节点,比如:ROS 内置的小乌龟案例,如果要控制乌 ...
- python ros 使用launch文件启动脚本
目录结构 在包里面新建scripts文件夹,里面放运行的脚本文件,记得设置执行权限 然后新建launch文件夹,新建launch文件按照如下格式写: <node pkg="initia ...
- ROS启动多launch文件
在ROS工程中经常需要启动好几个launch文件,比较不方便,有下面两种方法可以更高效些: 重写一个大型的launch文件,将所有的节点的启动配置信息都包含进去. 通过bash写一个xxx.sh文件, ...
- ROS Learning-032 (提高篇-010 Launch)Launch 深入研究 --- (启动文件编程)ROS 的 XML语法简介
ROS 提高篇 之 Launch 深入研究 - 01 - 启动文件的编程 - ROS 的 XML语法简介 我使用的虚拟机软件:VMware Workstation 11 使用的Ubuntu系统:Ubu ...
- (八) .launch文件 ---编写简单的启动脚本文件
下面我们将介绍,如何编写一个启动脚本程序:(.launch文件) 还记得我们在 创建ROS软件包教程 中创建的第一个程序包(beginner_tutorials)吗,现在我们要使用它. 在 begin ...
- ROS launch 文件的编写
ROS提供了一个同时启动节点管理器(master)和多个节点的途径,即使用启动文件(launch file).事实上,在ROS功能包中,启动文件的使用是非常普遍的.任何包含两个或两个以上节点的系统都可 ...
- Ros学习——launch文件解析
launch文件的重点是:节点(node)元素的集合. roslaunch 则是让所有的节点共享同一个终端. 1.标签(元素)说明 1. group标签 2. node标签 <group ns= ...
随机推荐
- PAT Spell It Right [非常简单]
1005 Spell It Right (20)(20 分) Given a non-negative integer N, your task is to compute the sum of al ...
- rsync 配置详解
安装 [root@localhost ~]# yum install -y rsync [root@localhost ~]# systemctl start rsyncd [root@localho ...
- [LeetCode] 42. Trapping Rain Water_hard tag: Two Pointers
Given n non-negative integers representing an elevation map where the width of each bar is 1, comput ...
- CentOS6.5安装Redis数据库
1.以安装redis2.8.19为例 下载安装包:http://redis.io tar zxvf redis-2.8.19.tar.gz #解压 cd redis-2.8.19 #进入解压后的文件夹 ...
- [转]Mac Appium环境安装
原文:https://blog.csdn.net/dongqiushan/article/details/53326518 1.安装JDK; 2.安装Android SDK; 3.安装brew; 4. ...
- Python: 序列: 过滤序列元素
问题: 你有一个数据序列,想利用一些规则从中提取出需要的值或者是缩短序列 answer: eg1:列表推导 最简单的过滤序列元素的方法就是使用列表推导.比如:>>> mylist = ...
- python 单例模式,一个类只能生成唯一的一个实例,重写__new__方法详解
单例:一个类只能生成唯一的一个实例 每个类只要被实例化了,他的私有属性 '_instance'就会被赋值,这样理解对吗 对 #方法1,实现__new__方法 #并在将一个类的实例绑定到类变量_inst ...
- Linux基础命令---ln
ln 为指定的目录或者文件创建链接,如果没有指定链接名,那么会创建一个和源文件名字一样的链接. 此命令的适用范围:RedHat.RHEL.Ubuntu.CentOS.SUSE.openSUSE.Fed ...
- 20145225唐振远《网络对抗》 Web安全基础实践
20145225唐振远<网络对抗>Web安全基础实践 参考博客:20145215 卢肖明 基础问题回答 (1)SQL注入攻击原理,如何防御? SQL注入攻击就是通过把SQL命令插入到Web ...
- #if 1...#endif
1. “#if 0/#if 1 ... #endif”的作用,我们知道,C标准不提供C++里的“//”这样的单行风格注释而只提供“/* */”这样的块注释功能,我们通常使用它写代码中说明性的注释文字( ...