
Robot_bfs
Description
The GO command has one integer parameter n in {1,2,3}. After receiving this command the robot moves n meters in the direction it faces.
The TURN command has one parameter which is either left or right. After receiving this command the robot changes its orientation by 90o in the direction indicated by the parameter.
The execution of each command lasts one second.
Help researchers of RMI to write a program which will determine the minimal time in which the robot can move from a given starting point to a given destination.
Input
Output
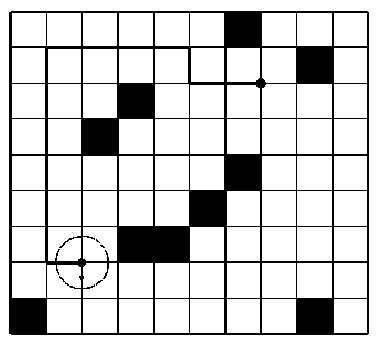
Sample Input
9 10

0 0 0 0 0 0 1 0 0 0

0 0 0 0 0 0 0 0 1 0

0 0 0 1 0 0 0 0 0 0

0 0 1 0 0 0 0 0 0 0

0 0 0 0 0 0 1 0 0 0

0 0 0 0 0 1 0 0 0 0

0 0 0 1 1 0 0 0 0 0

0 0 0 0 0 0 0 0 0 0

1 0 0 0 0 0 0 0 1 0

7 2 2 7 south

0 0
Sample Output
12
【题意】给出一个n*m的图,给出起点和终点的坐标以及刚开始所处的方向,求最少步数,不能走出则输出-1;
【思路】
1、2种命令,一种是向现在所面向的方向走1-3步,另外一种是向左或向右90度转向(不能向后转)。
2、不允许出界和到达障碍物。
3、对搜索进行去重操作的时候需要记录所处位置的方向,因为这个题存在方向的问题,需要注意下,可以设置数组为vis用三维,第三维代表4个方向。
4、存在起点等于终点的情况,还有就是终点是无法到达的。
#include<iostream>

#include<queue>

#include<stdio.h>

#include<string.h>

using namespace std;

const int N=+;

struct node

{

    int x,y;

    int t;

    int pos;

};

node cur;

int n,m,ex,ey,mp[N][N],ans;

bool vis[N][N][];

int dirx[]={-,,,},diry[]={,,,-};

int getPos(char *str)

{

    if(!strcmp(str,"north")) return ;

    if(!strcmp(str,"east")) return ;

    if(!strcmp(str,"south")) return ;

        return ;

}

bool isgo(int x,int y)

{

    if(x<||x>=n||y<||y>=m)

        return false;

    if(mp[x][y]||mp[x+][y]||mp[x][y+]||mp[x+][y+])

        return false ;

    return true;

}

void bfs()

{

    queue<node>qu;

    qu.push(cur);

    vis[cur.x][cur.y][cur.pos]=;

    int ans=-;

    if(cur.x==ex&&cur.y==ey)//起点相同

    {

        printf("0\n");

        return ;

    }

    if(!isgo(ex,ey))//终点出界

    {

        printf("-1\n");

        return ;

    }

    while(!qu.empty())

    {

        node now=qu.front();

        qu.pop();

        int xx=now.x;

        int yy=now.y;

        for(int i=;i<=;i++)

        {

            xx+=dirx[now.pos];

            yy+=diry[now.pos];

            if(!isgo(xx,yy)) break ;

            if(xx==ex&&yy==ey)

            {

                ans=now.t+;

                break;

            }

            if(!vis[xx][yy][now.pos])

            {

                node tmp;

                tmp.x=xx;

                tmp.y=yy;

                tmp.t=now.t+;

                tmp.pos=now.pos;

                vis[xx][yy][tmp.pos]=;

                qu.push(tmp);

            }

        }

        for(int i=;i<;i++)

        {

            if(max(now.pos,i)-min(now.pos,i)==)

                continue;

            if(vis[now.x][now.y][i]) continue;

            node next=now;

            next.t=now.t+;

            next.pos=i;

            vis[next.x][next.y][next.pos]=;

            qu.push(next);

        }

        if(ans!=-) break;

    }

    if(ans!=-) printf("%d\n",ans);

    else printf("-1\n");

    return ;

}

int main()

{

    while(scanf("%d%d",&n,&m))

    {

        if(n==&&m==) break;

        for(int i=;i<=n;i++)

        {

            for(int j=;j<=m;j++)

            {

                scanf("%d",&mp[i][j]);

            }

        }

        memset(vis,,sizeof(vis));

        scanf("%d%d",&cur.x,&cur.y);

        scanf("%d%d",&ex,&ey);

        char op[];

        scanf("%s",op);

        cur.pos=getPos(op);

        cur.t=;

        bfs();

    }

    return ;

}
Robot_bfs的更多相关文章
随机推荐
- touch的属性
touch命令:建立文件 touch的功能并不是用来创建新文件的,创建文件是touch命令的一个特殊情况,touch是用来修改指定的文件的访问和修改时间属性,如果指定的文件不存在,将建立一个新的空 ...
- sphinx索引分析续
4.10 同义词文件/Synonym 同义词文件格式 from => to AT &T => AT&T AT & T => AT & T standa ...
- Ubuntu 16.04 安装 .NET Core[转]
upir@upir-Rev-1-0:~$ sudo sh -c 'echo "deb [arch=amd64] https://apt-mo.trafficmanager.net/repos ...
- 14071702(SkeletalControl_Limb)
[目标] SkeletalControl_Limb [思路] HumanIK的15 个节点 CCDIK [步骤] 1 先编译[!BuildAll] [注]先把SYSTEM文件夹该为非只读属性,编译生成 ...
- fileupload图片预览功能
FileUpload上传图片前首先预览一下 看看效果: 在专案中,创建aspx页面,拉上FileUpload控件一个Image,将用来预览上传时的图片. <%@ Page Language=&q ...
- 处理GitHub不允许上传大于100M文件问题
第一步输入命令 cd /Users/Dora/Desktop/XXX(cd后面的这个路径要换成你自己项目的路径) 第二步输入命令 git rm --cached/Users/Dora/Desktop/ ...
- ionic环境搭建及新建项目中的各种问题
具体流程可见http://bbs.ionic-china.com/read-7.html 问题1.安装ionic cordova失败 解决方法:修改npm的源,npm config set regis ...
- Altium Designer自动更新——解决方法
今天,打开AD,一直显示更新,关机重启也不管事. 然后,我把AD安装目录下,system文件夹下的Installation文件夹删了.就不再更新了.
- seleniu+python+chrome的调试
1.下载chrome,下载chrome driver,下载地址:http://code.google.com/p/chromedriver/downloads/list 2.安装chrome,默认路径 ...
- IOS开发:监听来电状态的改变。
#import <CoreTelephony/CTCallCenter.h> #import <CoreTelephony/CTCall.h> @property(nonato ...