
Writing a Simple Publisher and Subscriber
用c++实现一个publisher/subscriber
publisher
#include "ros/ros.h"

#include "std_msgs/String.h"

#include <sstream>

/**

 * This tutorial demonstrates simple sending of messages over the ROS system.

 */

int main(int argc, char **argv)

{

  /**

   * The ros::init() function needs to see argc and argv so that it can perform

   * any ROS arguments and name remapping that were provided at the command line.

   * For programmatic remappings you can use a different version of init() which takes

   * remappings directly, but for most command-line programs, passing argc and argv is

   * the easiest way to do it.  The third argument to init() is the name of the node.

   *

   * You must call one of the versions of ros::init() before using any other

   * part of the ROS system.

   */

  ros::init(argc, argv, "talker");

  /**

   * NodeHandle is the main access point to communications with the ROS system.

   * The first NodeHandle constructed will fully initialize this node, and the last

   * NodeHandle destructed will close down the node.

   */

  ros::NodeHandle n;

  /**

   * The advertise() function is how you tell ROS that you want to

   * publish on a given topic name. This invokes a call to the ROS

   * master node, which keeps a registry of who is publishing and who

   * is subscribing. After this advertise() call is made, the master

   * node will notify anyone who is trying to subscribe to this topic name,

   * and they will in turn negotiate a peer-to-peer connection with this

   * node.  advertise() returns a Publisher object which allows you to

   * publish messages on that topic through a call to publish().  Once

   * all copies of the returned Publisher object are destroyed, the topic

   * will be automatically unadvertised.

   *

   * The second parameter to advertise() is the size of the message queue

   * used for publishing messages.  If messages are published more quickly

   * than we can send them, the number here specifies how many messages to

   * buffer up before throwing some away.

   */

  //

  ros::Publisher chatter_pub = n.advertise<std_msgs::String>("chatter", 1000);

  ros::Rate loop_rate(10);

  /**

   * A count of how many messages we have sent. This is used to create

   * a unique string for each message.

   */

  int count = 0;

  while (ros::ok())

  {

    /**

     * This is a message object. You stuff it with data, and then publish it.

     */

    std_msgs::String msg;

    std::stringstream ss;

    ss << "hello world " << count;

    msg.data = ss.str();

    ROS_INFO("%s", msg.data.c_str());

    /**

     * The publish() function is how you send messages. The parameter

     * is the message object. The type of this object must agree with the type

     * given as a template parameter to the advertise<>() call, as was done

     * in the constructor above.

     */

    chatter_pub.publish(msg);

    ros::spinOnce();

    loop_rate.sleep();

    ++count;

  }

  return 0;

}
- 初始化ros system
ros::init(argc, argv, "talker"); //使得可以通过命令行进行name remapping - 告知master程序想向什么topic publish何种type的msg
ros::Publisher chatter_pub = n.advertise<std_msgs::String>("chatter", 1000); - publish
chatter_pub.publish(msg);
几个知识点:
- ros::init(argc, argv, "talker");中的"talker"是node name。不可以含/,并且该name要全局唯一.
Node names must be unique in a running system The name used here must be a base name, ie. it cannot have a / in it.
- ros::NodeHandle n;
第一个handle会对node初始化,最后一个destruct的handle会clean掉该node正在使用的相关资源.
Create a handle to this process' node. The first NodeHandle created will actually do the initialization of the node, and the last one destructed will cleanup any resources the node was using.
- n.advertise<std_msgs::String>("chatter", 1000)
第二个参数含义为队列大小,当消费方消费过慢,比如发了1001个msg,还无人sub,那么第一条会被丢弃.
his lets the master tell any nodes listening on chatter that we are going to publish data on that topic. The second argument is the size of our publishing queue. In this case if we are publishing too quickly it will buffer up a maximum of 1000 messages before beginning to throw away old ones.
- ros::Publisher chatter_pub = n.advertise<std_msgs::String>("chatter", 1000);
注意,出了作用域,chatter_pub将不再可以向相应topic发送消息
NodeHandle::advertise() returns a ros::Publisher object, which serves two purposes: 1) it contains a publish() method that lets you publish messages onto the topic it was created with, and 2) when it goes out of scope, it will automatically unadvertise.
ros::Rate loop_rate(10);
10代表10HZ,即每秒10次,这样loop_rate.sleep()的时候自己计算该sleep多久;ros::ok() will return false if:
- 收到SIGINT信号(ctrl + c)
- 被同名node踢下网络
- 程序里调用了ros::shutdown()
- 所有的ros::NodeHandles都destroy了
ros::spinOnce();
如果不加spinOnce,回调函数将不会被调用.
Calling ros::spinOnce() here is not necessary for this simple program, because we are not receiving any callbacks. However, if you were to add a subscription into this application, and did not have ros::spinOnce() here, your callbacks would never get called. So, add it for good measure.
subscriber
#include "ros/ros.h"

#include "std_msgs/String.h"

/**

 * This tutorial demonstrates simple receipt of messages over the ROS system.

 */

void chatterCallback(const std_msgs::String::ConstPtr& msg)

{

  ROS_INFO("I heard: [%s]", msg->data.c_str());

}

int main(int argc, char **argv)

{

  /**

   * The ros::init() function needs to see argc and argv so that it can perform

   * any ROS arguments and name remapping that were provided at the command line.

   * For programmatic remappings you can use a different version of init() which takes

   * remappings directly, but for most command-line programs, passing argc and argv is

   * the easiest way to do it.  The third argument to init() is the name of the node.

   *

   * You must call one of the versions of ros::init() before using any other

   * part of the ROS system.

   */

  ros::init(argc, argv, "listener");

  /**

   * NodeHandle is the main access point to communications with the ROS system.

   * The first NodeHandle constructed will fully initialize this node, and the last

   * NodeHandle destructed will close down the node.

   */

  ros::NodeHandle n;

  /**

   * The subscribe() call is how you tell ROS that you want to receive messages

   * on a given topic.  This invokes a call to the ROS

   * master node, which keeps a registry of who is publishing and who

   * is subscribing.  Messages are passed to a callback function, here

   * called chatterCallback.  subscribe() returns a Subscriber object that you

   * must hold on to until you want to unsubscribe.  When all copies of the Subscriber

   * object go out of scope, this callback will automatically be unsubscribed from

   * this topic.

   *

   * The second parameter to the subscribe() function is the size of the message

   * queue.  If messages are arriving faster than they are being processed, this

   * is the number of messages that will be buffered up before beginning to throw

   * away the oldest ones.

   */

  ros::Subscriber sub = n.subscribe("chatter", 1000, chatterCallback);

  /**

   * ros::spin() will enter a loop, pumping callbacks.  With this version, all

   * callbacks will be called from within this thread (the main one).  ros::spin()

   * will exit when Ctrl-C is pressed, or the node is shutdown by the master.

   */

  ros::spin();

  return 0;

}
- 初始化ROS
- subscribe chatter topic
- spin,等待msg到达
- msg到达时,回调函数会被调用
和publisher类似
- ros::Subscriber sub = n.subscribe("chatter", 1000, chatterCallback);
只是需要指定一个回调函数,作为收到消息时的处理函数.
void chatterCallback(const std_msgs::String::ConstPtr& msg),回调传入的是一个boost:share_ptr。你可以存储这个ptr,不用担心其指向的msg被删除.
This is the callback function that will get called when a new message has arrived on the chatter topic. The message is passed in a boost shared_ptr, which means you can store it off if you want, without worrying about it getting deleted underneath you, and without copying the underlying data.
- ros::spin()
ros::spin() enters a loop, calling message callbacks as fast as possible. Don't worry though, if there's nothing for it to do it won't use much CPU. ros::spin() will exit once ros::ok() returns false
可能类似于select之类的吧,循环并不会太耗cpu。
编译
修改CMakeLists.txt
add_executable(talker src/talker.cpp)

target_link_libraries(talker ${catkin_LIBRARIES})

add_dependencies(talker beginner_tutorials_generate_messages_cpp)

add_executable(listener src/listener.cpp)

target_link_libraries(listener ${catkin_LIBRARIES})

add_dependencies(listener beginner_tutorials_generate_messages_cpp)
进入顶层目录执行make.
This will create two executables, talker and listener, which by default will go into package directory of your devel space, located by default at ~/catkin_ws/devel/lib/.
测试publisher和sunscriber

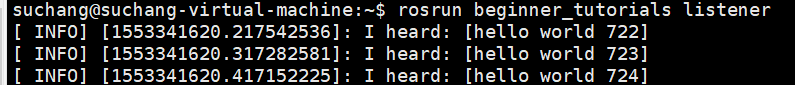
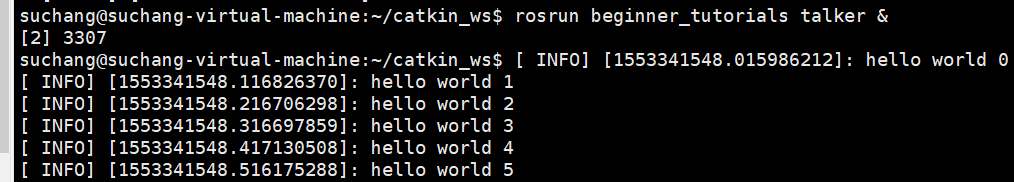
https://askubuntu.com/questions/690631/executables-vs-shared-objects
之前一直用的centos,并且工作项目里bin和lib下的文件是严格区别开来的,一直理解的是可执行程序是executable,而lib下的是动态库shared object.这个理解实际上是有误的.
实际测试,先启动talker,后启动listener,listener只会消费他启动之后收到的监听topic上的消息.
再举个例子,先启动talker,关闭talker,再启动listener,listener不会受到任何消息.
实际上,master并不承担消息中转的作用,他不是消息中间件,各个node只是向他注册消息,告知master自己的身份,想发或想收什么样的消息.node之间还是直接通信的
Writing a Simple Publisher and Subscriber的更多相关文章
- ROS学习手记 - 8 编写ROS的Publisher and Subscriber
上一节我们完成了 message & srv 文件的创建和加入编译,这次我们要玩简单的Publisher 和 Subscriber 要玩 Publisher 和 Subscriber, 需要具 ...
- Writing a simple Lexer in PHP/C++/Java
catalog . Comparison of parser generators . Writing a simple lexer in PHP . phc . JLexPHP: A PHP Lex ...
- Publisher和Subscriber节点
一.Publisher节点 /*"ros/ros.h"里面包含了ROS系统内最常用的一些头文件,包含此文件,便可以使用ROS的核心功能.*/#include "ros/r ...
- Writing a Simple Service and Client (C++)
此前说的publisher/subscriber都是广播式的,subscriber被动地接收消息,二者没有request/response这种交互. Service Node Client Node ...
- C#的publisher与subscriber,事件发布者与订阅者
说明:示例借鉴自这里,但原版很不友好,于是修改了下,一目了然. 直接上代码: using System; using System.Collections.Generic; using System. ...
- Writing a Simple YARN Application 从hadoop生态抽出yarn ,单独使用yarn
Apache Hadoop 2.9.1 – Hadoop: Writing YARN Applications https://hadoop.apache.org/docs/current/hadoo ...
- ROS验证publisher和subscriber
在前面的两篇博客中我们用C++在ROS中创建了一个发布者和接收者,并使用catkin_make构建了新的节点,下面就需要验证一下,我们写的是否正确. 首先运行roscore roscore 在使用ca ...
- ROS教程
Learning ROS 学习ROS Depending on your learning style and preferences, you can take two approaches to ...
- Publisher/Subscriber(发布/订阅者)消息模式开发流程
该模式的作用是发布者和订阅者 可以相互发送消息 发布者和订阅者都充当 生产者和消费者 发布者 package publisher.to.subscriber; import java.awt.font ...
随机推荐
- ArcGIS API for JavaScript 入门教程[1] 渊源
->对于萌新,你可能需要了解一下这个东西是什么 ->对于已经知道要用这个东西的开发者,你可能需要了解一下它的底层机制 不针对大牛.龟速更新ing. 转载注明出处.博客园&CSDN& ...
- MYSQL———正则表达式查询!
在使用select查询的过程中,有时会用到正则表达式对结果进行查询,将学习到的内容进行总结! 一 语法结构如下: 二 常用匹配方式进行示例说明 首先创建表student,表的结构如下: 1·^:查询s ...
- 【原】js数组对象去重最简单的方法
简单的数组去重是比较简单的,方法也特别多,如给下面的数组去重: let arr = [1,2,2,4,9,6,7,5,2,3,5,6,5] 最常用的可以用for循环套for循环,再用splice删除重 ...
- Appscan 工具快速上手教程
1.appscan扫描 (1)白盒扫描=静态扫描,扫描源代码.(2)动态扫描=黑盒扫描,用工具来模拟黑客的攻击,查看应用层的响应.产品内部会有大量受攻击的库,当我们把一个模拟攻击发给我们的应用的时 ...
- 死磕 java集合之ConcurrentLinkedQueue源码分析
问题 (1)ConcurrentLinkedQueue是阻塞队列吗? (2)ConcurrentLinkedQueue如何保证并发安全? (3)ConcurrentLinkedQueue能用于线程池吗 ...
- asp.net core 系列之中间件基础篇(middleware)
中间件是一种插入到管道上进行处理请求和响应的软件:每个中间件组件具有下面的功能: 选择是否把请求传递到管道上的下一个组件 可以在下一个组件的之前和之后做处理工作 请求委托(request delega ...
- Linq中 AsQueryable(), AsEnumerable()和ToList()的区别和用法
Linq中 AsQueryable(), AsEnumerable()和ToList()的区别和用法:在写LINQ语句的时候,往往会看到AsEnumerable() ,AsQueryable() 和T ...
- jQuery中对未来的元素绑定事件用 on
最近项目需要点击弹窗里面的a标签出现外连接跳转提示 <a href="javascript:void(0);" target="_blank" id=&q ...
- Web前端 css实现元素垂直居中的常用方法
方法1:table-cell html结构: 1 2 3 <div class="box box1"> <span>垂直居中</spa ...
- MySQL和SQLyog的配置-安装及遇到的问题
1. 安装MySQL 我先是参考了菜鸟教程上的#Windows 上安装 MySQL #版块的安装教程,不过经历了种种磨难,我最后是按照#此篇博客#安装成功的. 这两篇教程最大的差别是在于下载的版本不同 ...