
am335x system upgrade kernel ethernet(四)
1 Scope of Document
This document describes ethernet hardware design and porting KZS8081 to uboot and kernel
2 Requiremen
2.1 Function Requirement
Use KZS8081 in am335x, user space use network interface
2.2 Performance Requirement
Support Highest Link-Up Speed( 10/100 Mbps )
3 Hardware Overview
ethernet interface,pin map:
// send signal
AM335X_RMII1_TXD1 -------------MII1_TXD1
AM335X_RMII1_TXD0 -------------MII1_TXD0
AM335X_RMII1_TXEN -------------MII1_TXEN
// receive signal
AM335X_RMII1_RXD0 -------------MII1_RXD0
AM335X_RMII1_RXD1 -------------MII1_RXD1
AM335X_RMII1_RXERR ---------------MII1_RXERR
AM335X_RMII1_REFCLK --------------MII1_REFCLK
// relate with phy addr
AM335X_RMII1_CRS_DV-------------RMII1_CRS
// control signal
AM335X_RMII1_MDIO_CLK -------------MDIO_CLK
AM335X_RMII1_MDIO_DATA------------MDIO_DATA

Figure 1 ethernet interface block diagram
4 Functional Description
4.1 Functional Block Diagram
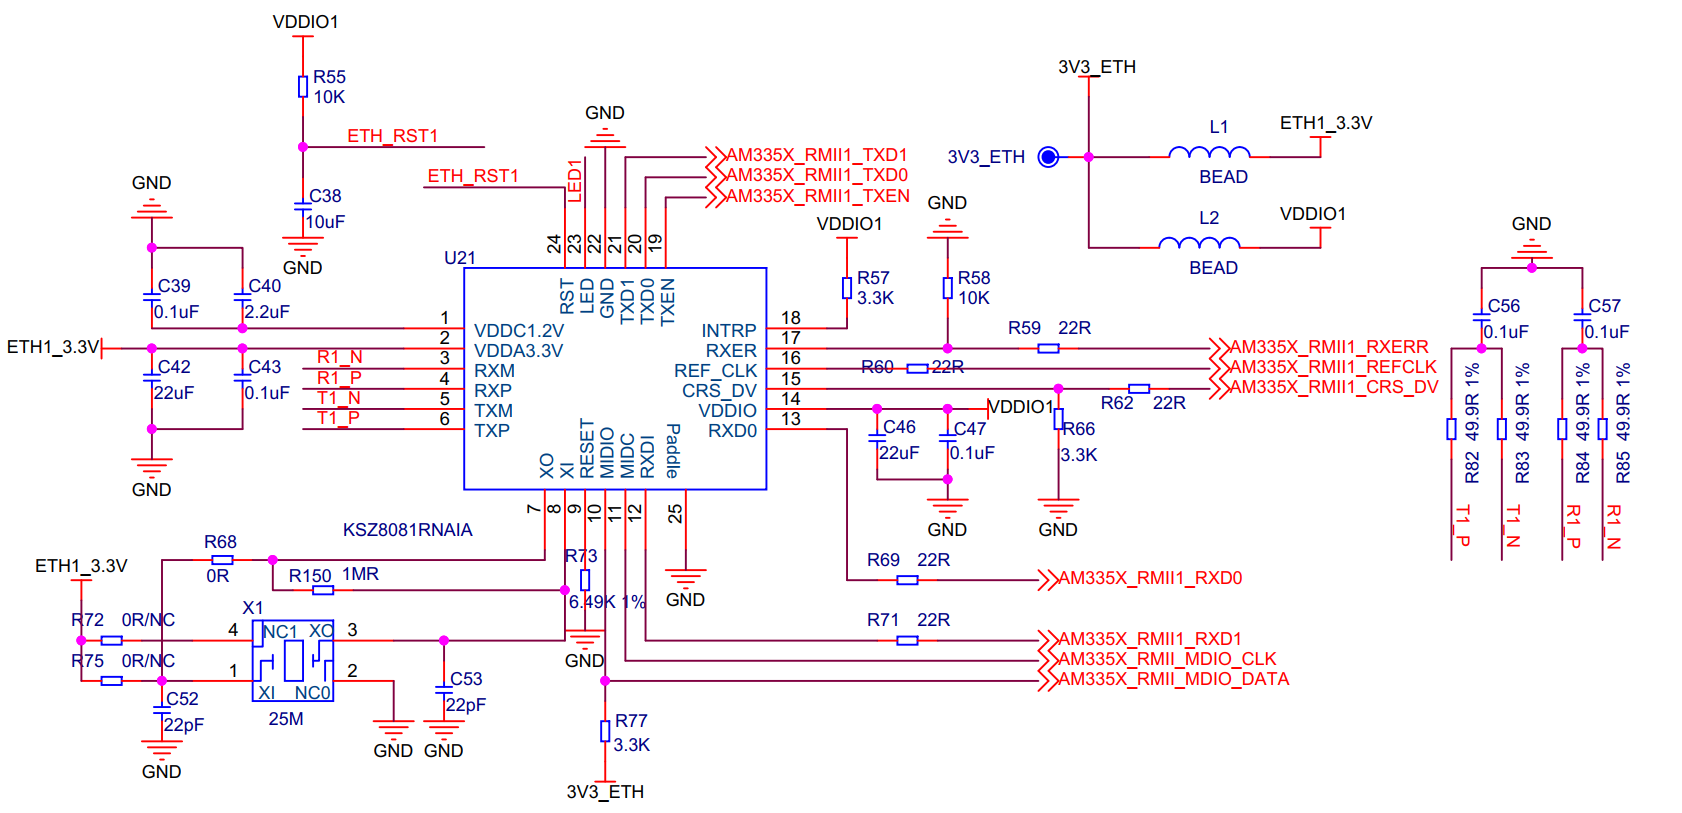
Figure 2 EMAC connect to KSZ8081 phy
AM335X EMAC module connect to KSZ8081 phy
4.2 mdio bus specification
4.2.1 Overview
Most network devices are connected to a PHY by means of a management bus.Different devices use different busses (though some share common interfaces).
The MDIO interface is implemented by two signals:
MDC clock: driven by the MAC device to the PHY.
MDIO data: bidirectional, the PHY drives it to provide register data at the end of a read operation.
The bus only supports a single MAC as the master, and can have up to 32 PHY slaves.
The MDC can be periodic, with a minimum period of 400 ns, which corresponds to a maximum frequency of 2.5 MHz. Newer chips, however, allow faster accesses.
The MDIO requires a specific pull-up resistor of 1.5 kΩ to 10 kΩ, taking into account the total worst-case leakage current of 32 PHYs and one MAC.
4.2.2 Bus timing
Before a register access, PHY devices generally require a preamble of 32 ones to be sent by the MAC on the MDIO line. The access consists of 16 control bits, followed by 16 data bits. The control bits consist of 2 start bits, 2 access type bits (read or write), the PHY address (5 bits), the register address (5 bits), and 2 "turnaround" bits.
During a write command, the MAC provides address and data. For a read command, the PHY takes over the MDIO line during the turnaround bit times, supplies the MAC with the register data requested, then releases the MDIO line.
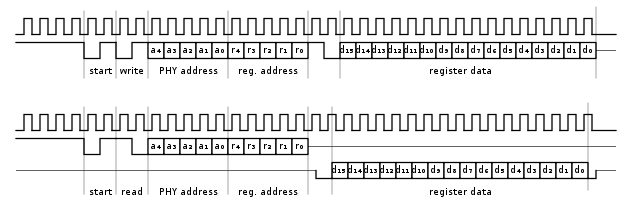
When the MAC drives the MDIO line, it has to guarantee a stable value 10 ns (setup time) before the rising edge of the clock MDC. Further, MDIO has to remain stable 10 ns (hold time) after the rising edge of MDC.
When the PHY drives the MDIO line, the PHY has to provide the MDIO signal between 0 and 300 ns after the rising edge of the clock. Hence, with a minimum clock period of 400 ns (2.5 MHz maximum clock rate) the MAC can safely sample MDIO during the second half of the low cycle of the clock.
4.2.3 MDIO Packet Format
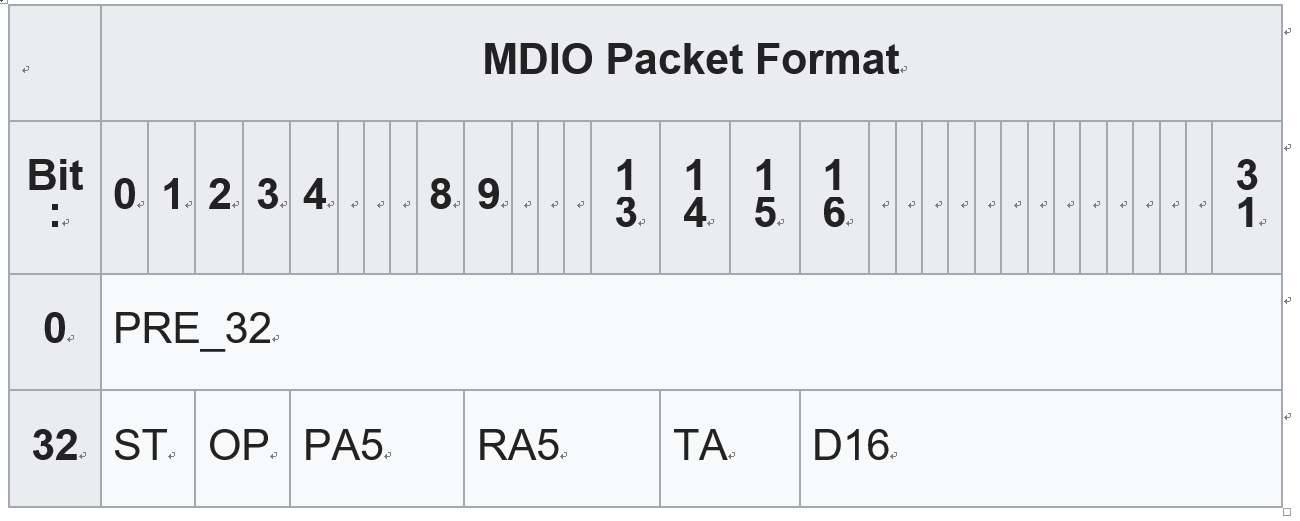
PRE_32
The first field in the MDIO header is the Preamble. During the preamble, the MAC sends 32 bits, all '1', on the MDIO line.
ST
The Start field consists of 2 bits and always contains the combination '01'.
OP
The Opcode consists of 2 bits. There are two possible opcodes, read '10' or write '01'.
PA5
5 bits, PHY address.
RA5
The Register Address field indicates the register to be written to or read from. It is 5 bits long.
TA
The turn-around field is 2 bits long. When data is being written to the PHY, the MAC writes '10' to the MDIO line. When data is being read, the MAC releases the MDIO line.
D16
16 bits, data. This can be sent by either the SME or the PHY, depending on the value of the OP field.
Z
Tristate MDIO.
5 Porting
5.1 Uboot porting
NA
5.2 Kernel porting
am335x.dtsi
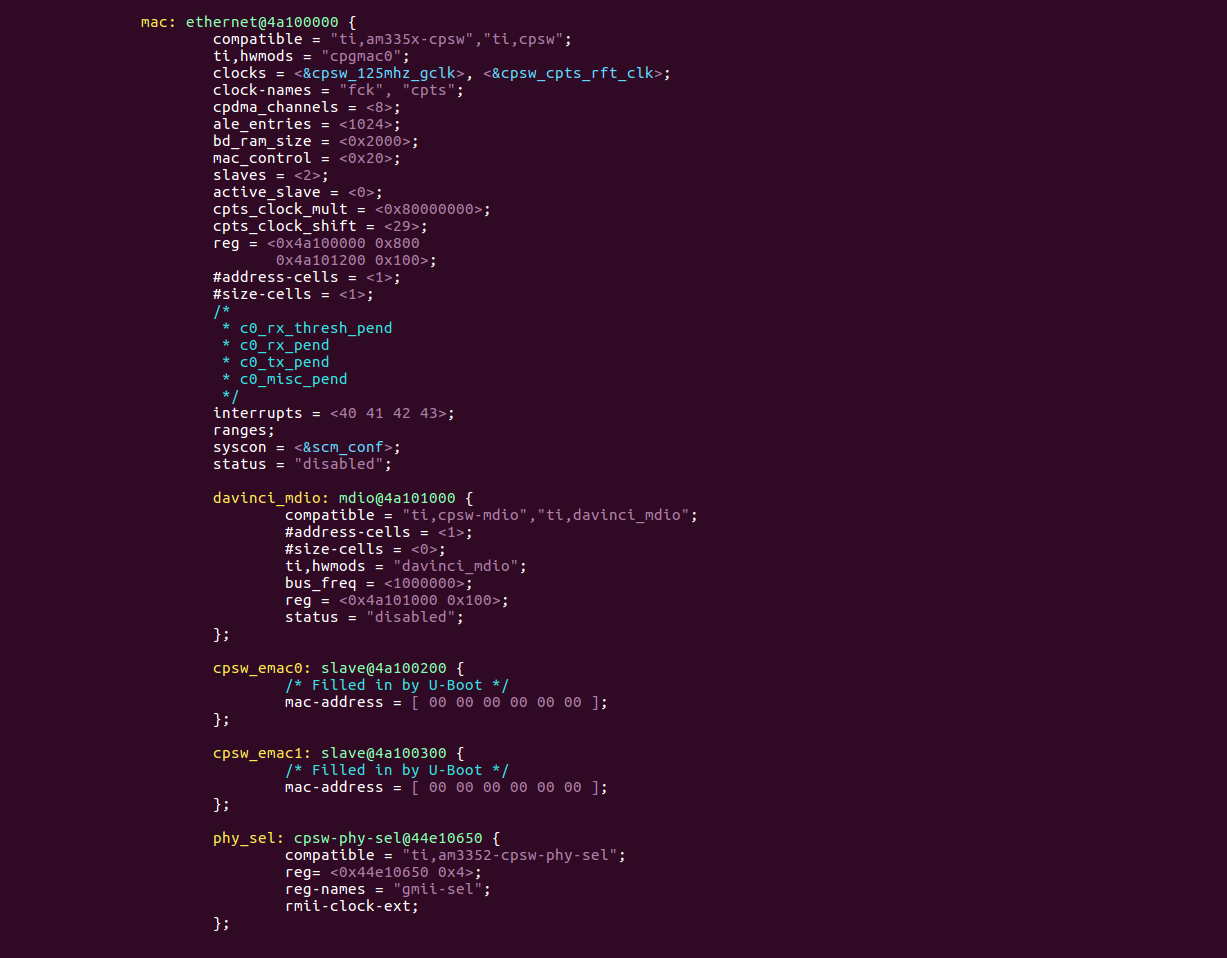
am335x-evm.dts
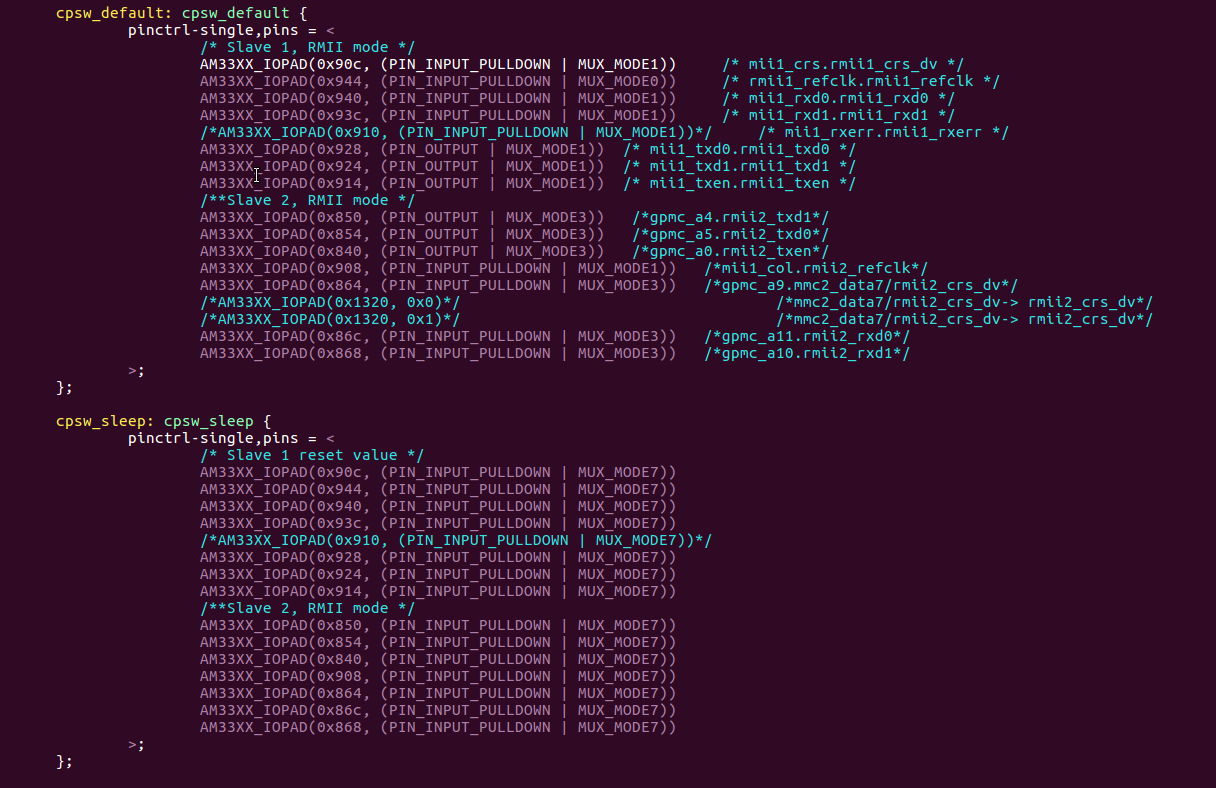
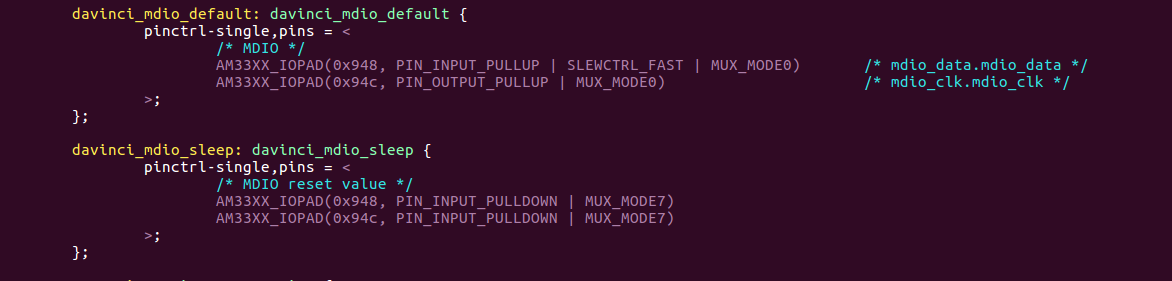
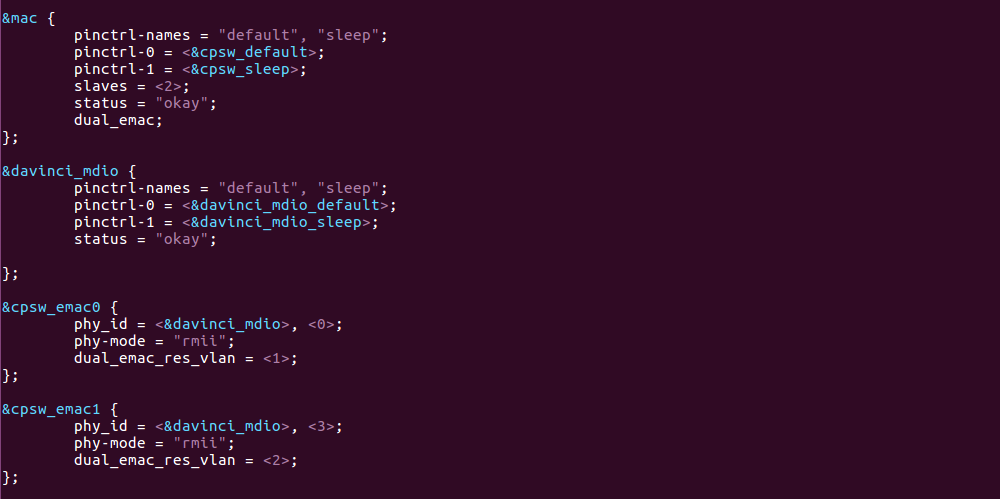
In the new kernel version,we need to change the dts file, to do the pin mux, register phy id , phy connect mode. Then it will work well.
kernel log:
[ 21.514107] Micrel KSZ8081 or KSZ8091 4a101000.mdio:00: attached PHY driver [Micrel KSZ8081 or KSZ8091] (mii_bus:phy_addr=4a101000.mdio:00, irq=POLL)
[ 21.690932] IPv6: ADDRCONF(NETDEV_UP): eth0: link is not ready
[ 21.816198] net eth1: initializing cpsw version 1.12 (0)
[ 21.994187] Micrel KSZ8081 or KSZ8091 4a101000.mdio:03: attached PHY driver [Micrel KSZ8081 or KSZ8091] (mii_bus:phy_addr=4a101000.mdio:03, irq=POLL)
[ 22.106839] IPv6: ADDRCONF(NETDEV_UP): eth1: link is not ready
5.3 Application Interface
The net device interface eth0 eth1
6 Summary
In the KSZ8081 datasheet we can find 32 registers map, the 32 registers is the standard register.
We can ask ourself some question:
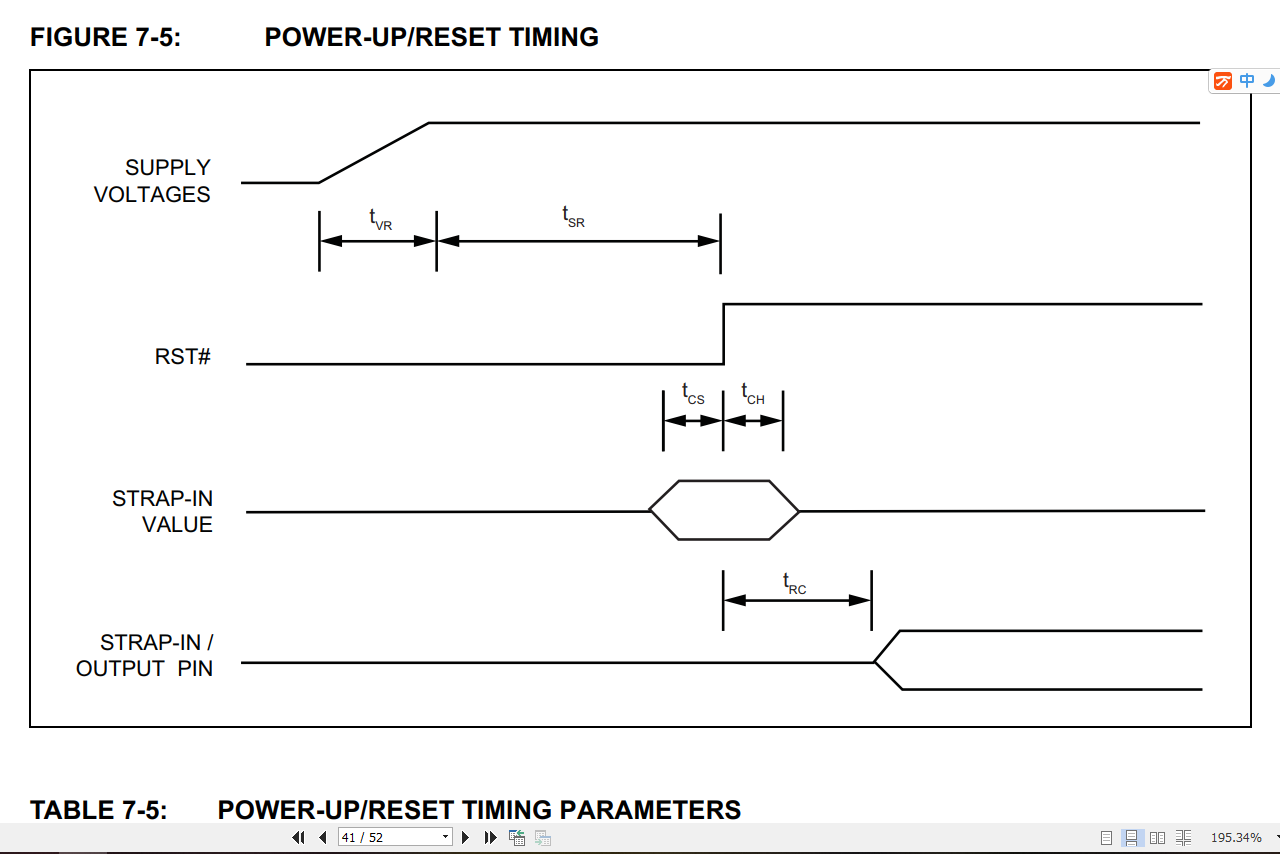
1.How to reset phy?
Reset phy can use gpio base on phy datasheet,such as
2. how to know the phy id?
In phy datasheet we can find our answer.

3. how to cominicate with phy?
Use rmii interface, in the am335x datasheet we can use USERACCESS0/1 register to control rmi interface.
Reading PHY and writing to PHY through the USERACCESS0/1 register using memory browser or
registers window in Code Composer Studio™ is a
effective field-debug feature to troubleshoot PHY issues
(see Table 2).
Table
2. MDIOUSERACCESS0 Register Field Descriptions
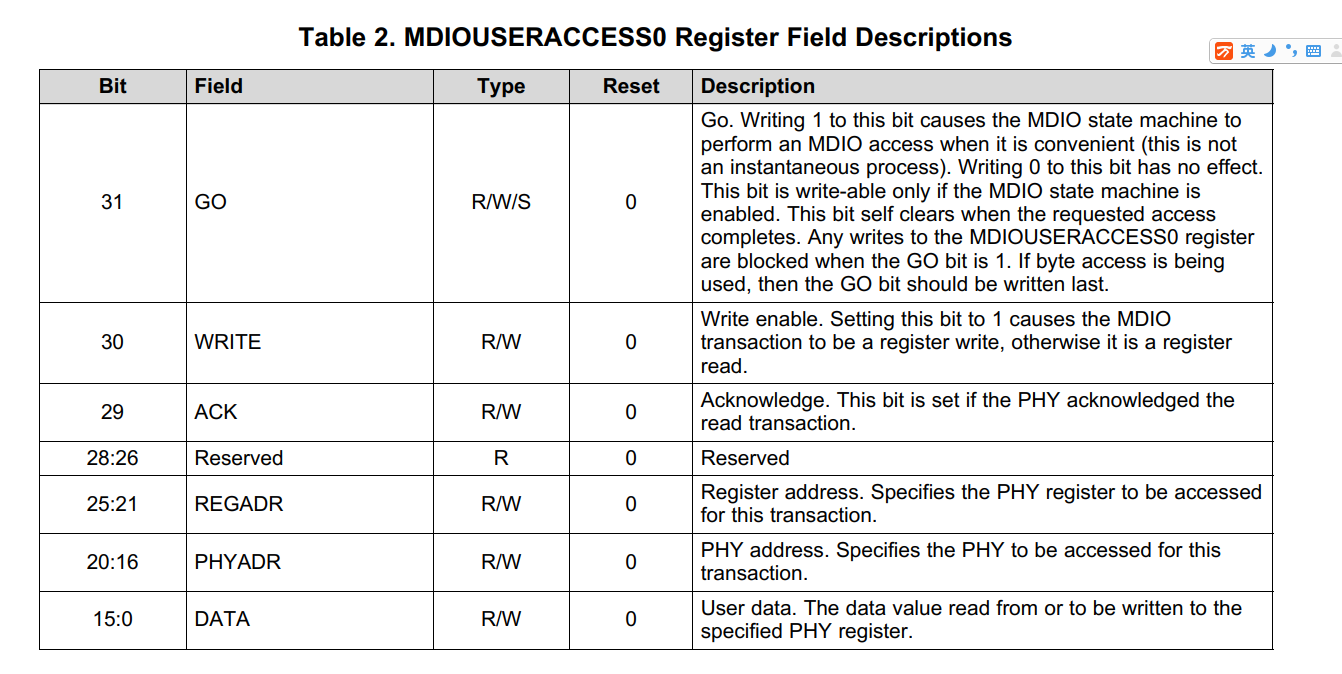
Bit Field Type Reset Description
To read PHY in the memory browser or registers window, follow these steps:
1. Ensure the GO bit in the MDIO user access register (MDIOUSERACCESSn) is
cleared.
2. Write to the GO, REGADR, and PHYADR bits in MDIOUSERACCESSn corresponding to
the PHY and
PHY register to be read.
3. The read data value is available in the DATA bits in MDIOUSERACCESSn after
the module completes
the read operation on the serial bus. Completion of the read operation can be
determined by polling
the GO and ACK bits in MDIOUSERACCESSn. When the GO bit clears, the ACK bit is
set on a
successful read.
To write PHY in the memory browser or registers window, follow these steps:
1. Ensure the GO bit in the MDIO user access register (MDIOUSERACCESSn) is
cleared.
2. Write to the GO, WRITE, REGADR, PHYADR, and DATA bits in MDIOUSERACCESSn
corresponding
to the PHY and PHY register you want to write.
3. The write operation to the PHY is scheduled and completed by the MDIO
module. Completion of the
write operation can be determined by polling the GO bit in MDIOUSERACCESSn for
a 0.
4. how to init phy?
• Connection speed, duplex, and auto-negotiation
•
Auto-MDIX, which determines if a straight or crossover cable is used to connect
to the link partner.
•
Extended full-duplex mode. In extended full-duplex mode, when the PHY is set to
auto-negotiation or
Force
100Base-TX, and the link partner is operated in Force 100Base-TX, the link is
always full
duplex.
When disabled, the decision to work in full-duplex or half-duplex mode follows
IEEE
specification
– half duplex.
•
Detection of transmit error in odd-nibble boundary, which extends TX_EN by one
additional TX_CLK
cycle
and behaves as if TX_ER were asserted during that additional cycle.
•
Additional features like odd nibble insertion and fast link down detection
Most MDIO PHY configuration functions are integrated in the
board library of the Processor SDK
am335x system upgrade kernel ethernet(四)的更多相关文章
- am335x system upgrade kernel can(八)
1 Scope of Document This document describes can bus hardware design and can bus driver developm ...
- am335x system upgrade kernel tf(五)
1 Scope of Document This document describes TF hardware design 2 Requiremen 2.1 Functi ...
- am335x system upgrade kernel ec20 simcom7600ce(十一)
1 Scope of Document This document describes 4G hardware design, support quectel ec20 4G module/ ...
- am335x system upgrade kernel gpio(九)
1 Hardware Overview gpio interface,pin map: AM335X_I2C0_W_C----------------------MCASP0_AXR1 /* ...
- am335x system upgrade kernel uart(七)
1 Scope of Document This document describes UART hardware design, uart driver porting 2 Re ...
- am335x system upgrade kernel i2c rtc eeprom(六)
1 Scope of Document This document describes i2c bus hardware design and support i2c-devices: ee ...
- am335x system upgrade uboot ethernet(二)
系统可以通过SD卡引道之后,为了之后了调试方便 通过查看网卡的硬件设计 正常来说需要注意的有如下几点: 1) 网口 的接线方式: RMII 2) 网口的PHY地址两张网口,这里我们只需先初始化一张网卡 ...
- am335x system upgrade kernel usb stroage(十)
1 Scope of Document This document describes USB hardware design, support stardard usb2.0 port o ...
- am335x system upgrade kernel f-ram fm25l16b(十六)
1 Scope of Document This document describes SPI F-RAM hardware design 2 Requiremen 2.1 ...
随机推荐
- Python使用队列实现Josephus问题
Josephus问题,在这个古老的问题中,N个深陷绝境的人一致同意通过以下方式减少生存的人数.他们围坐一圈(位置记为0~N-1)并从第一个人报数,报到M的人会被杀死, 知道最后一个人留下来.传说中Jo ...
- C#:蓝牙串口读数据和写数据
首次使用C#编写与COM口有关的程序,期间遇到了很多问题,写下自己的经验总结,如有错漏,欢迎批评指正! 1.新建一个串口类( SerialPort类) //Create a serial port f ...
- linux服务器同时运行两个或多个tomcat
第一步:条件:配置好jdk,如果没有配置好请看:https://www.cnblogs.com/weibanggang/p/11460537.html 第二步:下载安装tomcat 下载tomcat到 ...
- win10下更新anaconda和pip源
第一步:更新anaconda源. anaconda的官方源太慢,推荐清华源:https://mirrors.tuna.tsinghua.edu.cn/help/anaconda/ 软件下载也可以在这个 ...
- linux 安装Python3.6
1.安装依赖 yum -y install zlib-devel bzip2-devel openssl-devel ncurses-devel sqlite-devel readline-devel ...
- C# EF框架 频繁连接性能损耗
目的 测试EF框架在一次连接中多次保存和多次连接的耗时对比 测试环境 数据库SqlServer 2012 R2 EF框架6.2.0版本 数据库内容 ID UserName Password Creat ...
- Linux DNS 主从复制
设置主从DNS的主要是为了冗余,分担压力,防止服务器宕机后,DNS无法正常解析. 配置 master 正常配置DNS服务. 设置主机名 [root@localhost ~]# hostnamectl ...
- 关于 Spring AOP (AspectJ) 你该知晓的一切
版权声明:本文为CSDN博主「zejian_」的原创文章,遵循 CC 4.0 BY-SA 版权协议,转载请附上原文出处链接及本声明.原文链接:https://blog.csdn.net/javazej ...
- 【Spring Boot】Spring Boot之自定义拦截器
一.拦截器的作用 将通用的代码抽取出来,达到复用的效果.比如可以用来做日志记录.登录判断.权限校验等等 二.如何实现自定义拦截器 1)创建自定义拦截器类并实现HandlerInterceptor类 / ...
- linux查看磁盘分区
df 查看磁盘分区使用状况 用法:df [选项]... [文件]... Show information about the file system on which each FILE resid ...