
关于SIFT,GIFT在旋转不变性上的对比实验
关于SIFT,GIFT在旋转不变性上的对比实验
这篇文章不讨论SIFT,GIFT的实现原理,只从最终匹配结果的准确度上来进行对比。
回顾
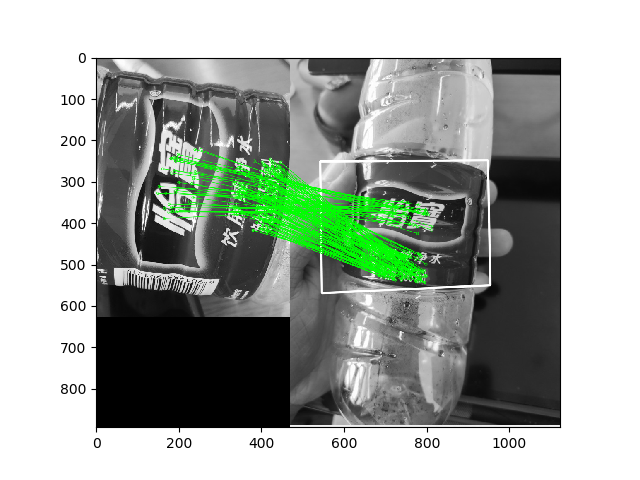
先简单回顾一下,两种方法略有不同。SIFT是检测出各个特征点,并得到特征点描述子。
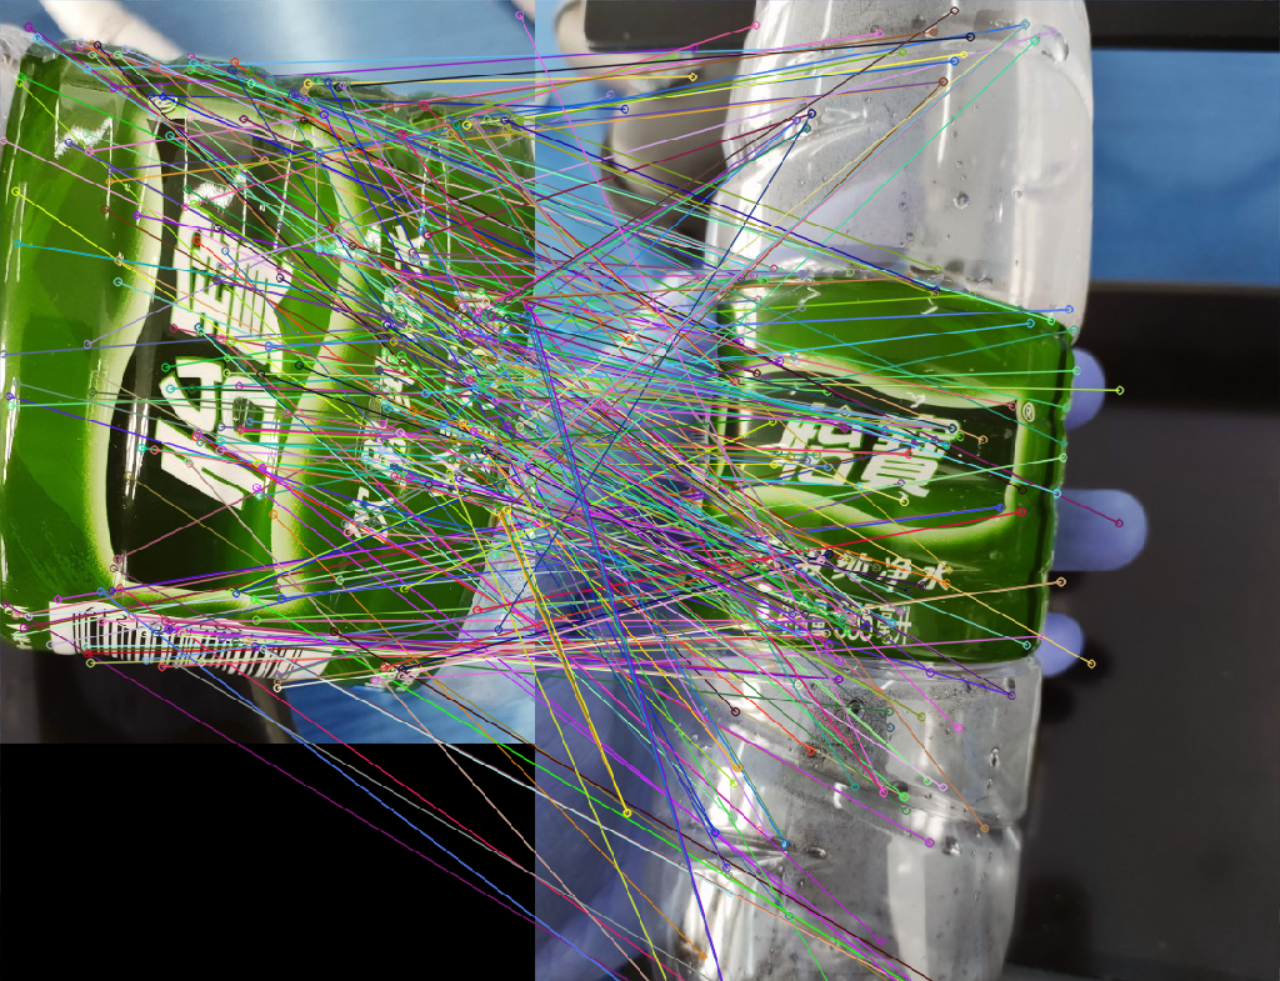
GIFT是先使用其它算法(SIFT,SuperPoint,Harris)等方法得到特征点,然后将原图加检测得到的特征点输入网络得到特征点描述子。
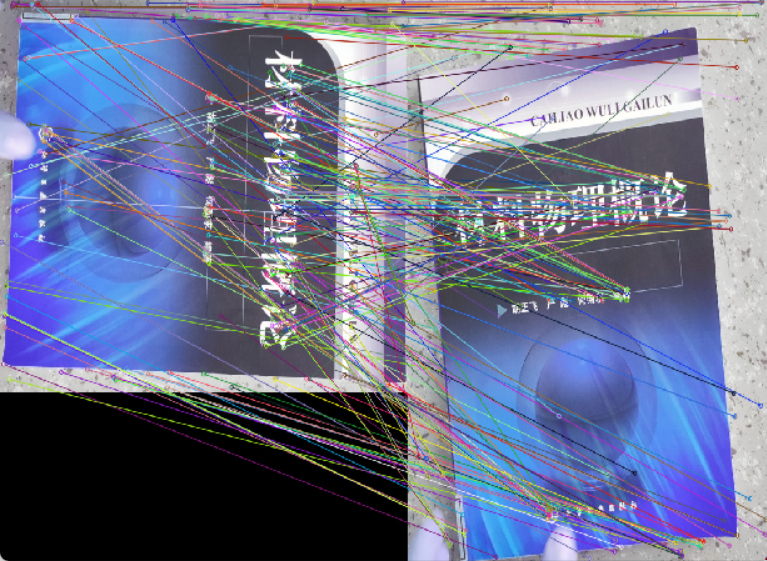
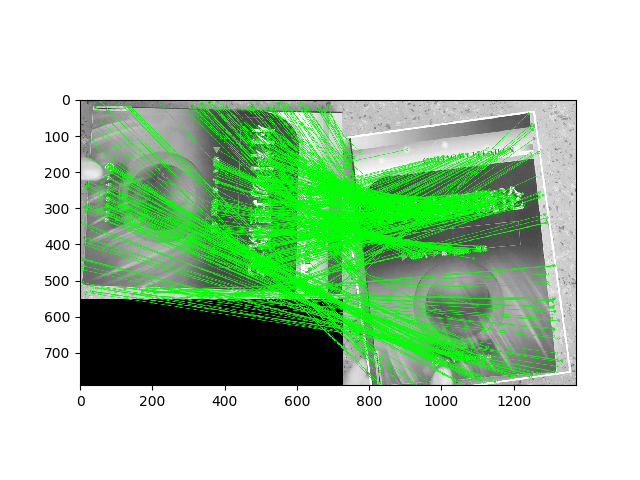
用特征点描述子进行匹配,我们可以得到如下的试验结果:
| 原图1 | 原图2 | GIFT | SIFT |
|---|---|---|---|
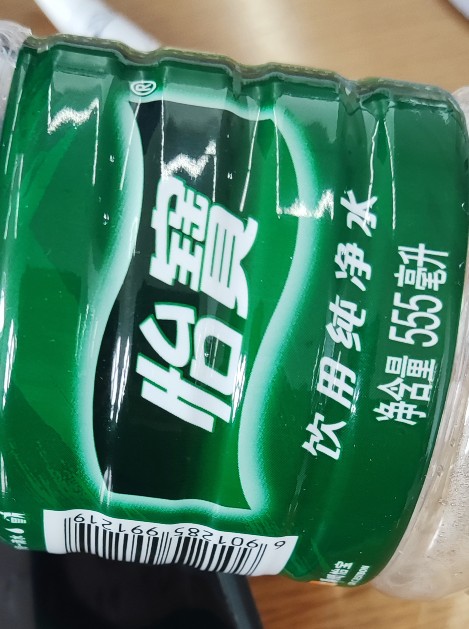 |
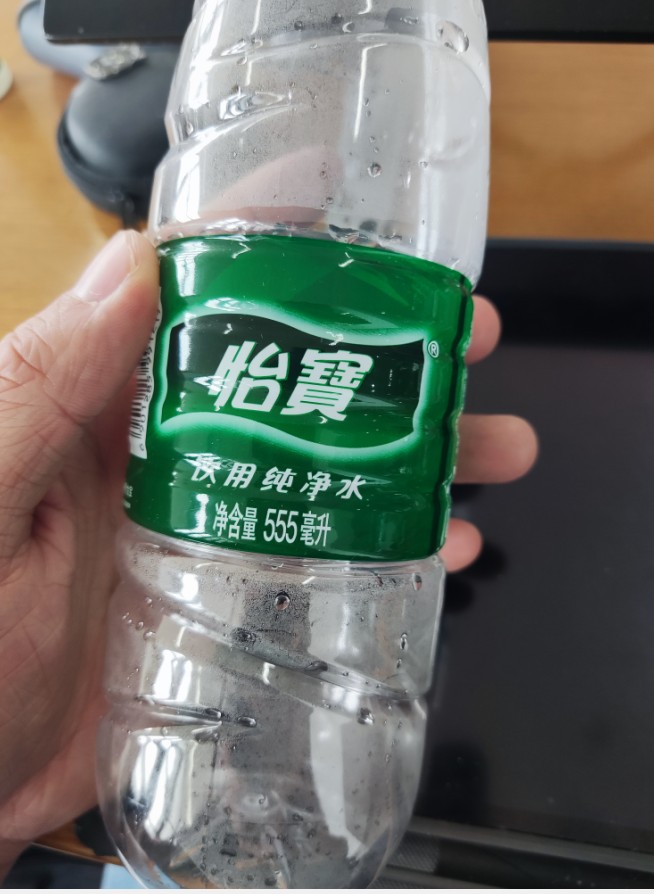 |
 |
 |
 |
 |
 |
 |
准确率测试
但是仔细观察GIFT的匹配结果,肉眼就能看出很多错误的匹配。(SIFT,GIFT都使用的是FLANN)
对此,我设计了一个方法来估算一下二者匹配的准确率,也能侧面反映出描述子的健壮性。
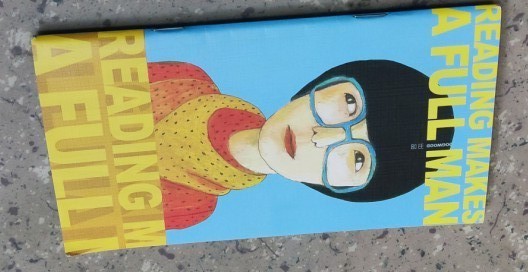
思路:一张图片\(img\),将其旋转90°,得到\(img_{}'\),然后分别使用SIFT,GIFT进行特征点匹配,由于\(ima\)与\(ima_{}'\)的像素点存在一个旋转矩阵的对应关系,我们可以据此来大体估算两种方法的准确率。
实验环境:pycharm, cpu, opencv
- Test1
 |
 |
 |
|---|
我们看一下在这两张图片上的匹配结果:
| SIFT | SIFT points+GIFT | SuperPoint points+GIFT | |
|---|---|---|---|
| 特征点匹配数目 | 5184 | 1506 | 630 |
| 正确匹配数目 | 5038 | 876 | 358 |
| 准确率 | 0.9718 | 0.5817 | 0.5682 |
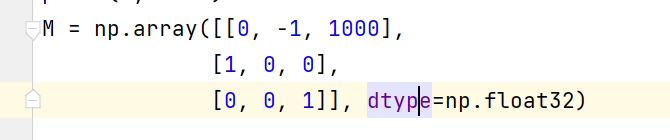
特征点匹配对应的就是附录代码里的good_mathes,正确匹配数目是使用两张图片的旋转矩阵计算而来,也就是,\(img\)里的一个特征点坐标\(p\),对应\(img_{}'\)里的\(p_{}'\), 有$p_{}' = Mp $。详情请查看附录代码。
Test2
| SIFT | SIFT points+GIFT | SuperPoint points+GIFT | |
|---|---|---|---|
| 特征点匹配数目 | 594 | 256 | 216 |
| 正确匹配数目 | 587 | 155 | 127 |
| 准确率 | 0.9882 | 0.6055 | 0.5880 |
总结
虽然GIFT具有一定的旋转不变性,但是效果不是很好,使用特征描述子匹配出的错点比较多,特征描述子的健壮性也不如SIFT通用。
最后要说的是,受限于笔者目前的知识水平和技术水平,不排除在复现GIFT原代码时出现概念性错误,或者是由于粗心导致的细节疏忽。所以此篇文章仅供参考,如果您有新的想法或者建议,欢迎在评论区指出或者发送邮件(lightwxz@foxmail.com)讨论。实验代码请看附录。
核心代码
GIFT_Test.py 代码修改自GIFT论文作者在GitHub发布的demo.ipynb
备注:
- 复现此代码时需要修改test_acc下的M矩阵,因为实验所用的旋转变更了坐标系,因此每张图片的旋转矩阵都是不同的
GIFT_Test.py
import numpy as np

import torch

from skimage.io import imread

from network.wrapper import GIFTDescriptor

from train.evaluation import EvaluationWrapper, Matcher

from utils.superpoint_utils import SuperPointWrapper, SuperPointDescriptor

import matplotlib.pyplot as plt

import cv2

MIN_MATCH_COUNT = 10

def test_acc(good, kps0, kps1):

    # 给特征点末尾添加一列变为其次坐标

    points1 = np.insert(kps0, 2, values=np.ones(kps0.shape[0]), axis=1)

    points2 = np.insert(kps1, 2, values=np.ones(kps1.shape[0]), axis=1)

    # 旋转矩阵

    M = np.array([[0, -1, 528],

                  [1, 0, 0],

                  [0, 0, 1]], dtype=np.float32)

    # 图一是图二旋转 90°得到,因此像素坐标乘以一个旋转矩阵即可

    count = 0

    for i in good:

        pts_after_rotate = M.dot(points1[i.queryIdx].T)

        if (pts_after_rotate - points2[i.trainIdx]).sum() < 3:

            count += 1

    print(len(good))

    print(count)

if __name__ == '__main__':

    detector = SuperPointWrapper(EvaluationWrapper.load_cfg('configs/eval/superpoint_det.yaml'))

    gift_desc = GIFTDescriptor(EvaluationWrapper.load_cfg('configs/eval/gift_pretrain_desc.yaml'))

    superpoint_desc = SuperPointDescriptor(EvaluationWrapper.load_cfg('configs/eval/superpoint_desc.yaml'))

    # matcher = Matcher(EvaluationWrapper.load_cfg('configs/eval/match_v0.yaml'))

    img0 = imread("demo/woman.jpg")

    img1 = imread("demo/woman_ro.jpg")

    # 此处可以通过修改注释来切换检测器

    # to use superpoint detector

    # kps0, _ = detector(img0)

    # kps1, _ = detector(img1)

    # to use SIFT detector

    sift = cv2.SIFT_create()

    kps0, _ = sift.detectAndCompute(img0, None)

    kps1, _ = sift.detectAndCompute(img1, None)

    kps0 = np.array([[i.pt[0], i.pt[1]] for i in kps0])

    kps1 = np.array([[i.pt[0], i.pt[1]] for i in kps1])

    # -----------------------

    # 得到GIFT特征描述子

    des1 = gift_desc(img0, kps0)

    des2 = gift_desc(img1, kps1)

    #描述子匹配

    FLANN_INDEX_KDTREE = 0

    index_params = dict(algorithm=FLANN_INDEX_KDTREE, trees=5)

    search_params = dict(checks=50)

    flann = cv2.FlannBasedMatcher(index_params, search_params)

    matches1 = flann.knnMatch(des1, des2, k=2)

    # matches2 = flann.knnMatch(des2, des1, k=1)

    ratio_thresh = 0.98 # 此处设置为0.7,0.8时就一个都匹配不上了。

    good_matches = []

    for m, n in matches1:

        if m.distance < ratio_thresh * n.distance:

            good_matches.append(m)

    test_acc(good_matches, kps0, kps1)

    kps0 = [cv2.KeyPoint(kps0[i][0], kps0[i][1], 1)

                for i in range(kps0.shape[0])]

    kps1 = [cv2.KeyPoint(kps1[i][0], kps1[i][1], 1)

                     for i in range(kps1.shape[0])]

    img_matches = np.empty(

        (max(img0.shape[0], img1.shape[0]), img0.shape[1] + img1.shape[1], 3),

        dtype=np.uint8)

    cv2.drawMatches(img0, kps0, img1, kps1, good_matches, img_matches,

                    flags=cv2.DrawMatchesFlags_NOT_DRAW_SINGLE_POINTS)

    cv2.namedWindow("Good Matches of GIFT", 0)

    cv2.resizeWindow("Good Matches of GIFT", 1024, 1024)

    cv2.imshow('Good Matches of GIFT', img_matches)

    cv2.waitKey()
SIFT_Test.py
from __future__ import print_function

import cv2 as cv

import numpy as np

pic1 = "data/woman.jpg"

pic2 = "data/woman_ro.jpg"

def test_acc(good, kps0, kps1):

    count = 0

    # 给特征点末尾添加一列变为其次坐标

    points1 = np.insert(kps0, 2, values=np.ones(kps0.shape[0]), axis=1)

    points2 = np.insert(kps1, 2, values=np.ones(kps1.shape[0]), axis=1)

    # 旋转矩阵

    M = np.array([[0, -1, 528],

                  [1, 0, 0],

                  [0, 0, 1]], dtype=np.float32)

    # 图一是图二旋转 90°得到,因此像素坐标乘以一个旋转矩阵即可

    count = 0

    for i in good:

        pts_after_rotate = M.dot(points1[i.queryIdx].T)

        if (pts_after_rotate-points2[i.trainIdx]).sum() < 3:

            count += 1

    print(len(good))

    print(count)

img_object = cv.imread(pic1)

img_scene = cv.imread(pic2)

if img_object is None or img_scene is None:

    print('Could not open or find the images!')

    exit(0)

#-- Step 1: Detect the keypoints using SURF Detector, compute the descriptors

sift = cv.SIFT_create()

keypoints_obj, descriptors_obj = sift.detectAndCompute(img_object,None)

keypoints_scene, descriptors_scene = sift.detectAndCompute(img_scene,None)

#-- Step 2: Matching descriptor vectors with a FLANN based matcher

# Since SURF is a floating-point descriptor NORM_L2 is used

matcher = cv.DescriptorMatcher_create(cv.DescriptorMatcher_FLANNBASED)

knn_matches = matcher.knnMatch(descriptors_obj, descriptors_scene, 2)

#-- Filter matches using the Lowe's ratio test

ratio_thresh = 0.75

good_matches = []

for m,n in knn_matches:

    if m.distance < ratio_thresh * n.distance:

        good_matches.append(m)

print("The number of keypoints in image1 is", len(keypoints_obj))

print("The number of keypoints in image2 is", len(keypoints_scene))

#

kp1 = np.array([[i.pt[0], i.pt[1]] for i in keypoints_obj], dtype=np.int32)

kp2 = np.array([[i.pt[0], i.pt[1]] for i in keypoints_scene], dtype=np.int32)

test_acc(good_matches, kp1, kp2)

#-- Draw matches

img_matches = np.empty((max(img_object.shape[0], img_scene.shape[0]), img_object.shape[1]+img_scene.shape[1], 3), dtype=np.uint8)

cv.drawMatches(img_object, keypoints_obj, img_scene, keypoints_scene, good_matches, img_matches, flags=cv.DrawMatchesFlags_NOT_DRAW_SINGLE_POINTS)

cv.namedWindow("Good Matches of SIFT", 0)

cv.resizeWindow("Good Matches of SIFT", 1024, 1024)

cv.imshow('Good Matches of SIFT', img_matches)

cv.waitKey()
关于SIFT,GIFT在旋转不变性上的对比实验的更多相关文章
- SIFT,SuperPoint在图像特征提取上的对比实验
SIFT,SuperPoint都具有提取图片特征点,并且输出特征描述子的特性,本篇文章从特征点的提取数量,特征点的正确匹配数量来探索一下二者的优劣. 视角变化较大的情况下 原图1 原图2 SuperP ...
- 局部二值模式(Local Binary Patterns)纹理灰度与旋转不变性
Multiresolution Gray Scale and Rotation Invariant Texture Classification with Local Binary Patterns, ...
- CNN对位移、尺度和旋转不变性的讨论
CNN得益于全局共享权值和pool操作,具有平移不变性. 对于尺度不变性,是没有或者说具有一定的不变性(尺度变化不大),实验中小目标的检测是难点,需要采用FPN或者其他的方式单独处理. 对于旋转不变性 ...
- 在阿里云上搭建 Spark 实验平台
在阿里云上搭建 Spark 实验平台 Hadoop2.7.3+Spark2.1.0 完全分布式环境 搭建全过程 [传统文化热爱者] 阿里云服务器搭建spark特别坑的地方 阿里云实现Hadoop+Sp ...
- 记一次burp suite文件上传漏洞实验
一·文件上传漏洞概念 文件上传漏洞是指 Web 服务器允许用户在没有充分验证文件名称.类型.内容或大小等内容的情况下将文件上传到其文件系统.未能正确执行这些限制可能意味着 即使是基本的图像上传功能也可 ...
- LCD驱动移植在在mini2440(linux2.6.29)和FS4412(linux3.14.78)上实现对比(deep dive)
1.Linux帧缓冲子系统 帧缓冲(FrameBuffer)是Linux为显示设备提供的一个接口,用户可以将帧缓冲看成是显示内存的一种映像,将其映射到进程地址空间之后,就可以直接进行读写操作,而写操作 ...
- IIC驱动移植在linux3.14.78上的实现和在linux2.6.29上实现对比(deep dive)
首先说明下为什么写这篇文章,网上有许多博客也是介绍I2C驱动在linux上移植的实现,但是笔者认为他们相当一部分没有分清所写的驱动时的驱动模型,是基于device tree, 还是基于传统的Platf ...
- Suspend to RAM和Suspend to Idle分析,以及在HiKey上性能对比
Linux内核suspend状态 Linux内核支持多种类型的睡眠状态,通过设置不同的模块进入低功耗模式来达到省电功能.目前存在四种模式:suspend to idle.power-on standb ...
- 中英文维基百科语料上的Word2Vec实验
最近试了一下Word2Vec, GloVe 以及对应的python版本 gensim word2vec 和 python-glove,就有心在一个更大规模的语料上测试一下,自然而然维基百科的语料进入了 ...
- 在Spark上用Scala实验梯度下降算法
首先参考的是这篇文章:http://blog.csdn.net/sadfasdgaaaasdfa/article/details/45970185 但是其中的函数太老了.所以要改.另外出发点是我自己的 ...
随机推荐
- 使用Ollama
推荐 Ollama 本地运行大模型(LLM)完全指南 Ollama中文学习 应用 查看可支持的模型:https://ollama.com/library 查看运行中的模型 ollama ps 停止模型 ...
- LeetCode 第3题:无重复字符的最长子串
LeetCode 第3题:无重复字符的最长子串 题目描述 给定一个字符串 s ,请你找出其中不含有重复字符的最长子串的长度. 难度 中等 题目链接 https://leetcode.cn/proble ...
- Jenkins插件:Publish over SSH
Jenkins插件:Publish over SSH Jenkins作为一个开源的持续集成和交付工具,通过插件扩展可以实现各种功能.其中,Publish over SSH插件是Jenkins的一个常用 ...
- MySQL主从复制-原理实战
一.原理 主从复制架构图:主从复制原理: Mysql 中有一种日志叫做 bin 日志(二进制日志).这个日志会记录下所有修改了数据库的SQL 语句(insert,update,delete,creat ...
- Project Euler 728 题解
Problem 728 Circle of Coins 得到 Wallbreaker5th 的指导. \(F\) 就是求这些环上区间(记为 \(A\))的异或线性基大小.令 \(A'_i\gets A ...
- Hive源码解析环境搭建
一.准备工作 1.1 下载地址 https://github.com/apache/hive https://dlcdn.apache.org/hive/ 版本:2.3.9 1.2 环境依赖 had ...
- Luogu P4310 绝世好题 题解 [ 绿 ] [ 线性 dp ] [ 单调队列优化 ] [ 二进制优化 ]
题目:绝世好题. 暴力 dp 显然 \(O(n^2)\) 转移即可. 单调队列优化 观察到只有某二进制位两个数都为 \(1\) 时才能转移,因此我们把每个二进制位开一个单调队列,然后对于一个数 \(a ...
- getDerivedStateFromProps 详解
getDerivedStateFromProps 是 React 生命周期中的一个静态方法,主要用于在组件接收到新的 props 时更新 state.这个方法在组件的初始渲染和后续的每次更新(即每次接 ...
- el-radio-group之迷惑操作:label和label
el-radio-group之迷惑操作:label和label 今天学习element-ui的el-radio-group的时候发现el-radio-group的默认值设置无效,但是点击其他单选框可以 ...
- DeepSeek-R1的“思考”艺术,你真的了解吗?
大家好~,这里是AI粉嫩特攻队!今天咱们来聊聊一个有趣的话题--DeepSeek-R1到底什么时候会"思考",什么时候又会选择"偷懒"? 最近有朋友问我:&qu ...