
Cartographer源码阅读(5):PoseGraph位姿图
PoseGraph位姿图
mapping2D::PoseGraph类的注释:
|
// Implements the loop closure method called Sparse Pose Adjustment (SPA) from |
1.继承关系mapping,mapping2D,mapping3D (以前叫sparse_pose_graph.h,目前名称被修改了)
类中一个很重要的类OptimizationProblem对象optimization_problem_,该类的注释是Implements the SPA loop closure method.即实现了SPA方法的闭环。
类的主要成员变量和成员函数如类图所示,其中重要的方法PoseGraph::RunOptimization()。
pose_graph::OptimizationProblem optimization_problem_;
pose_graph::ConstraintBuilder constraint_builder_ GUARDED_BY(mutex_);
std::vector<Constraint> constraints_ GUARDED_BY(mutex_);
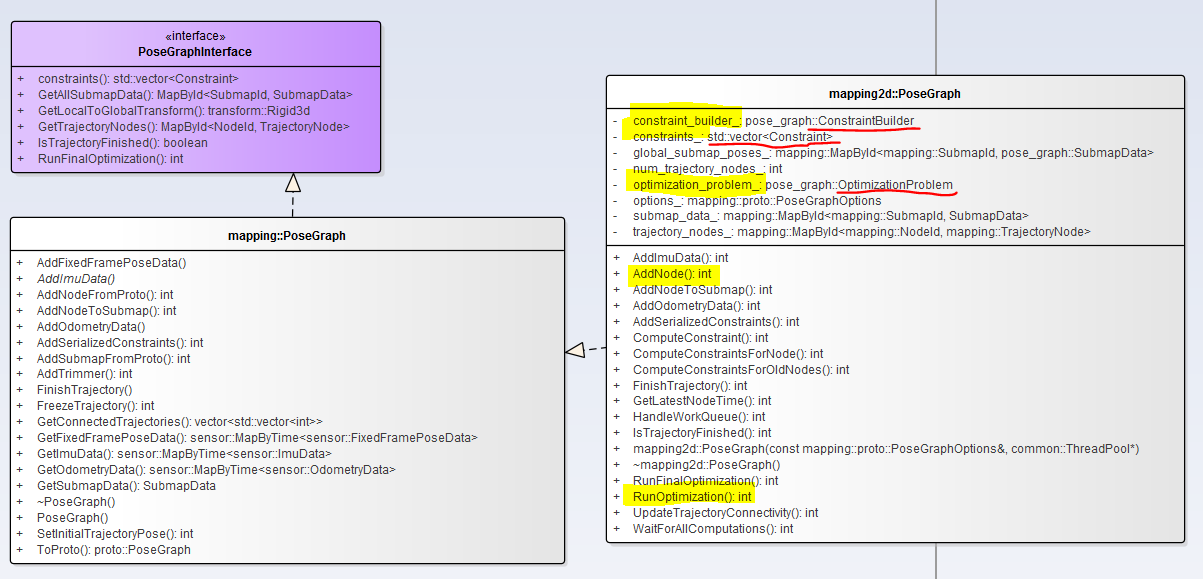
接上一篇在PoseGraph::AddNode方法中调用了 AddTrajectoryIfNeeded() 和 PoseGraph::ComputeConstraintsForNode()方法。
 void PoseGraph::ComputeConstraintsForNode(

     const mapping::NodeId& node_id,

     std::vector<std::shared_ptr<const Submap>> insertion_submaps,

     const bool newly_finished_submap) {

   const auto& constant_data = trajectory_nodes_.at(node_id).constant_data;

   const std::vector<mapping::SubmapId> submap_ids = InitializeGlobalSubmapPoses(

       node_id.trajectory_id, constant_data->time, insertion_submaps);

   CHECK_EQ(submap_ids.size(), insertion_submaps.size());

   const mapping::SubmapId matching_id = submap_ids.front();

   const transform::Rigid2d pose = transform::Project2D(

       constant_data->local_pose *

       transform::Rigid3d::Rotation(constant_data->gravity_alignment.inverse()));

   const transform::Rigid2d optimized_pose =

       optimization_problem_.submap_data().at(matching_id).global_pose *

       pose_graph::ComputeSubmapPose(*insertion_submaps.front()).inverse() *

       pose;

   optimization_problem_.AddTrajectoryNode(

       matching_id.trajectory_id, constant_data->time, pose, optimized_pose,

       constant_data->gravity_alignment);

   for (size_t i = ; i < insertion_submaps.size(); ++i) {

     const mapping::SubmapId submap_id = submap_ids[i];

     // Even if this was the last node added to 'submap_id', the submap will only

     // be marked as finished in 'submap_data_' further below.

     CHECK(submap_data_.at(submap_id).state == SubmapState::kActive);

     submap_data_.at(submap_id).node_ids.emplace(node_id);

     const transform::Rigid2d constraint_transform =

         pose_graph::ComputeSubmapPose(*insertion_submaps[i]).inverse() * pose;

     constraints_.push_back(Constraint{submap_id,

                                       node_id,

                                       {transform::Embed3D(constraint_transform),

                                        options_.matcher_translation_weight(),

                                        options_.matcher_rotation_weight()},

                                       Constraint::INTRA_SUBMAP});

   }

   for (const auto& submap_id_data : submap_data_) {

     if (submap_id_data.data.state == SubmapState::kFinished) {

       CHECK_EQ(submap_id_data.data.node_ids.count(node_id), );

       ComputeConstraint(node_id, submap_id_data.id);

     }

   }

   if (newly_finished_submap) {

     const mapping::SubmapId finished_submap_id = submap_ids.front();

     SubmapData& finished_submap_data = submap_data_.at(finished_submap_id);

     CHECK(finished_submap_data.state == SubmapState::kActive);

     finished_submap_data.state = SubmapState::kFinished;

     // We have a new completed submap, so we look into adding constraints for

     // old nodes.

     ComputeConstraintsForOldNodes(finished_submap_id);

   }

   constraint_builder_.NotifyEndOfNode();

   ++num_nodes_since_last_loop_closure_;

   if (options_.optimize_every_n_nodes() >  &&

       num_nodes_since_last_loop_closure_ > options_.optimize_every_n_nodes()) {

     CHECK(!run_loop_closure_);

     run_loop_closure_ = true;

     // If there is a 'work_queue_' already, some other thread will take care.

     if (work_queue_ == nullptr) {

       work_queue_ = common::make_unique<std::deque<std::function<void()>>>();

       HandleWorkQueue();

     }

   }

 }
可以看到对本类中ComputeConstraint、ComputeConstraintsForOldNodes、HandleWorkQueue方法的调用。这里有个pose_graph::ComputeSubmapPose方法在cartographer/mapping_2d/pose_graph/constraint_builder.h文件中。子图submap位姿?
transform::Rigid2d ComputeSubmapPose(const Submap& submap)

{

      return transform::Project2D(submap.local_pose());

}
注意HandleWorkQueue()方法中调用了RunOptimization方法。
 void PoseGraph::HandleWorkQueue() {

   constraint_builder_.WhenDone(

       [this](const pose_graph::ConstraintBuilder::Result& result) {

         {

           common::MutexLocker locker(&mutex_);

           constraints_.insert(constraints_.end(), result.begin(), result.end());

         }

         RunOptimization();

         common::MutexLocker locker(&mutex_);

         for (const Constraint& constraint : result) {

           UpdateTrajectoryConnectivity(constraint);

         }

         TrimmingHandle trimming_handle(this);

         for (auto& trimmer : trimmers_) {

           trimmer->Trim(&trimming_handle);

         }

         trimmers_.erase(

             std::remove_if(

                 trimmers_.begin(), trimmers_.end(),

                 [](std::unique_ptr<mapping::PoseGraphTrimmer>& trimmer) {

                   return trimmer->IsFinished();

                 }),

             trimmers_.end());

         num_nodes_since_last_loop_closure_ = ;

         run_loop_closure_ = false;

         while (!run_loop_closure_) {

           if (work_queue_->empty()) {

             work_queue_.reset();

             return;

           }

           work_queue_->front()();

           work_queue_->pop_front();

         }

         LOG(INFO) << "Remaining work items in queue: " << work_queue_->size();

         // We have to optimize again.

         HandleWorkQueue();

       });

 }
PoseGraph::HandleWorkQueue
查看PoseGraph::RunOptimization方法,
 void PoseGraph::RunOptimization()

 {

   if (optimization_problem_.submap_data().empty())

   {

     return;

   }

   // No other thread is accessing the optimization_problem_, constraints_ and

   // frozen_trajectories_ when executing the Solve. Solve is time consuming, so

   // not taking the mutex before Solve to avoid blocking foreground processing.

   optimization_problem_.Solve(constraints_, frozen_trajectories_);

   common::MutexLocker locker(&mutex_);

   const auto& submap_data = optimization_problem_.submap_data();

   const auto& node_data = optimization_problem_.node_data();

   for (const int trajectory_id : node_data.trajectory_ids())

   {

     for (const auto& node : node_data.trajectory(trajectory_id))

     {

       auto& mutable_trajectory_node = trajectory_nodes_.at(node.id);

       mutable_trajectory_node.global_pose =

           transform::Embed3D(node.data.pose) *

           transform::Rigid3d::Rotation(mutable_trajectory_node.constant_data->gravity_alignment);

     }

     // Extrapolate all point cloud poses that were not included in the

     // 'optimization_problem_' yet.

     const auto local_to_new_global =

         ComputeLocalToGlobalTransform(submap_data, trajectory_id);

     const auto local_to_old_global =

         ComputeLocalToGlobalTransform(global_submap_poses_, trajectory_id);

     const transform::Rigid3d old_global_to_new_global =

         local_to_new_global * local_to_old_global.inverse();

     const mapping::NodeId last_optimized_node_id =

         std::prev(node_data.EndOfTrajectory(trajectory_id))->id;

     auto node_it = std::next(trajectory_nodes_.find(last_optimized_node_id));

     for (; node_it != trajectory_nodes_.EndOfTrajectory(trajectory_id); ++node_it)

     {

       auto& mutable_trajectory_node = trajectory_nodes_.at(node_it->id);

       mutable_trajectory_node.global_pose =

           old_global_to_new_global * mutable_trajectory_node.global_pose;

     }

   }

   global_submap_poses_ = submap_data;

 }
查看Constraint 结构体,该结构体在PoseGraphInterface中定义。
   // A "constraint" as in the paper by Konolige, Kurt, et al. "Efficient sparse

   // pose adjustment for 2d mapping." Intelligent Robots and Systems (IROS),

   // 2010 IEEE/RSJ International Conference on (pp. 22--29). IEEE, 2010.

   struct Constraint {

     struct Pose {

       transform::Rigid3d zbar_ij;

       double translation_weight;

       double rotation_weight;

     };

     SubmapId submap_id;  // 'i' in the paper.

     NodeId node_id;      // 'j' in the paper.

     // Pose of the node 'j' relative to submap 'i'.

     Pose pose;

     // Differentiates between intra-submap (where node 'j' was inserted into

     // submap 'i') and inter-submap constraints (where node 'j' was not inserted

     // into submap 'i').

     enum Tag { INTRA_SUBMAP, INTER_SUBMAP } tag;

   };
Cartographer源码阅读(5):PoseGraph位姿图的更多相关文章
- Cartographer源码阅读(9):图优化的前端——闭环检测
约束计算 闭环检测的策略:搜索闭环,通过匹配检测是否是闭环,采用了分支定界法. 前已经述及PoseGraph的内容,此处继续.位姿图类定义了pose_graph::ConstraintBuilder ...
- Cartographer源码阅读(7):轨迹推算和位姿推算的原理
其实也就是包括两个方面的内容:类似于运动模型的位姿估计和扫描匹配,因为需要计算速度,所以时间就有必要了! 1. PoseExtrapolator解决了IMU数据.里程计和位姿信息进行融合的问题. 该类 ...
- Cartographer源码阅读(6):LocalTrajectoryBuilder和PoseExtrapolator
LocalTrajectoryBuilder意思是局部轨迹的构建,下面的类图中方法的参数没有画进去. 注意其中的三个类:PoseExtrapolator类,RealTimeCorrelativeSca ...
- Cartographer源码阅读(4):Node和MapBuilder对象2
MapBuilder的成员变量sensor::Collator sensor_collator_; 再次阅读MapBuilder::AddTrajectoryBuilder方法.首先构造了mappin ...
- Cartographer源码阅读(3):程序逻辑结构
Cartographer早期的代码在进行3d制图的时候使用了UKF方法,查看现有的tag版本,可以转到0.1.0和0.2.0查看,包含kalman_filter文件夹. 文件夹中的pose_track ...
- Cartographer源码阅读(2):Node和MapBuilder对象
上文提到特别注意map_builder_bridge_.AddTrajectory(x,x),查看其中的代码.两点: 首先是map_builder_.AddTrajectoryBuilder(...) ...
- Cartographer源码阅读(1):程序入口
带着几个思考问题: (1)IMU数据的使用,如何融合,Kalman滤波? (2)图优化的具体实现,闭环检测的策略? (3)3D激光的接入和闭环策略? 1. 安装Kdevelop工具: http://b ...
- Cartographer源码阅读(8):imu_tracker
IMU的输入为imu_linear_acceleration 和 imu_angular_velocity 线加速和角速度.最终作为属性输出的是方位四元数. Eigen::Quaterniond ...
- 【原】AFNetworking源码阅读(六)
[原]AFNetworking源码阅读(六) 本文转载请注明出处 —— polobymulberry-博客园 1. 前言 这一篇的想讲的,一个就是分析一下AFSecurityPolicy文件,看看AF ...
随机推荐
- CentOS 7 安装GitLab
CentOS 安装GitLab CentOS 安装GitLab GitLab是一个利用Ruby on Rails开发的开源应用程序,实现一个自托管的Git项目仓库,可通过Web界面进行访问公开的或者私 ...
- [Java并发编程(四)] Java volatile 的理论实践
[Java并发编程(四)] Java volatile 的理论实践 摘要 Java 语言中的 volatile 变量可以被看作是一种 "程度较轻的 synchronized":与 ...
- 看雪CTF第十四题
from z3 import * dest=[] s = Solver() data = [, , , , , , , , , , , , , , , , , , , , , , , , , , , ...
- 【转】WPF自定义控件与样式(11)-等待/忙/正在加载状态-控件实现
一.前言 申明:WPF自定义控件与样式是一个系列文章,前后是有些关联的,但大多是按照由简到繁的顺序逐步发布的等. 本文主要有三种实现方式: 简单忙碌状态控件BusyBox: Win8/win10效果忙 ...
- MySql快速插入以及批量更新
MySql快速插入以及批量更新 插入: MySql提供了可以一次插入多条数据的用法: [sql] INSERT INTO tbl_name (a,b,c) VALUES(1,2,3),(4,5,6), ...
- Ubuntu下安装open-falcon-v0.2.1
在Ubuntu下安装open-falcon和Centos下安装的方法有点区别,因为Ubuntu使用的包管理器是apt-get,而Centos下使用的是Yum,建议不要再Ubuntu下使用yum 建议自 ...
- phpmyadmin 上传超过50m限制
sql文件太大(达到400m),导致无法正常导入.需要修改php,nginx的配置文件 php.ini配置 post_max_size = 500M upload_max_filesize = 500 ...
- 解决importerror no module named mysqldb
在window中 1:在Scripts文件夹下会出现一系列和pip有关的文件,DOS中到Scripts,运行:pip install mysql-python 2:报错:Microsoft Visua ...
- 【hbase】Unable to read additional data from client sessionid 0x15c92bd1fca0003, likely client has closed socket
启动hbase ,验证出错 Master is initializing 查看zk日志,发现Unable to read additional data from client sessionid 0 ...
- c# httpclient
using Newtonsoft.Json; using System; using System.Collections.Generic; using System.IO; using System ...