
[python] RRT快速拓展随机树
"""

version1.1,2018-05-09

《基于智能优化与RRT算法的无人机任务规划方法研究》博士论文

《基于改进人工势场法的路径规划算法研究》硕士论文

"""

import matplotlib.pyplot as plt

import random

import math

import copy

show_animation = True

class Node(object):

    """

    RRT Node

    """

    def __init__(self, x, y):

        self.x = x

        self.y = y

        self.parent = None

class RRT(object):

    """

    Class for RRT Planning

    """

    def __init__(self, start, goal, obstacle_list, rand_area):

        """

        Setting Parameter

        start:Start Position [x,y]

        goal:Goal Position [x,y]

        obstacleList:obstacle Positions [[x,y,size],...]

        randArea:random sampling Area [min,max]

        """

        self.start = Node(start[0], start[1])

        self.end = Node(goal[0], goal[1])

        self.min_rand = rand_area[0]

        self.max_rand = rand_area[1]

        self.expandDis = 1.0

        self.goalSampleRate = 0.05  # 选择终点的概率是0.05

        self.maxIter = 500

        self.obstacleList = obstacle_list

        self.nodeList = [self.start]

    def random_node(self):

        """

        产生随机节点

        :return:

        """

        node_x = random.uniform(self.min_rand, self.max_rand)

        node_y = random.uniform(self.min_rand, self.max_rand)

        node = [node_x, node_y]

        return node

    @staticmethod

    def get_nearest_list_index(node_list, rnd):

        """

        :param node_list:

        :param rnd:

        :return:

        """

        d_list = [(node.x - rnd[0]) ** 2 + (node.y - rnd[1]) ** 2 for node in node_list]

        min_index = d_list.index(min(d_list))

        return min_index

    @staticmethod

    def collision_check(new_node, obstacle_list):

        a = 1

        for (ox, oy, size) in obstacle_list:

            dx = ox - new_node.x

            dy = oy - new_node.y

            d = math.sqrt(dx * dx + dy * dy)

            if d <= size:

                a = 0  # collision

        return a  # safe

    def planning(self):

        """

        Path planning

        animation: flag for animation on or off

        """

        while True:

            # Random Sampling

            if random.random() > self.goalSampleRate:

                rnd = self.random_node()

            else:

                rnd = [self.end.x, self.end.y]

            # Find nearest node

            min_index = self.get_nearest_list_index(self.nodeList, rnd)

            # print(min_index)

            # expand tree

            nearest_node = self.nodeList[min_index]

            # 返回弧度制

            theta = math.atan2(rnd[1] - nearest_node.y, rnd[0] - nearest_node.x)

            new_node = copy.deepcopy(nearest_node)

            new_node.x += self.expandDis * math.cos(theta)

            new_node.y += self.expandDis * math.sin(theta)

            new_node.parent = min_index

            if not self.collision_check(new_node, self.obstacleList):

                continue

            self.nodeList.append(new_node)

            # check goal

            dx = new_node.x - self.end.x

            dy = new_node.y - self.end.y

            d = math.sqrt(dx * dx + dy * dy)

            if d <= self.expandDis:

                print("Goal!!")

                break

            if True:

                self.draw_graph(rnd)

        path = [[self.end.x, self.end.y]]

        last_index = len(self.nodeList) - 1

        while self.nodeList[last_index].parent is not None:

            node = self.nodeList[last_index]

            path.append([node.x, node.y])

            last_index = node.parent

        path.append([self.start.x, self.start.y])

        return path

    def draw_graph(self, rnd=None):

        """

        Draw Graph

        """

        print('aaa')

        plt.clf()  # 清除上次画的图

        if rnd is not None:

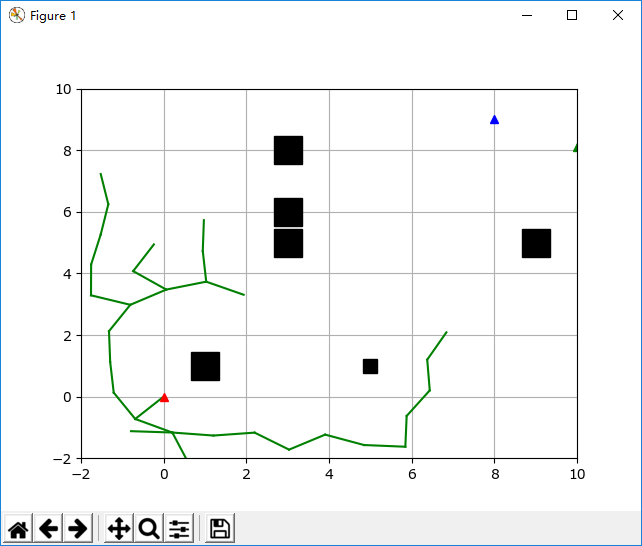
            plt.plot(rnd[0], rnd[1], "^g")

        for node in self.nodeList:

            if node.parent is not None:

                plt.plot([node.x, self.nodeList[node.parent].x], [

                         node.y, self.nodeList[node.parent].y], "-g")

        for (ox, oy, size) in self.obstacleList:

            plt.plot(ox, oy, "sk", ms=10*size)

        plt.plot(self.start.x, self.start.y, "^r")

        plt.plot(self.end.x, self.end.y, "^b")

        plt.axis([self.min_rand, self.max_rand, self.min_rand, self.max_rand])

        plt.grid(True)

        plt.pause(0.01)

    def draw_static(self, path):

        """

        画出静态图像

        :return:

        """

        plt.clf()  # 清除上次画的图

        for node in self.nodeList:

            if node.parent is not None:

                plt.plot([node.x, self.nodeList[node.parent].x], [

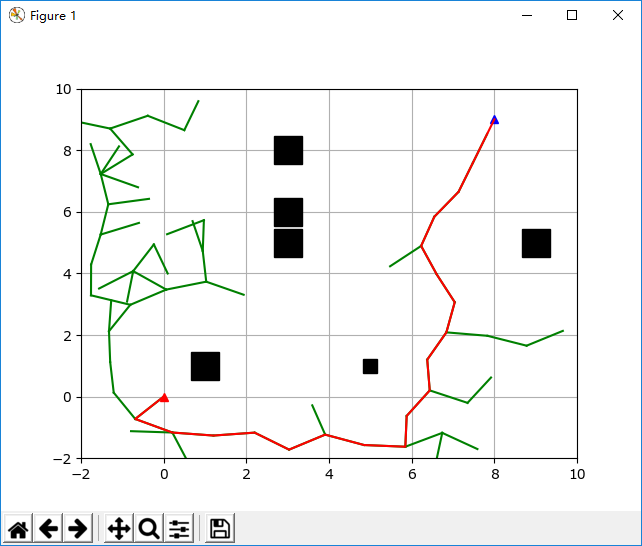
                    node.y, self.nodeList[node.parent].y], "-g")

        for (ox, oy, size) in self.obstacleList:

            plt.plot(ox, oy, "sk", ms=10*size)

        plt.plot(self.start.x, self.start.y, "^r")

        plt.plot(self.end.x, self.end.y, "^b")

        plt.axis([self.min_rand, self.max_rand, self.min_rand, self.max_rand])

        plt.plot([data[0] for data in path], [data[1] for data in path], '-r')

        plt.grid(True)

        plt.show()

def main():

    print("start RRT path planning")

    obstacle_list = [

        (5, 1, 1),

        (3, 6, 2),

        (3, 8, 2),

        (1, 1, 2),

        (3, 5, 2),

        (9, 5, 2)]

    # Set Initial parameters

    rrt = RRT(start=[0, 0], goal=[8, 9], rand_area=[-2, 10], obstacle_list=obstacle_list)

    path = rrt.planning()

    print(path)

    # Draw final path

    if show_animation:

        plt.close()

        rrt.draw_static(path)

if __name__ == '__main__':

    main()
RRT快速拓展随机树 python实现
[python] RRT快速拓展随机树的更多相关文章
- matlab练习程序(快速搜索随机树RRT)
RRT快速搜索随机树英文全称Rapid-exploration Random Tree,和PRM类似,也是一种路径规划算法. 和PRM类似,算法也需要随机撒点,不过不同的是,该算法不是全局随机撒点,而 ...
- [matlab] 7.快速搜索随机树(RRT---Rapidly-exploring Random Trees) 路径规划
RRT是一种多维空间中有效率的规划方法.它以一个初始点作为根节点,通过随机采样增加叶子节点的方式,生成一个随机扩展树,当随机树中的叶子节点包含了目标点或进入了目标区域,便可以在随机树中找到一条由从初始 ...
- LSH︱python实现局部敏感随机投影森林——LSHForest/sklearn(一)
关于局部敏感哈希算法.之前用R语言实现过,可是由于在R中效能太低.于是放弃用LSH来做类似性检索.学了python发现非常多模块都能实现,并且通过随机投影森林让查询数据更快.觉得能够试试大规模应用在数 ...
- (数据科学学习手札114)Python+Dash快速web应用开发——上传下载篇
本文示例代码已上传至我的Github仓库https://github.com/CNFeffery/DataScienceStudyNotes 1 简介 这是我的系列教程Python+Dash快速web ...
- P3830 [SHOI2012]随机树 题解
P3830 随机树 坑题,别人的题解我看了一个下午没一个看得懂的,我还是太弱了. 题目链接 P3830 [SHOI2012]随机树 题目描述 输入输出格式 输入格式: 输入仅有一行,包含两个正整数 q ...
- (数据科学学习手札102)Python+Dash快速web应用开发——基础概念篇
本文示例代码与数据已上传至我的Github仓库https://github.com/CNFeffery/DataScienceStudyNotes 1 简介 这是我的新系列教程Python+Dash快 ...
- (数据科学学习手札103)Python+Dash快速web应用开发——页面布局篇
本文示例代码已上传至我的Github仓库https://github.com/CNFeffery/DataScienceStudyNotes 1 简介 这是我的系列教程Python+Dash快速web ...
- (数据科学学习手札104)Python+Dash快速web应用开发——回调交互篇(上)
本文示例代码已上传至我的Github仓库https://github.com/CNFeffery/DataScienceStudyNotes 1 简介 这是我的系列教程Python+Dash快速web ...
- (数据科学学习手札109)Python+Dash快速web应用开发——静态部件篇(中)
本文示例代码已上传至我的Github仓库https://github.com/CNFeffery/DataScienceStudyNotes 1 简介 这是我的系列教程Python+Dash快速web ...
随机推荐
- Java实现Base64加密
阅读本文约“2.5分钟” Java加解密系列,介绍Java加密解密的基础知识,并使用Base64算法实现加解密. 对于加密在企业中是非常常见的,就如邮件的传输,每个企业都会有自己设置安全方式,设置加密 ...
- Netty实战八之引导
通过前面的学习,我们可能要考虑一个问题:如何将这些部分组织起来,成为一个可实际运行的应用程序呢? 答案是引导.简单来说,引导一个应用程序是指对它进行配置,并使它运行起来的过程——尽管该过程的具体细节可 ...
- 设计模式之原型模式——Java语言描述
原型模式是用于创建重复对象,同时又能保证性能.这种类型的设计模式属于创建型模式,它提供了一种创建对象的方式 这种模式实现了一个原型接口,该接口用于创建当前对象的克隆.当直接创建对象的代价比较大时,则适 ...
- Web Worker 初探
什么是Web Worker? Web Worker 是Html5 提出的能够在后台运行javascript的对象,独立于其他脚本,不会影响页面的性能,也不会影响你继续对于页面进行操作.通俗点讲,就是后 ...
- javascript中call()、apply()的区别
call().apply()的区别: 相同点: 1.call()和apply()都可以用来间接调用函数,都可以显式调用所需的this.即,锚点滑动任何函数可以作为任何对象的方法来调用. 2.两个方法都 ...
- gulp简介
简介 gulp是基于Nodejs的自动任务运行器, 她能自动化地完成 javascript/coffee/sass/less/html/image/css 等文件的的测试.检查.合并.压缩.格式化.浏 ...
- BZOJ 1022: [SHOI2008]小约翰的游戏John (Anti-nim)
Time Limit: 1 Sec Memory Limit: 162 MBSubmit: 3134 Solved: 2003[Submit][Status][Discuss] Descripti ...
- Mobius反演的套路
T1 \(\sum_{i=1}^N \sum_{j=1}^M [(i,j)=1]\) \(f(d)=\sum_{i=1}^N \sum_{j=1}^M [(i,j)=d]\) \(g(d)=\sum_ ...
- RobotFramework RobotFramework官方demo Quick Start Guide浅析
RobotFramework官方demo Quick Start Guide浅析 by:授客 QQ:1033553122 博客:http://blog.sina.com.cn/ishouk ...
- 「Android」系统架构概述
目录: 1.Android系统架构 2.Android类库 3.四大组件 --------------------------------------------------------------- ...