
寻找Harris、Shi-Tomasi和亚像素角点
Harris、Shi-Tomasi和亚像素角点都是角点,隶属于特征点这个大类(特征点可以分为边缘、角点、斑点).
| void cv::cornerHarris | ( | InputArray | src, //需要为8位单通道 |
| OutputArray | dst, //结果 | ||
| int | blockSize, //领域大小 | ||
| int | ksize, //Sobel孔径大小 | ||
| double | k, //Harris参数 | ||
| int | borderType = BORDER_DEFAULT |
||
| ) |
Harris corner detector.
The function runs the Harris corner detector on the image. Similarly to cornerMinEigenVal and cornerEigenValsAndVecs , for each pixel (x, y) it calculates a 2\times2 gradient covariance matrix M^{(x,y)} over a \texttt{blockSize} \times \texttt{blockSize} neighborhood. Then, it computes the following characteristic:
 (特征点计算方法)
Corners in the image can be found as the local maxima of this response map.
- Parameters
-
src Input single-channel 8-bit or floating-point image. dst Image to store the Harris detector responses. It has the type CV_32FC1 and the same size as src . blockSize Neighborhood size (see the details on cornerEigenValsAndVecs ). ksize Aperture parameter for the Sobel operator. k Harris detector free parameter. See the formula below. borderType Pixel extrapolation method. See cv::BorderTypes.
.,,THRESH_BINARY);
imshow();

| void cv::goodFeaturesToTrack | ( | InputArray | image,//输入图像 |
| OutputArray | corners,//输出向量 | ||
| int | maxCorners,//角点最大数量 | ||
| double | qualityLevel,//角点检测可接受的最小特征值 | ||
| double | minDistance,//角点之间的最小距离 | ||
| InputArray | mask = noArray(),//感兴趣区域 |
||
| int | blockSize = 3,//领域范围 |
||
| bool | useHarrisDetector = false,//true为harris;false为Shi-Tomasi |
||
| double | k = 0.04 //权重系数 |
||
| ) |
Determines strong corners on an image.
The function finds the most prominent corners in the image or in the specified image region, as described in [154]
- Function calculates the corner quality measure at every source image pixel using the cornerMinEigenVal or cornerHarris .
- Function performs a non-maximum suppression (the local maximums in 3 x 3 neighborhood are retained).
- The corners with the minimal eigenvalue less than qualityLevel⋅maxx,yqualityMeasureMap(x,y) are rejected.
- The remaining corners are sorted by the quality measure in the descending order.
- Function throws away each corner for which there is a stronger corner at a distance less than maxDistance.
The function can be used to initialize a point-based tracker of an object.
- Note
- If the function is called with different values A and B of the parameter qualityLevel , and A > B, the vector of returned corners with qualityLevel=A will be the prefix of the output vector with qualityLevel=B .
- Parameters
-
image Input 8-bit or floating-point 32-bit, single-channel image. corners Output vector of detected corners. maxCorners Maximum number of corners to return. If there are more corners than are found, the strongest of them is returned. maxCorners <= 0implies that no limit on the maximum is set and all detected corners are returned.qualityLevel Parameter characterizing the minimal accepted quality of image corners. The parameter value is multiplied by the best corner quality measure, which is the minimal eigenvalue (see cornerMinEigenVal ) or the Harris function response (see cornerHarris ). The corners with the quality measure less than the product are rejected. For example, if the best corner has the quality measure = 1500, and the qualityLevel=0.01 , then all the corners with the quality measure less than 15 are rejected. minDistance Minimum possible Euclidean distance between the returned corners. mask Optional region of interest. If the image is not empty (it needs to have the type CV_8UC1 and the same size as image ), it specifies the region in which the corners are detected. blockSize Size of an average block for computing a derivative covariation matrix over each pixel neighborhood. See cornerEigenValsAndVecs . useHarrisDetector Parameter indicating whether to use a Harris detector (see cornerHarris) or cornerMinEigenVal. k Free parameter of the Harris detector.
;i,Scalar());
}
imshow();

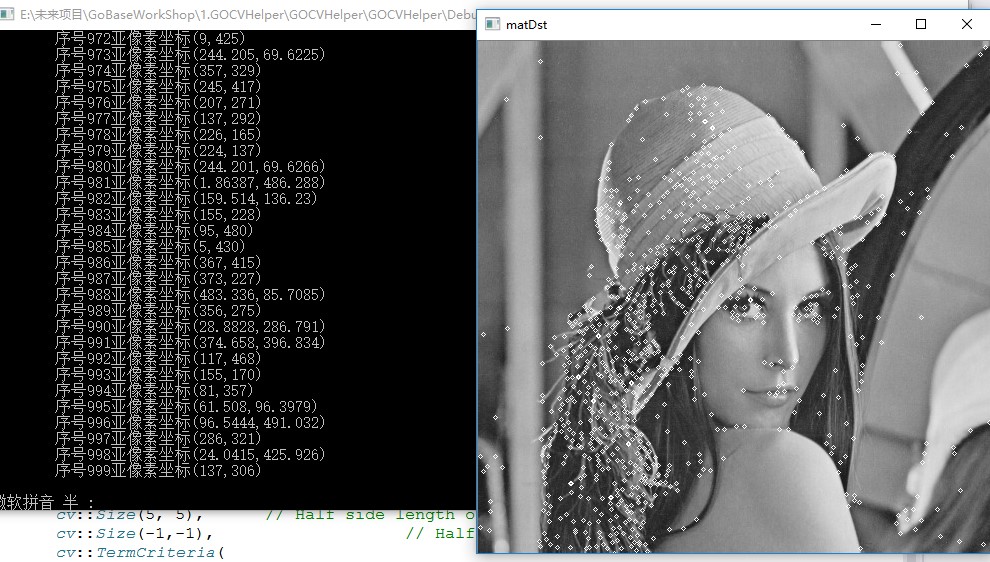
| void cv::cornerSubPix | ( | InputArray | image, |
| InputOutputArray | corners, | ||
| Size | winSize, | ||
| Size | zeroZone, | ||
| TermCriteria | criteria | ||
| ) |
cout);
寻找Harris、Shi-Tomasi和亚像素角点的更多相关文章
- OpenCV亚像素角点cornerSubPixel()源代码分析
上一篇博客中讲到了goodFeatureToTrack()这个API函数能够获取图像中的强角点.但是获取的角点坐标是整数,但是通常情况下,角点的真实位置并不一定在整数像素位置,因此为了获取更为精确的角 ...
- OpenCV——Harris、Shi Tomas、自定义、亚像素角点检测
#include <opencv2/opencv.hpp> #include <iostream> using namespace cv; using namespace st ...
- OpenCV亚像素级的角点检测
亚像素级的角点检测 目标 在本教程中我们将涉及以下内容: 使用OpenCV函数 cornerSubPix 寻找更精确的角点位置 (不是整数类型的位置,而是更精确的浮点类型位置). 理论 代码 这个教程 ...
- opencv亚像素级角点检测
一般角点检测: harris cv::cornerHarris() shi-tomasi cv::goodFeaturesToTrack() 亚像素级角点检测是在一般角点检测基础之上将检测出的角点精确 ...
- Paper | 亚像素运动补偿 + 视频超分辨
目录 1. ABSTRACT 2. INTRODUCTION 3. RELATED WORKS 4. SUB-PIXEL MOTION COMPENSATION (SPMC) 5. OUR METHO ...
- 亚像素Sub Pixel
亚像素Sub Pixel 评估图像处理算法时,通常会考虑是否具有亚像素精度. 亚像素概念的引出: 图像处理过程中,提高检测方法的精度一般有两种方式:一种是提高图像系统的光学放大倍数和CCD相机的分辨率 ...
- 【工程应用七】接着折腾模板匹配算法 (Optimization选项 + no_pregeneration模拟 + 3D亚像素插值)
在折腾中成长,在折腾中永生. 接着玩模板匹配,最近主要研究了3个课题. 1.创建模型的Optimization选项模拟(2022.5.16日) 这两天又遇到一个做模板匹配隐藏的高手,切磋起来后面就还是 ...
- Opencv 亚像素级别角点检测
Size winSize = Size(5,5); Size zerozone = Size(-1,-1); TermCriteria tc = TermCriteria(TermCriteria:: ...
- OpenCV 亚像素级的角点检测
#include "opencv2/highgui/highgui.hpp" #include "opencv2/imgproc/imgproc.hpp" #i ...
随机推荐
- POJ 3259 Wormholes Bellman_ford负权回路
Description While exploring his many farms, Farmer John has discovered a number of amazing wormholes ...
- Mysql元数据生成Hive建表语句注释脚本
在将数据从Mysql 等其他关系型数据库 抽取到Hive 表中时,需要同步mysql表中的注释,以下脚本可以生成hive表字段注释修改语句. 注:其他关系型数据库如:oracle 可以通过相同的思路, ...
- java运算符优先级与流程控制
1. Java 的方法Method (函数 Function), 功能, 动作 1) 方法就是函数: y=f(x)=3x+6; 2) 方法的语法 (修饰词)(返回值类型)(方法名)(参数列表){ ...
- POI通过模板导出EXCEL文件
一般的EXCEL导出使用POI先创建一个HSSFWorkbook,然后通过不断创建HSSFRow,HSSFCell后设置单元格内容便可以完成导出. 这次在项目中需要用到模板,导出的内容包括(1.模板中 ...
- Mybatis Dynamic Query 2.0 入门
简介 2.0 昨天打包好了,主要是整合了tk.mybatis.mapper 到项目中去,所以和1.x比起来主要多了一个通用mapper.因为作者主要是使用springboot 这里讲一下Springb ...
- MySQL Flush导致的等待问题
--MySQL Flush导致的等待问题 -------------------------------2014/07/13 前言 在实际生产环境中有时会发现大量的sql语句处于waiting for ...
- mongodb相关 (population)
记录Mongodb的populate Mongodb是文档型数据库,不存在像关系型数据库一样的外键设置,但通过Mongodb中的populate函数可以模拟关系型数据库的外键连接后的查询功能. 文档型 ...
- SSH服务(一)
一.初始SSH SSH是标准的网络协议,可用于大多数UNIX操作系统,能够实现字符界面的远程登录管理,它默认使用22号端口,采用密文的形式在网络中传输数据,相对于通过明文传输的Telnet,具有更高的 ...
- OpenCV探索之路(二十三):特征检测和特征匹配方法汇总
一幅图像中总存在着其独特的像素点,这些点我们可以认为就是这幅图像的特征,成为特征点.计算机视觉领域中的很重要的图像特征匹配就是一特征点为基础而进行的,所以,如何定义和找出一幅图像中的特征点就非常重要. ...
- 关于VS AddIn的注册
使用VS2010创建addin工程时,如果选择的开发语言是unmanaged c++,以addin为后缀的XML描述文件就不起作用了.这种情况下addin通过注册表来实现注册功能.实际可在如下位置找到 ...