
poj 1265&&poj 2954(Pick定理)
| Time Limit: 1000MS | Memory Limit: 10000K | |
| Total Submissions: 5811 | Accepted: 2589 |
Description
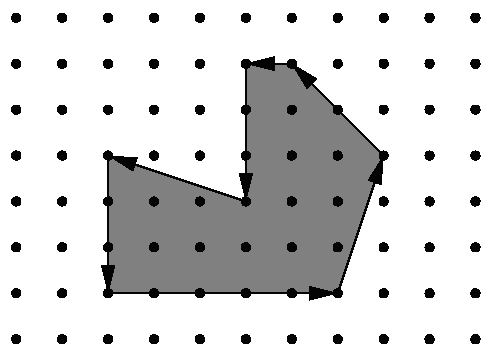
Figure 1: Example area.
You are hired to write a program that calculates the area occupied
by the new facility from the movements of a robot along its walls. You
can assume that this area is a polygon with corners on a rectangular
grid. However, your boss insists that you use a formula he is so proud
to have found somewhere. The formula relates the number I of grid points
inside the polygon, the number E of grid points on the edges, and the
total area A of the polygon. Unfortunately, you have lost the sheet on
which he had written down that simple formula for you, so your first
task is to find the formula yourself.
Input
For each scenario, you are given the number m, 3 <= m < 100,
of movements of the robot in the first line. The following m lines
contain pairs 揹x dy�of integers, separated by a single blank, satisfying
.-100 <= dx, dy <= 100 and (dx, dy) != (0, 0). Such a pair means
that the robot moves on to a grid point dx units to the right and dy
units upwards on the grid (with respect to the current position). You
can assume that the curve along which the robot moves is closed and that
it does not intersect or even touch itself except for the start and end
points. The robot moves anti-clockwise around the building, so the area
to be calculated lies to the left of the curve. It is known in advance
that the whole polygon would fit into a square on the grid with a side
length of 100 units.
Output
output for every scenario begins with a line containing 揝cenario #i:�
where i is the number of the scenario starting at 1. Then print a single
line containing I, E, and A, the area A rounded to one digit after the
decimal point. Separate the three numbers by two single blanks.
Terminate the output for the scenario with a blank line.
Sample Input
2

4

1 0

0 1

-1 0

0 -1

7

5 0

1 3

-2 2

-1 0

0 -3

-3 1

0 -3
Sample Output
Scenario #1:

0 4 1.0

Scenario #2:

12 16 19.0

题意:一个多边形从某个点出发(假设从0,0出发),每次有一个增量(dx,dy)!=(0,0) 经过n次之后又回到了原点
组成了一个简单多边形.问此时多边形内部的整点的数量,多边形边上的整点的数量,多边形的面积.

Pick定理:一个计算点阵中顶点在格点上的多边形面积公式:S=a+b/2-1,其中a表示多边形内部的整点数,b表示
多边形边界上的整点数,s表示多边形的面积。(ps:整点是x,y坐标都是整数)
每条边上的格点数(顶点只算终点) = gcd(abs(x2-x1),abs(y2-y1))
///题意:一个多边形从某个点出发(假设从0,0出发),每次有一个增量(dx,dy)!=(0,0) 经过n次之后又回到了原点

///组成了一个简单多边形.问此时多边形内部的整点的数量,多边形边上的整点的数量,多边形的面积.

///Pick定理:一个计算点阵中顶点在格点上的多边形面积公式:S=a+b/2-1,其中a表示多边形内部的整点数,b表示

///多边形边界上的整点数,s表示多边形的面积。(ps:整点是x,y坐标都是整数)

///每条边上的格点数 = gcd(abs(x2-x1),abs(y2-y1))

#include <iostream>

#include <cstdio>

#include <cstring>

#include <math.h>

#include <algorithm>

#include <stdlib.h>

using namespace std;

const int N =;

struct Point {

    int x,y;

}p[N];

int gcd(int a,int b){

    return b==?a:gcd(b,a%b);

}

int cross(Point a,Point b,Point c){

    return (a.x-c.x)*(b.y-c.y)-(a.y-c.y)*(b.x-c.x);

}

int main()

{

    int tcase;

    scanf("%d",&tcase);

    int k = ;

    while(tcase--){

        int n;

        scanf("%d",&n);

        p[].x = ,p[].y = ;

        int On=,In=;

        double area=;

        for(int i=;i<=n;i++){

            int dx,dy;

            scanf("%d%d",&dx,&dy);

            p[i].x= p[i-].x+dx;

            p[i].y=p[i-].y+dy;

            On+=gcd(abs(dx),abs(dy));

        }

        for(int i=;i<n-;i++){

            area+=cross(p[i],p[i+],p[])/2.0;

        }

        In = (int)(area+-On/);

        printf("Scenario #%d:\n%d %d %.1lf\n\n",k++,In,On,area);

    }

    return ;

}
poj 2954
http://acm.pku.edu.cn/JudgeOnline/problem?id=2954
///题意:完全包含在三角形内的整点有多少

#include <iostream>

#include <cstdio>

#include <cstring>

#include <math.h>

#include <algorithm>

#include <stdlib.h>

using namespace std;

struct Point {

    int x,y;

}p1,p2,p3;

int gcd(int a,int b){

    return b==?a:gcd(b,a%b);

}

int cross(Point a,Point b,Point c){

    return (a.x-c.x)*(b.y-c.y)-(a.y-c.y)*(b.x-c.x);

}

int main()

{

    while(scanf("%d%d%d%d%d%d",&p1.x,&p1.y,&p2.x,&p2.y,&p3.x,&p3.y)!=EOF){

        if(p1.x==&&p1.y==&&p2.x==&&p2.y==&&p3.x==&&p3.y==) break;

        double area = fabs(cross(p2,p3,p1)/2.0);

        int On = gcd(abs(p2.x-p1.x),abs(p2.y-p1.y))+gcd(abs(p3.x-p2.x),abs(p3.y-p2.y))+gcd(abs(p3.x-p1.x),abs(p3.y-p1.y));

        printf("%d\n",(int)(area+-On/));

    }

    return ;

}
poj 1265&&poj 2954(Pick定理)的更多相关文章
- poj 1265 Area(Pick定理)
Area Time Limit: 1000MS Memory Limit: 10000K Total Submissions: 5666 Accepted: 2533 Description ...
- POJ 1265 Area (pick定理)
题目大意:已知机器人行走步数及每一步的坐标变化量,求机器人所走路径围成的多边形的面积.多边形边上和内部的点的数量. 思路:叉积求面积,pick定理求点. pick定理:面积=内部点数+边上点数/2-1 ...
- POJ 1265 Area POJ 2954 Triangle Pick定理
Area Time Limit: 1000MS Memory Limit: 10000K Total Submissions: 5227 Accepted: 2342 Description ...
- 【POJ】2954 Triangle(pick定理)
http://poj.org/problem?id=2954 表示我交了20+次... 为什么呢?因为多组数据我是这样判断的:da=sum{a[i].x+a[i].y},然后!da就表示没有数据了QA ...
- poj 2954 Triangle(Pick定理)
链接:http://poj.org/problem?id=2954 Triangle Time Limit: 1000MS Memory Limit: 65536K Total Submissio ...
- poj 1265 Area (Pick定理+求面积)
链接:http://poj.org/problem?id=1265 Area Time Limit: 1000MS Memory Limit: 10000K Total Submissions: ...
- POJ 1265 Area (Pick定理 & 多边形面积)
题目链接:POJ 1265 Problem Description Being well known for its highly innovative products, Merck would d ...
- poj 1265 Area(pick定理)
Area Time Limit: 1000MS Memory Limit: 10000K Total Submissions: 4373 Accepted: 1983 Description Bein ...
- [poj 1265]Area[Pick定理][三角剖分]
题意: 给出机器人移动的向量, 计算包围区域的内部整点, 边上整点, 面积. 思路: 面积是用三角剖分, 边上整点与GCD有关, 内部整点套用Pick定理. S = I + E / 2 - 1 I 为 ...
随机推荐
- P2680 运输计划(二分+树上差分)
P2680 运输计划 链接 分析: 二分+树上差分. 首先可以二分一个答案,那么所有比这个答案大的路径,都需要减去些东西才可以满足这个答案. 那么减去的这条边一定在所有的路径的交集上. 那么如果求快速 ...
- loj2100 「TJOI2015」线性代数
先推公式,推出个这,然后因为是 \(0/1\) 矩阵,选一个有损耗,两个一组有加成,就想到了最大权闭合子图,(飞行计划问题) #include <iostream> #include &l ...
- phpStorm9.0 +xampp+chrome php调试环境配置!
不多说,直接上step by step: 1.xampp配置 看看我的XAMPP版本: 修改配置文件,该打开打开,该加上加上,结果如下(当前需要重新启动apache,配置才会生效): [XDebug] ...
- 在SqlServer中通过SQL语句实现树状查询
CREATE PROCEDURE [dbo].[GetTree] @Id int AS BEGIN with cte as ( as lvl from Entity where Id = @Id un ...
- GTID环境中手动修复主从故障一例(Error 1146)
Preface In my last test of pt-heartbeat,both of master and slave were out of disk.And the my ...
- Spring整合EhCache详解
一.EhCache介绍 EhCache 是一个纯Java的进程内缓存框架,具有快速.精干等特点,是Hibernate中默认的CacheProvider.Ehcache是一种广泛使用的开 源Java分布 ...
- NGUI-UIScroll View的使用及注意点
项目层次: scrollviewbg是600x150的背景图,Inspector视图如下: panel就是scrollview父容器了,size为600x150,Inspector视图如下: item ...
- Python全栈工程师(编码)
ParisGabriel Python 入门基础 补充: 主流3操作大系统 Windows: Winxp Win7 Win8 Win10 Unix: Solaris(SUN) IO ...
- CSU-2110 Keeping Cool
题目链接 http://acm.csu.edu.cn:20080/csuoj/problemset/problem?pid=2110 题目 Description Kevin has just got ...
- Opencv3.2.0安装包
这个资源是Opencv3.2.0安装包,包括Windows软件包,Android软件包,IOS软件包,还有opencv的源代码:需要的下载吧. 点击下载